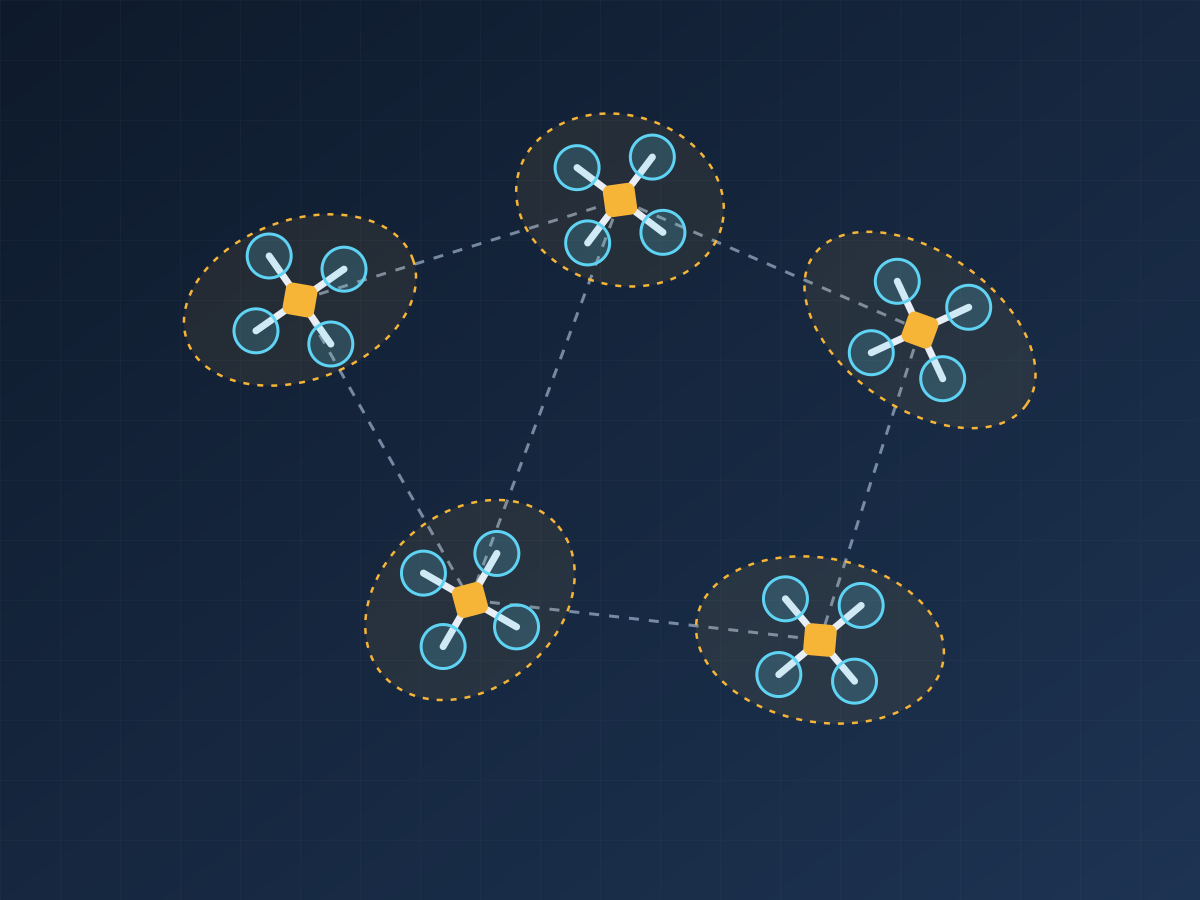
Distributed Invariant EKF for Drone Swarm State Estimation
Distributed invariant EKF for state estimation across a drone swarm.
Distributed invariant EKF for state estimation across a drone swarm.
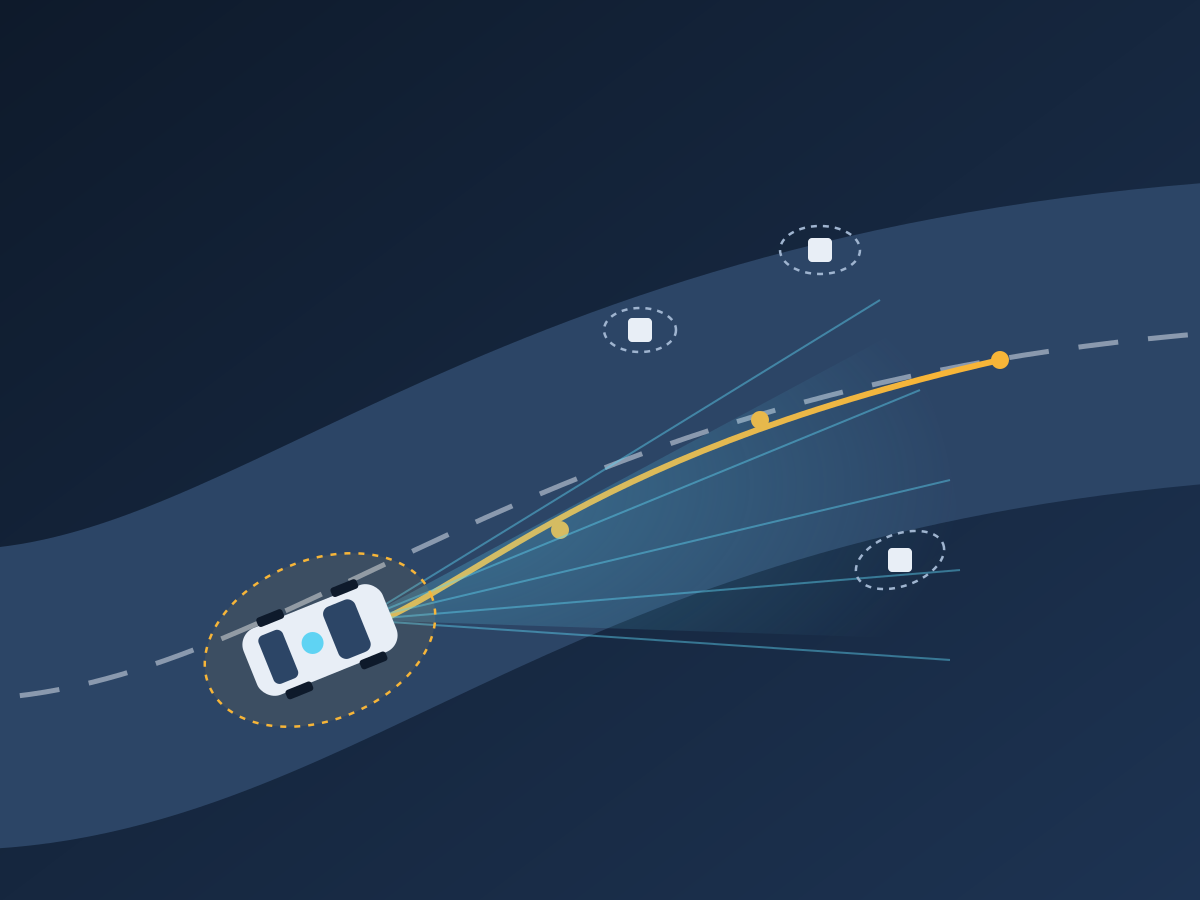
Active perception, localization, and control for an autonomous car.
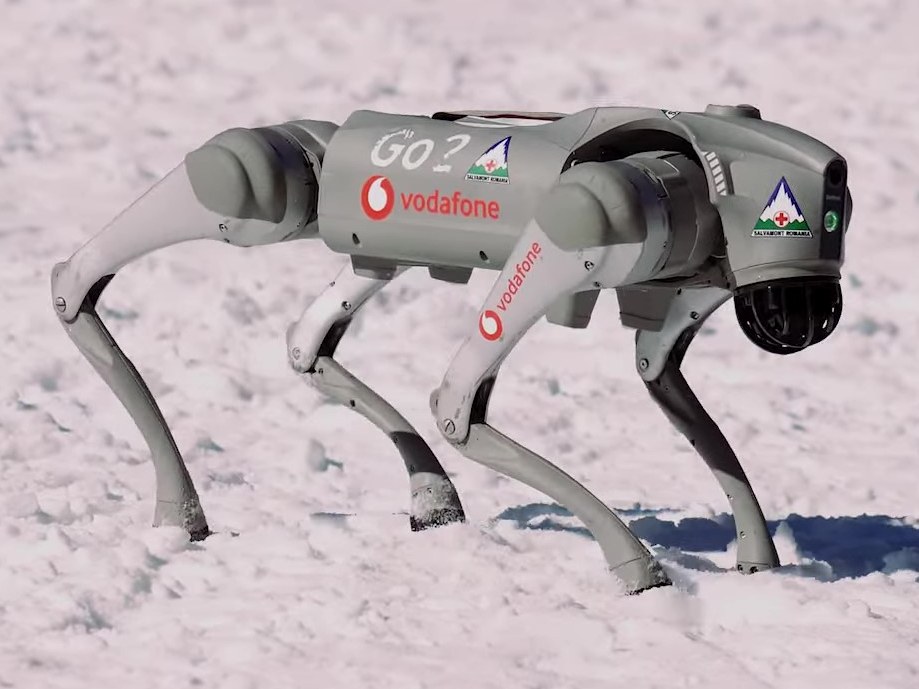
Reinforcement learning for controlled sliding gaits on a Unitree Go2 EDU quadruped, simulated in MuJoCo.
Developing VLM-based approaches to bridge the sim-to-real gap for robotic arm manipulation of reticles.
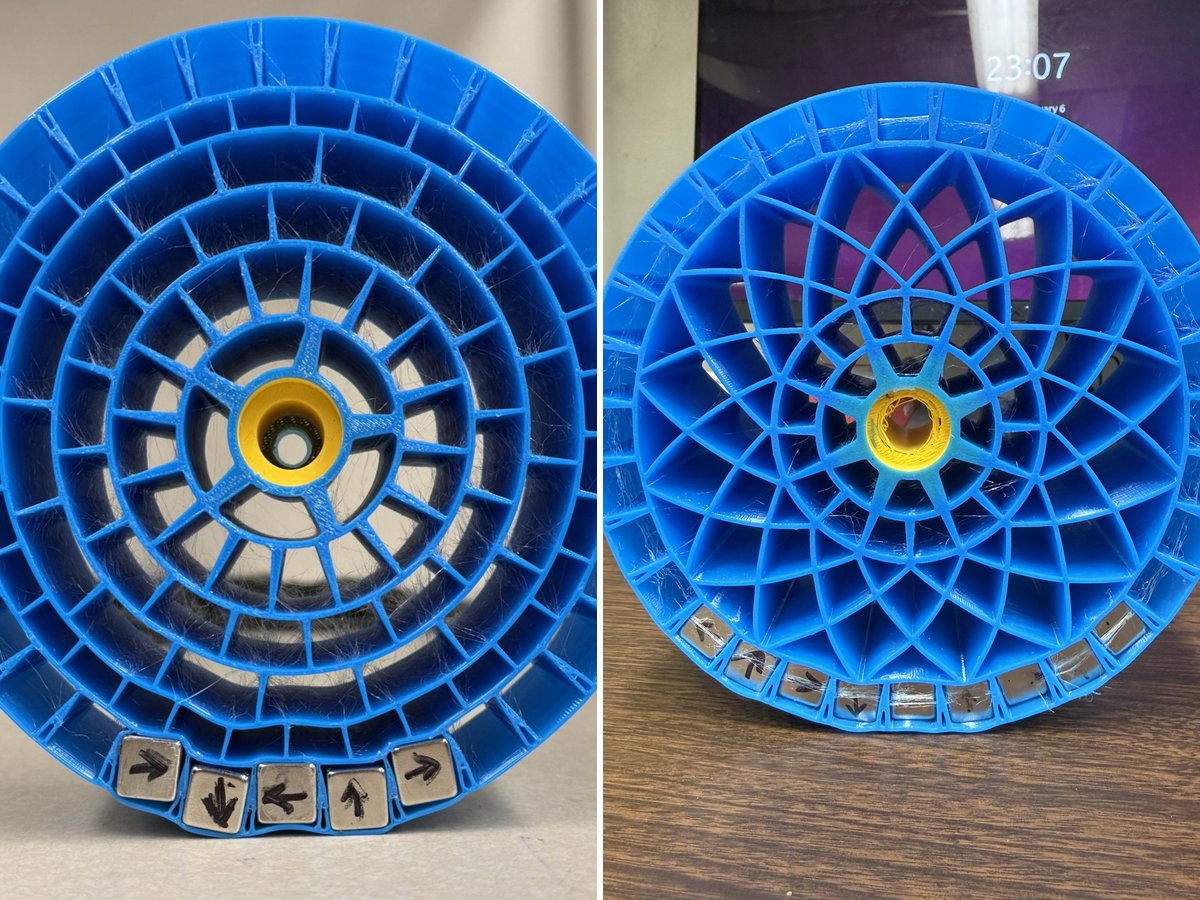
An analytical thin-ring model of a 3D-printed magnetic wheel, validated against COMSOL to within 6% mean error.
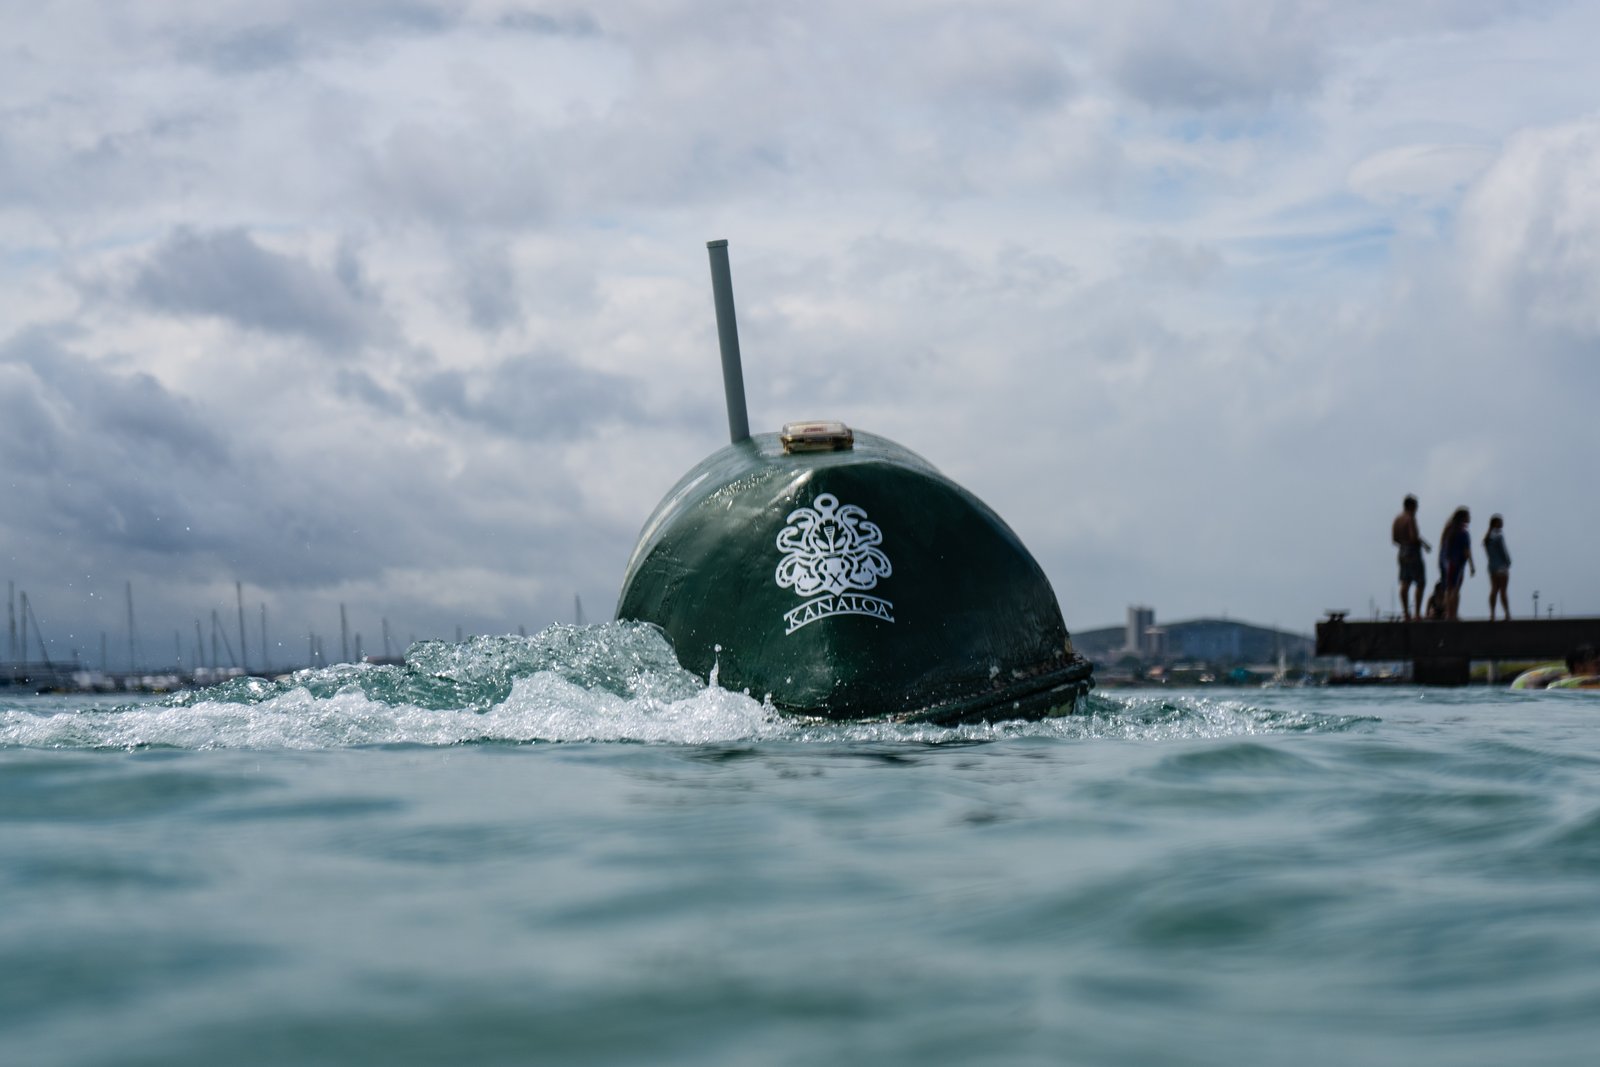
A 400-lb self-righting unmanned surface vessel built for littoral zone surveying.
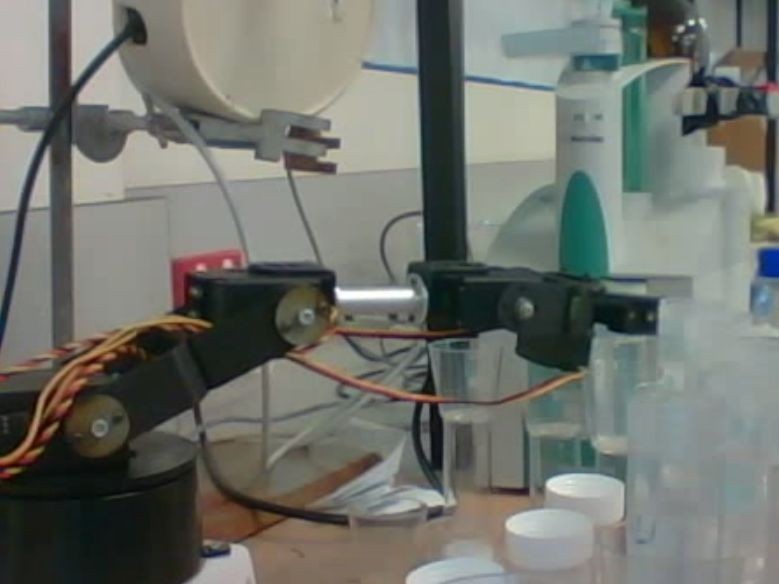
Inverse kinematics and straight-line trajectory control for a 4-DOF arm performing pick-and-place tasks.
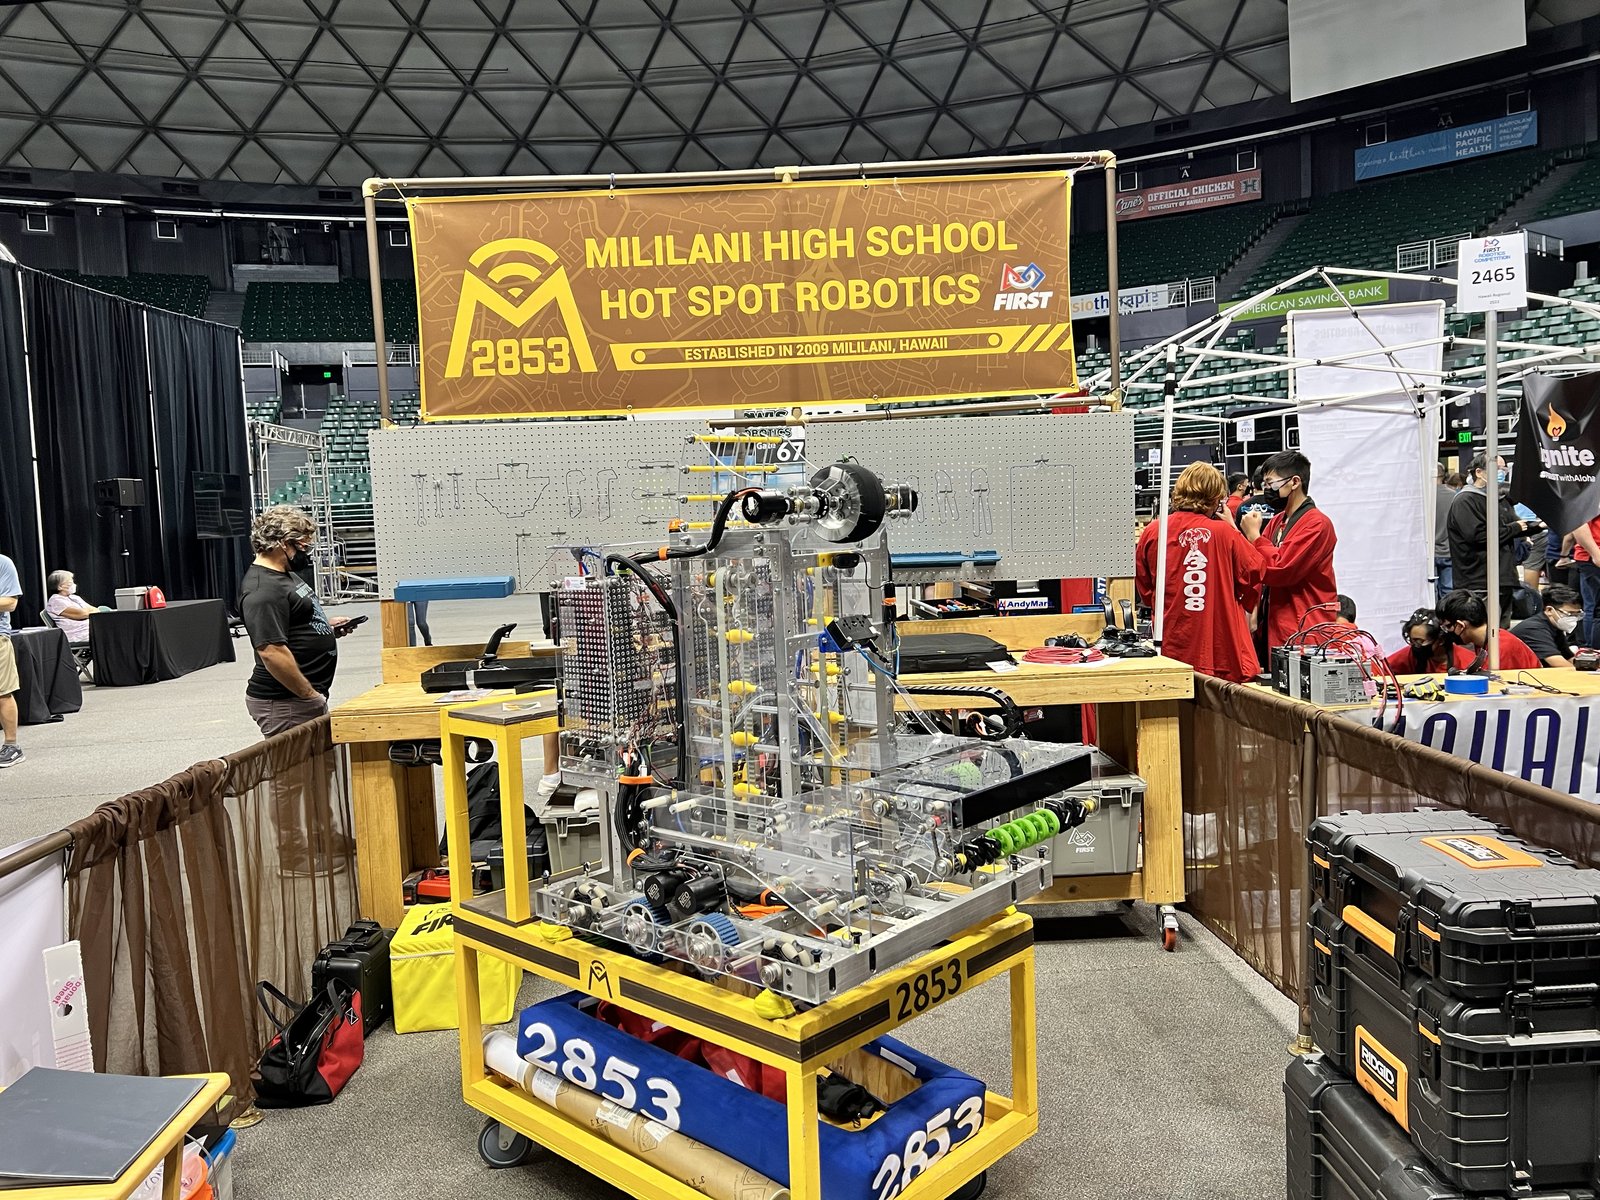
FIRST Robotics Competition with Mililani High School’s Hot Spot Robotics, Team 2853.