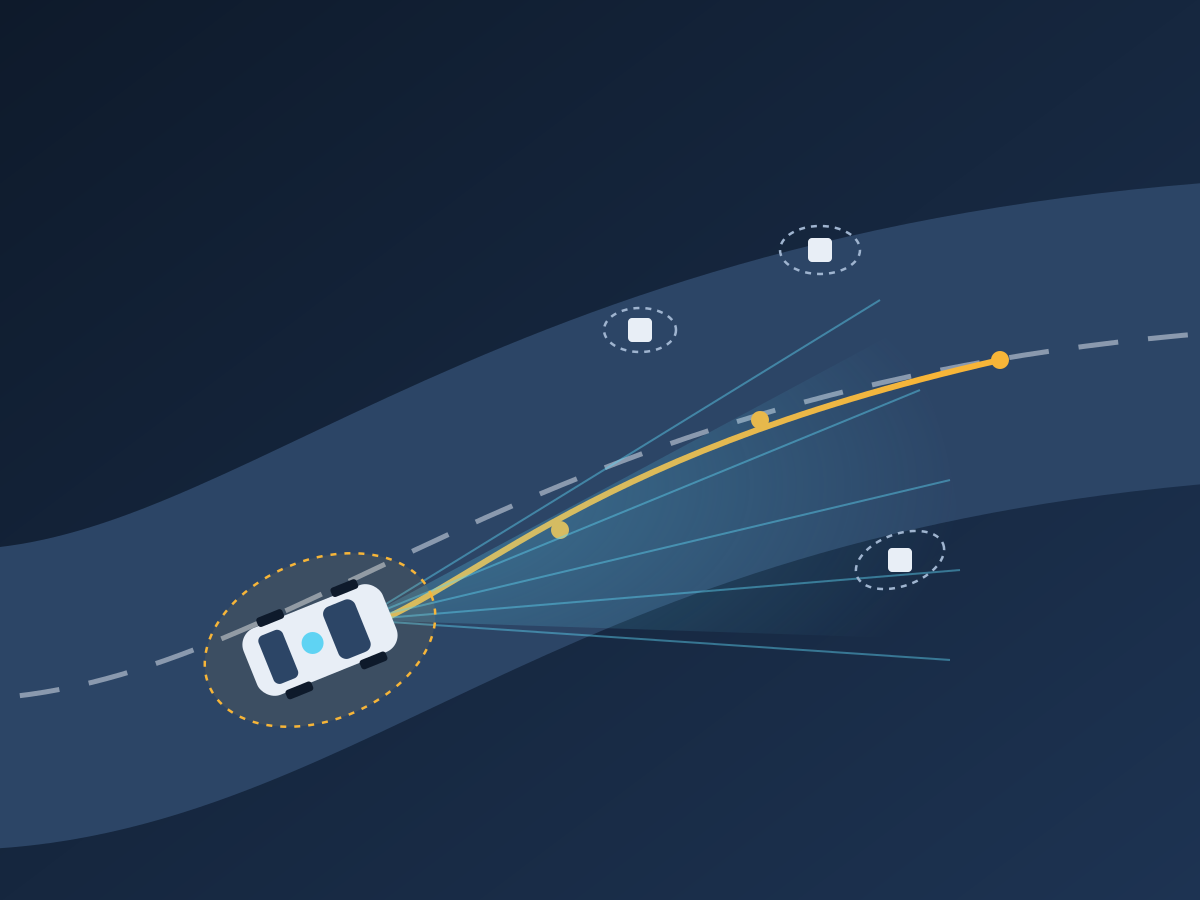
Active Perception, Localization, and Control for an Autonomous Car
Published:
More images coming soon
1 / 2
| Role: MAE 5810 Course Project · Cornell University | When: Aug 2026 – Dec 2026 |
Placeholder: a two-sentence overview of the problem and your approach.
- Placeholder: first contribution, with a concrete result or metric
- Placeholder: second contribution
Skills: LiDAR · ROS 2 · Gazebo