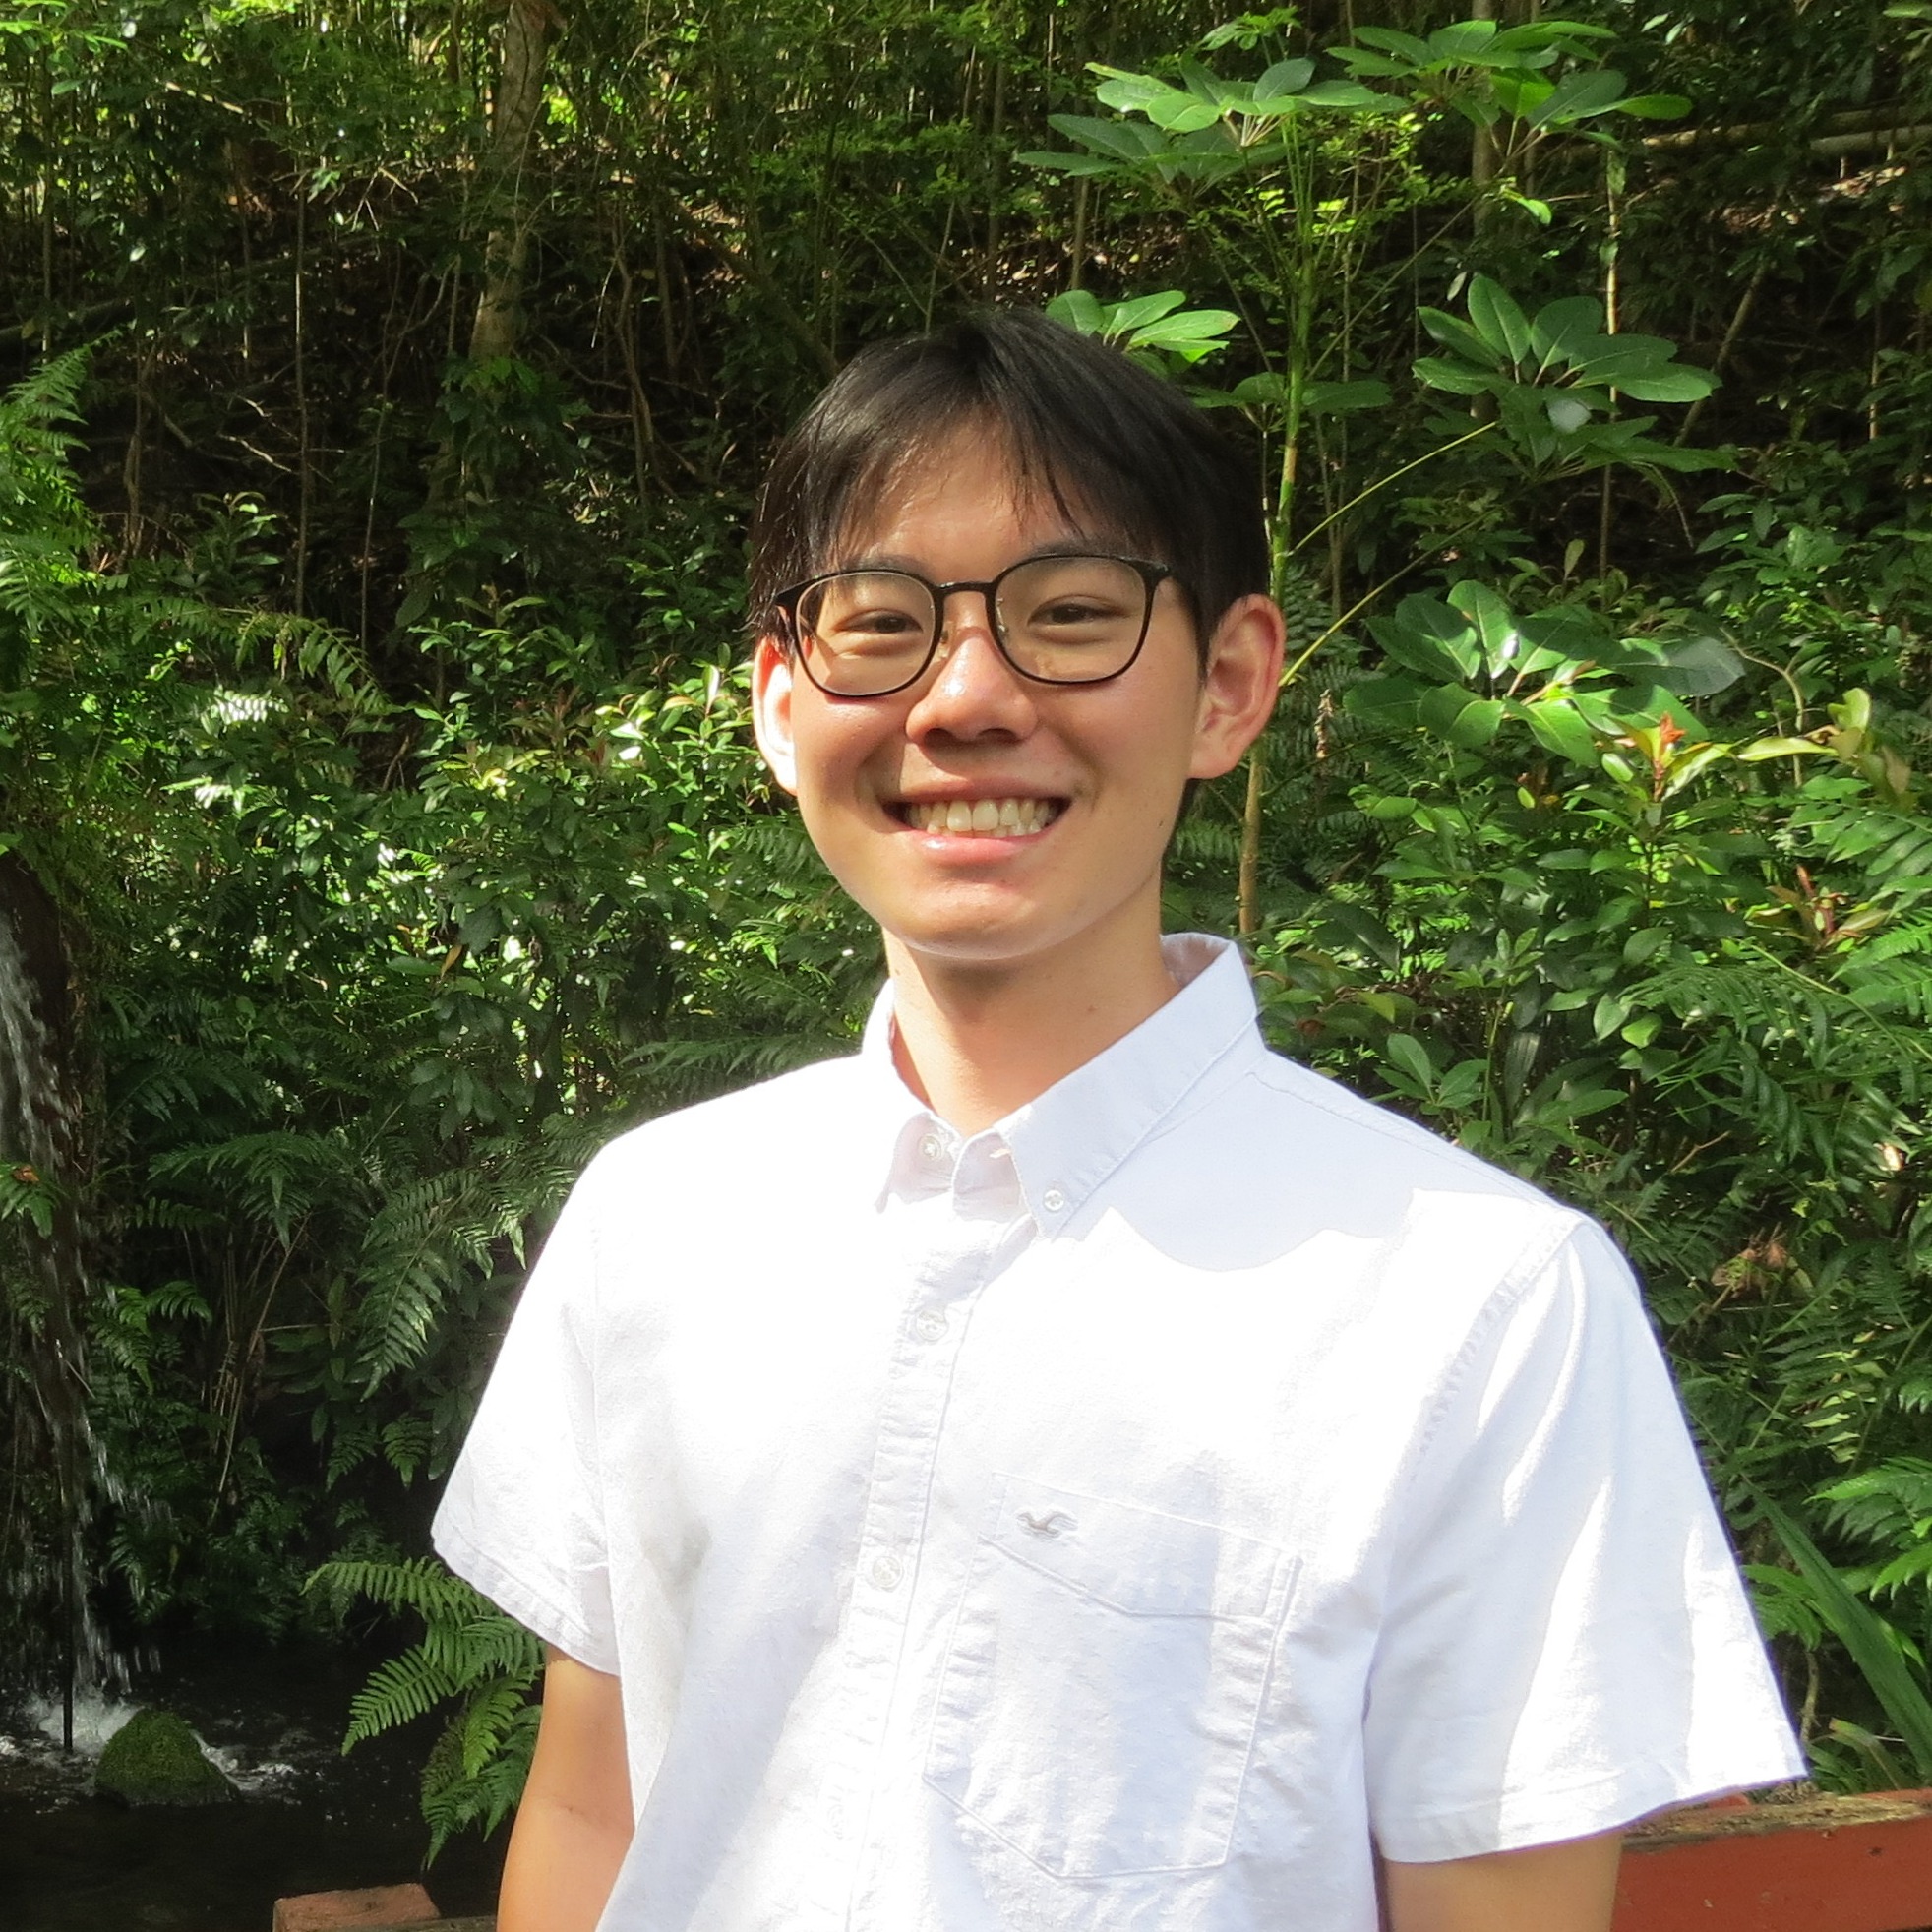
Thomas Istvan
🏖️ About Me
I am from Oahu, Hawaii and a current Master’s student in Mechanical Engineering at Cornell University, where I study Robotics and Controls. Throughout my undergraduate studies and research experiences, I have developed an interest in path planning and control theory, specifically in areas such as optimal and model predictive control, reinforcement learning, and trajectory optimization, particularly for autonomous robots.
At Cornell, I work with ASML on developing VLM-based approaches to bridge the sim-to-real gap for robotic arm manipulation of reticles. Additionally, I work in the GeoDesiC Lab on state estimation and control for quadrotors, supervised by Jake Welde.
Before Cornell, I graduated Summa Cum Laude from the University of Hawai’i at Mānoa with a B.S. in Mechanical Engineering, where I was fortunate to learn and be supervised by Dr. A. Zachary Trimble in the RIP Lab, working on an autonomous infrastructure inspection robot and an unmanned surface vessel, where I learned about design philosophy, low-level control in ROS 2, and sensor fusion for robust localization in dynamic and GPS-denied environments. I was also active in organizations such as Pi Tau Sigma Honor Society, American Society of Mechanical Engineers (ASME), and Institute of Electrical and Electronics Engineers (IEEE).
⌨️ Skills
- Software: ROS 2, Python, MATLAB, Linux, Gazebo, MoveIt 2, KiCad, C++, PyTorch, MuJoCo, Git/GitHub
- Mechanical & Hardware: SolidWorks, Onshape, COMSOL Multiphysics, FDM & resin 3D printing, Arduino, Raspberry Pi, Teensy Microcontrollers, Soldering
📖 Education
- M.Eng. in Mechanical Engineering (Robotics & Controls concentration), Cornell University — Aug 2026 – May 2027
- Masters of Engineering Committee (MEC) Fellowship
- B.S. in Mechanical Engineering, Summa Cum Laude, University of Hawai’i at Mānoa — Aug 2023 – May 2026
- GPA: 3.98/4.0
- Relevant coursework: Robot Perception, Legged Robots, Model-Based Estimation, Optimization for Robotics, Swarm Robotics, Maritime Robotics, Soft Robotics, Manipulator Robotics, Continuum Mechanics
📰 News
- Sep 2026 — Began as a Robotics Engineer at ASML, developing VLM-based approaches to bridge the sim-to-real gap for robotic arm manipulation of reticles.
- Aug 2026 — Started as a Teaching Assistant for MAE 3260 (System Dynamics) at Cornell.
- Aug 2026 — Started my graduate studies at Cornell University.
- May 2026 — Graduated Summa Cum Laude (GPA 3.98) with a B.S. in Mechanical Engineering from the University of Hawai’i at Mānoa.
🎖 Honors and Awards
- MEC Fellowship, $30,000 — Cornell University
- Academic Tuition Scholarship, $6,000 — Cornell University
- Manoa Academic Scholarship, $12,000 — University of Hawai’i at Mānoa
- ASUH Research Scholarship, $1,000 — University of Hawai’i at Mānoa
- Summa Cum Laude, B.S. Mechanical Engineering, GPA 3.98
💻 Work Experience
- Oct 2026 – Present — Graduate Research Assistant, Lamp Lighter Lab
- Sep 2026 – Present — Research Assistant, GeoDesiC Lab
- Sep 2026 – Present — Robotics Engineer, ASML
- May 2024 – Jul 2026 — Mobile Robotics Research Assistant, RIP Lab
- Aug 2025 – May 2026 — Lead Systems Engineer, Team Kanaloa
- May 2024 – May 2025 — Soft Robotics Research Assistant, SAIL Lab