Autonomous Surface Vessel — Team Kanaloa
Published:
1 / 14
| Role: Lead Systems Engineer · Team Kanaloa | When: Aug 2025 – May 2026 |
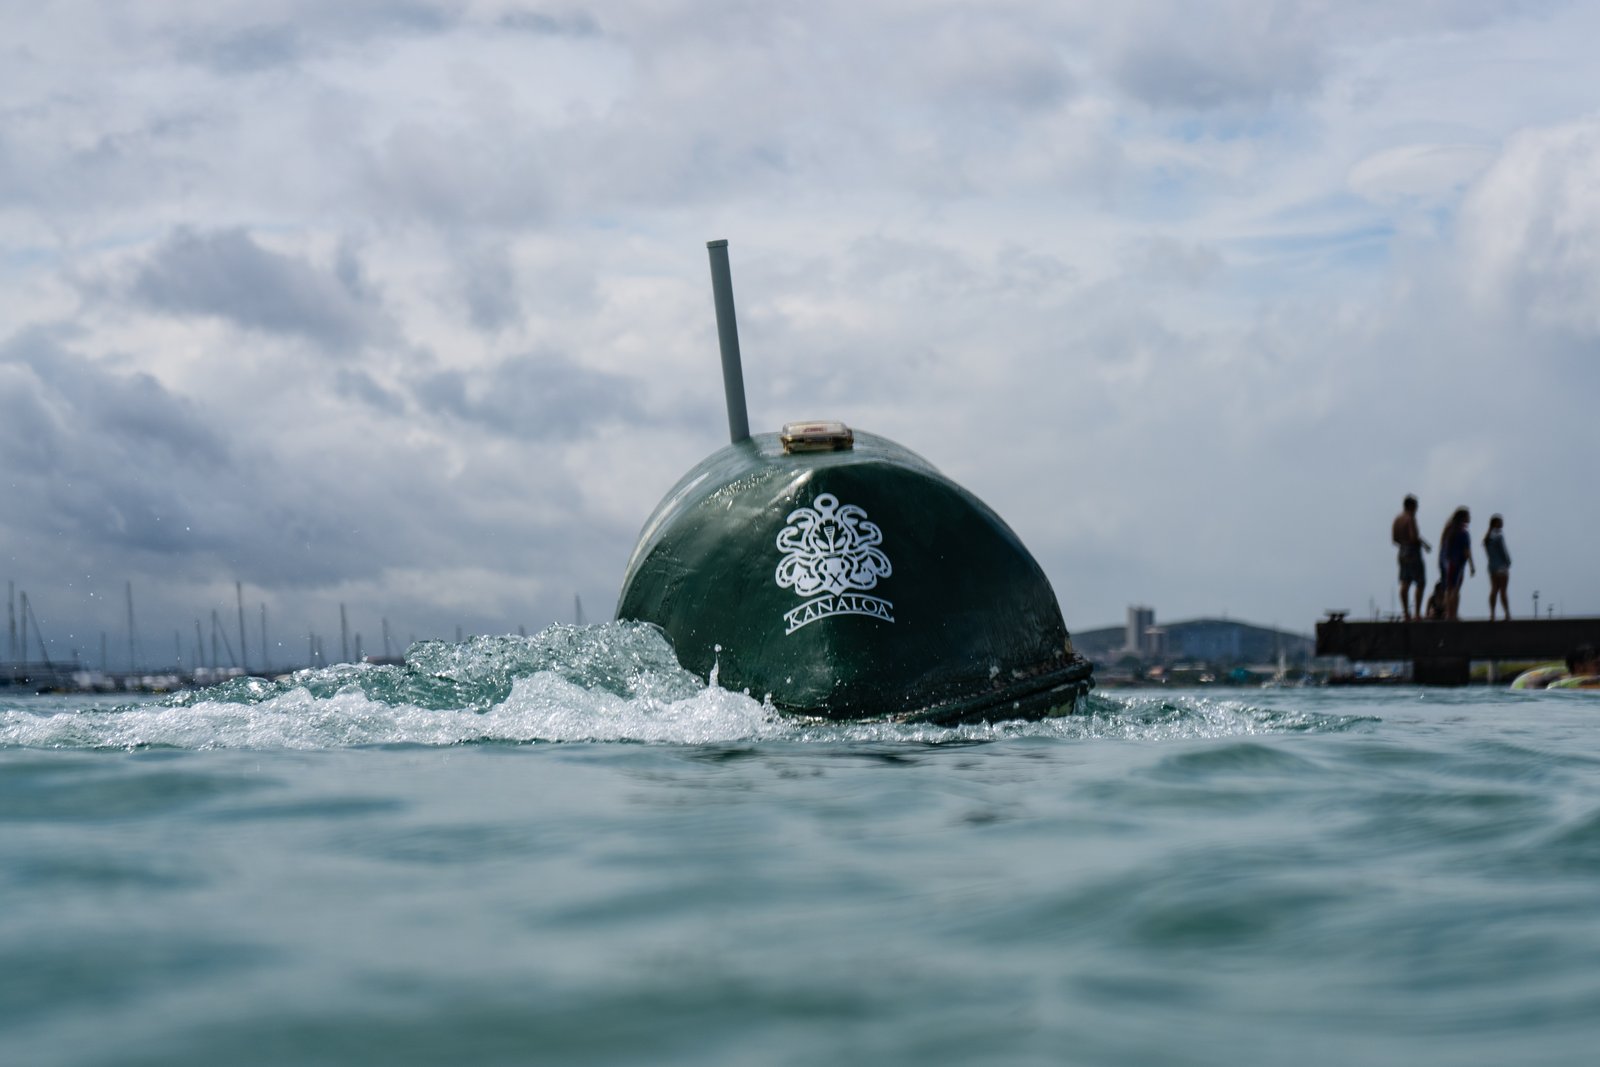
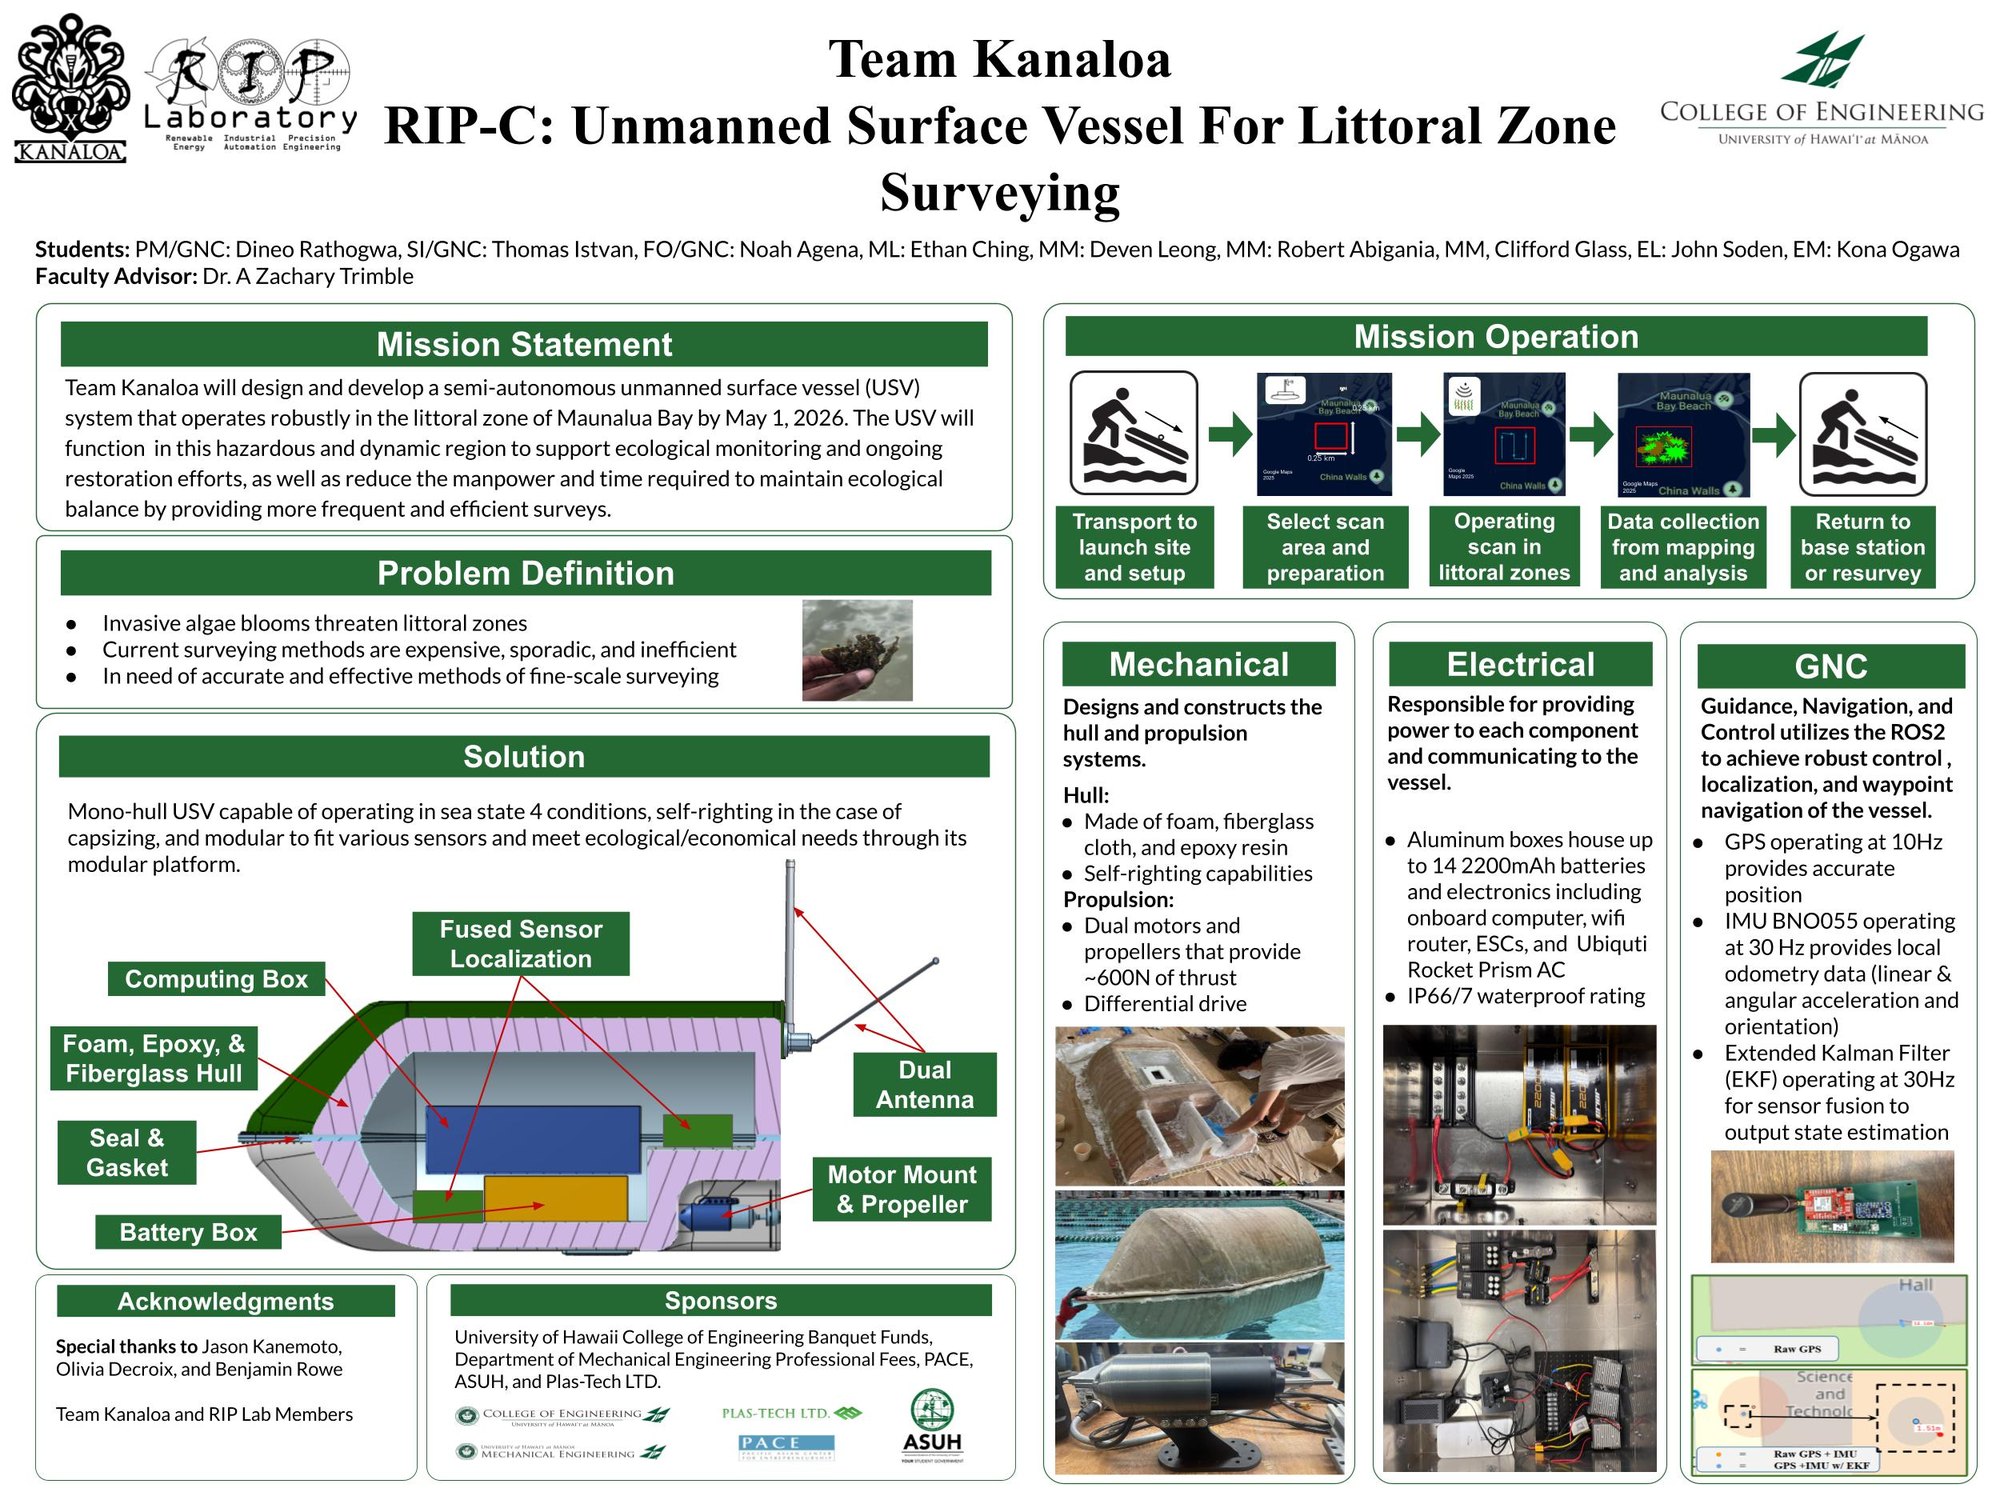
Designed and built a 400-lb unmanned surface vessel with a self-righting hull, then wrote the software that let it navigate on its own for the RobotX competition.
- Ran comparative FEA across hull composite layups (XPS foam core, 10oz fiberglass, marine-grade epoxy) to hit a factor of safety of 5 in 4-foot wave conditions
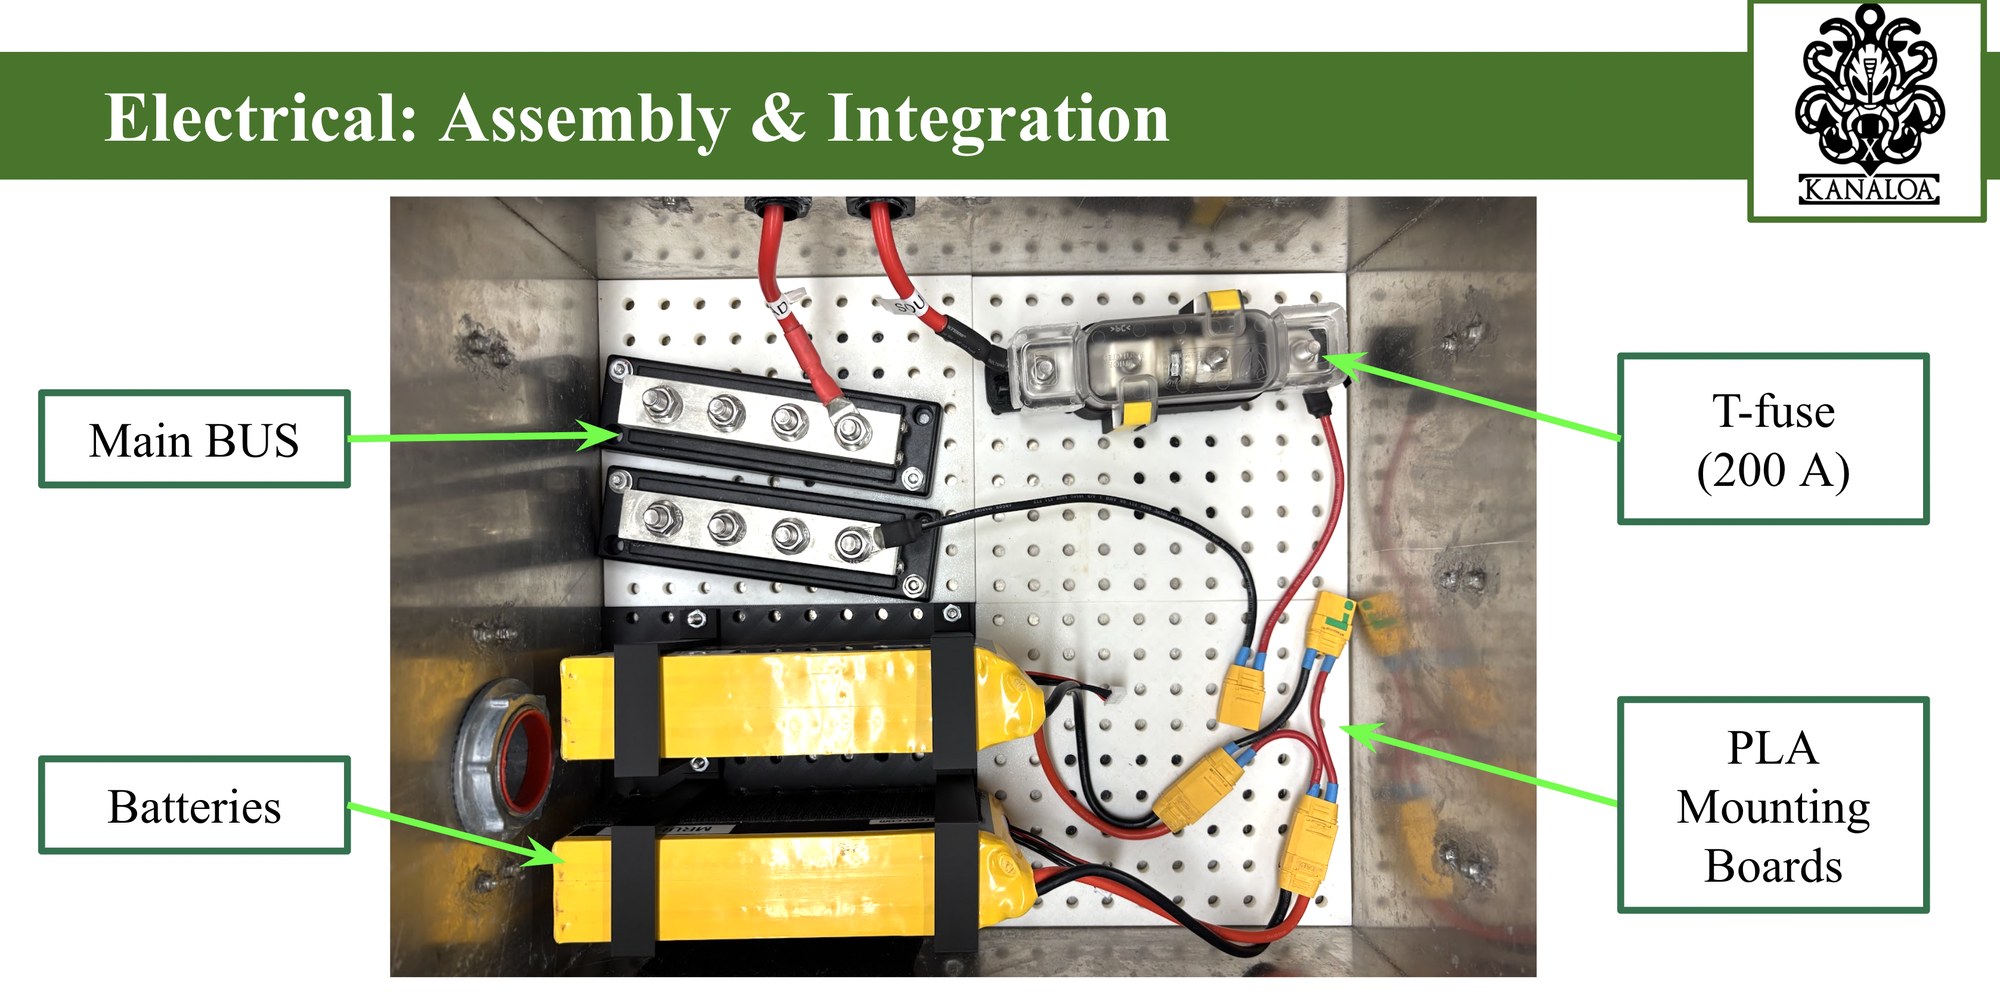
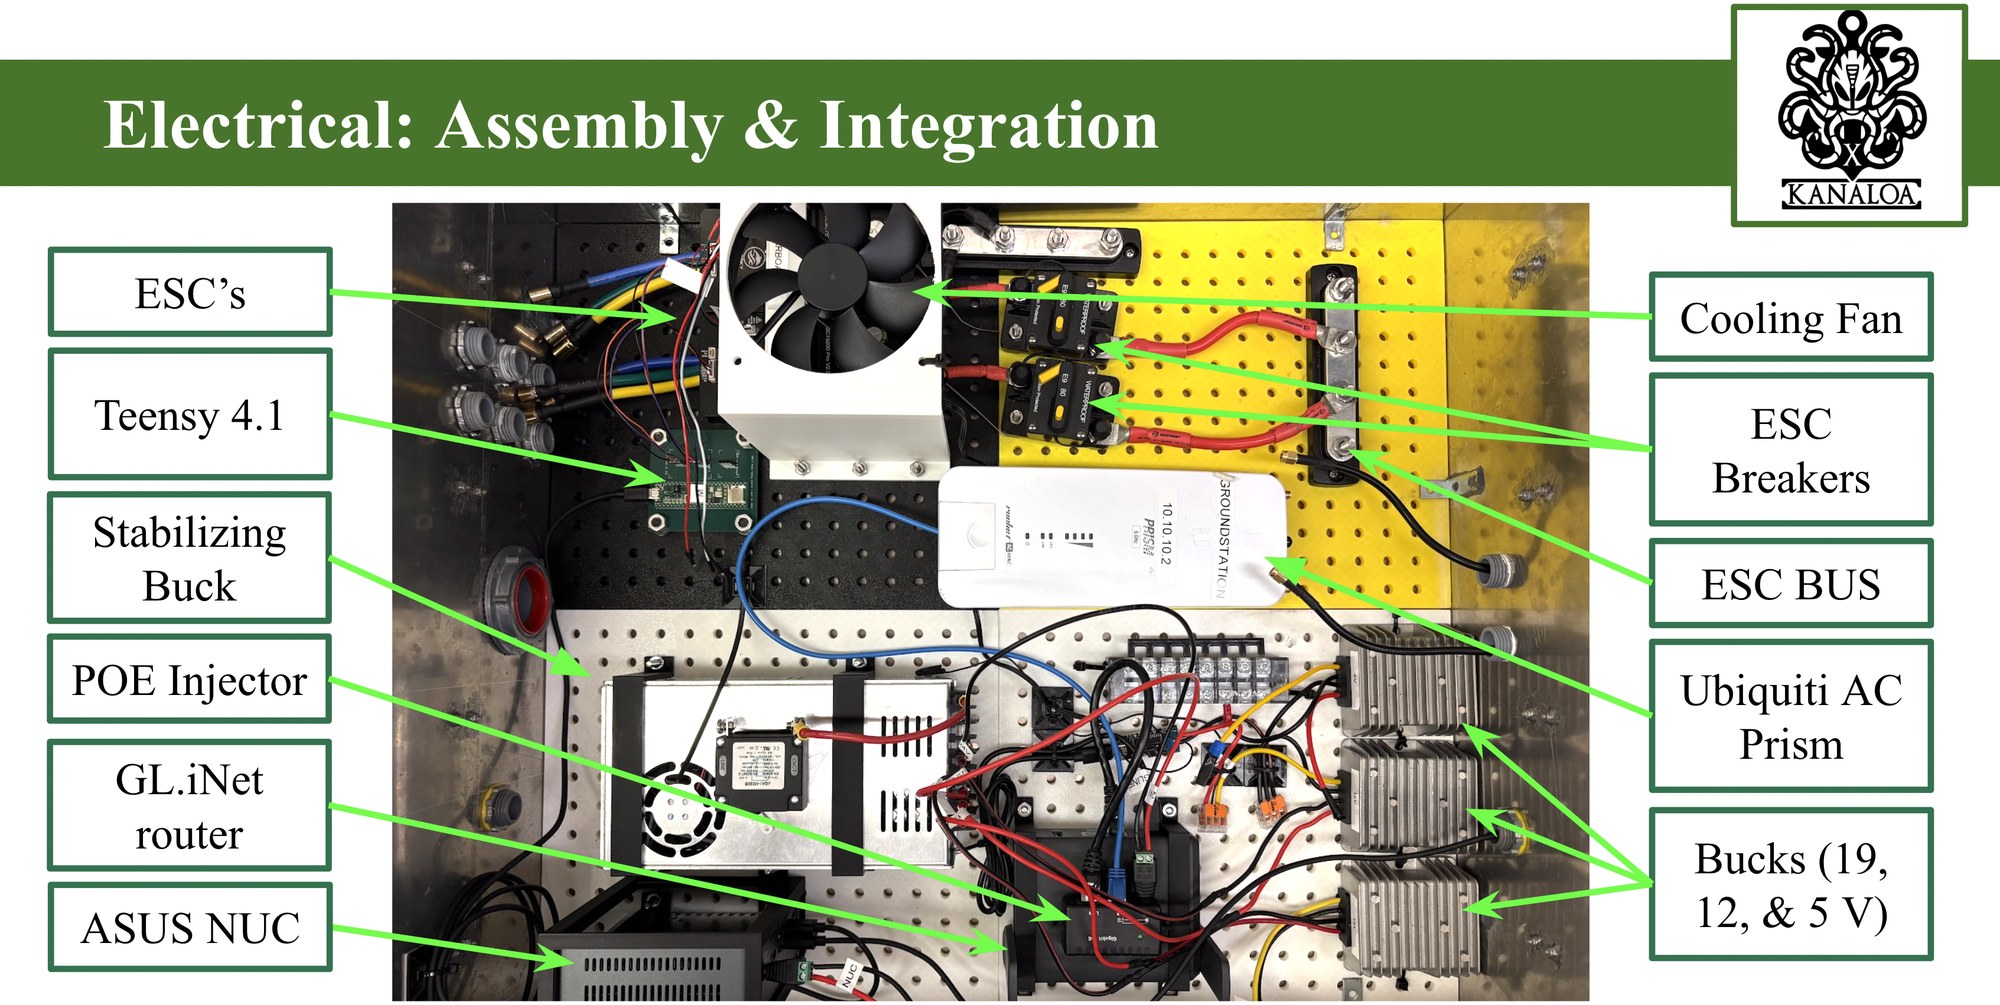
- Integrated an aluminum plate into the bottom of the hull for passive cooling of onboard electronics
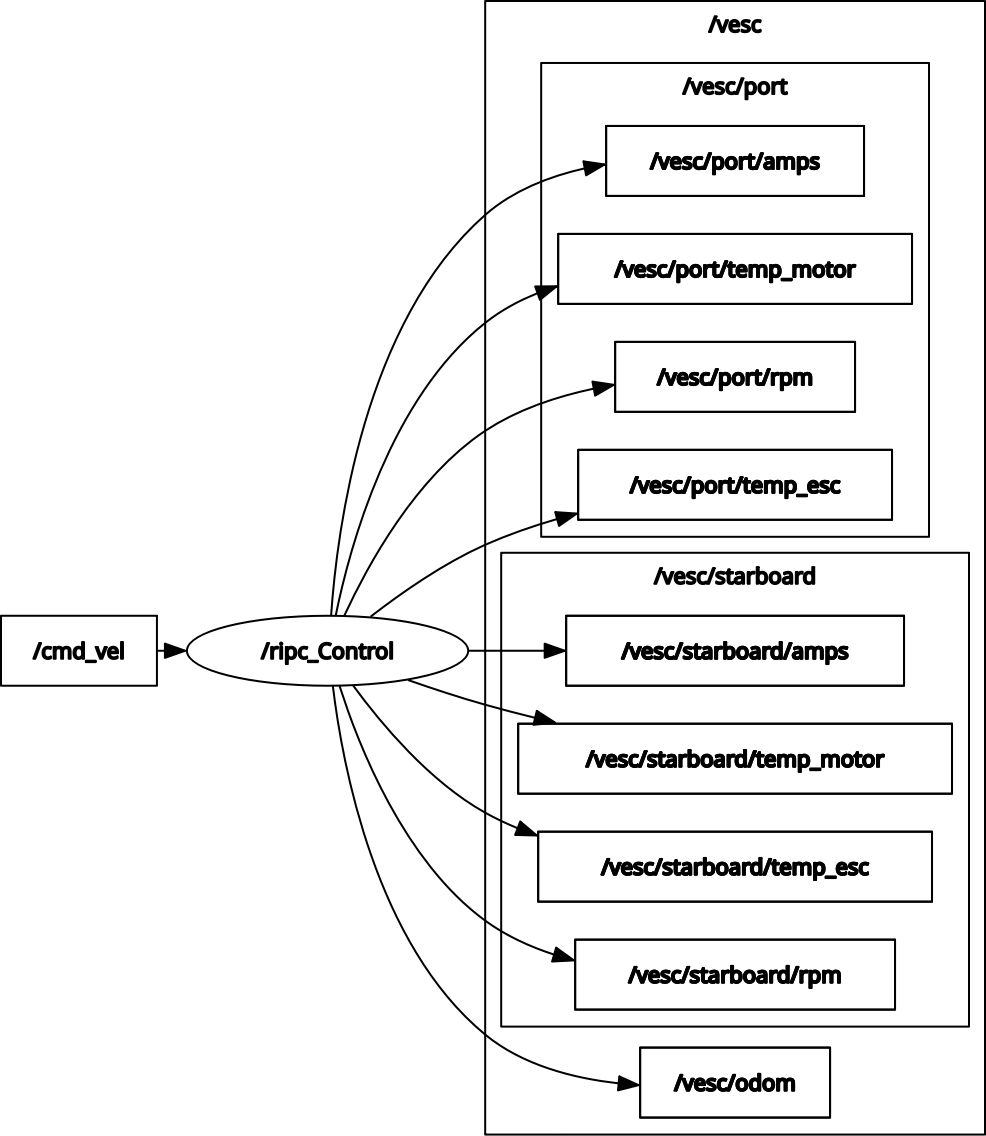
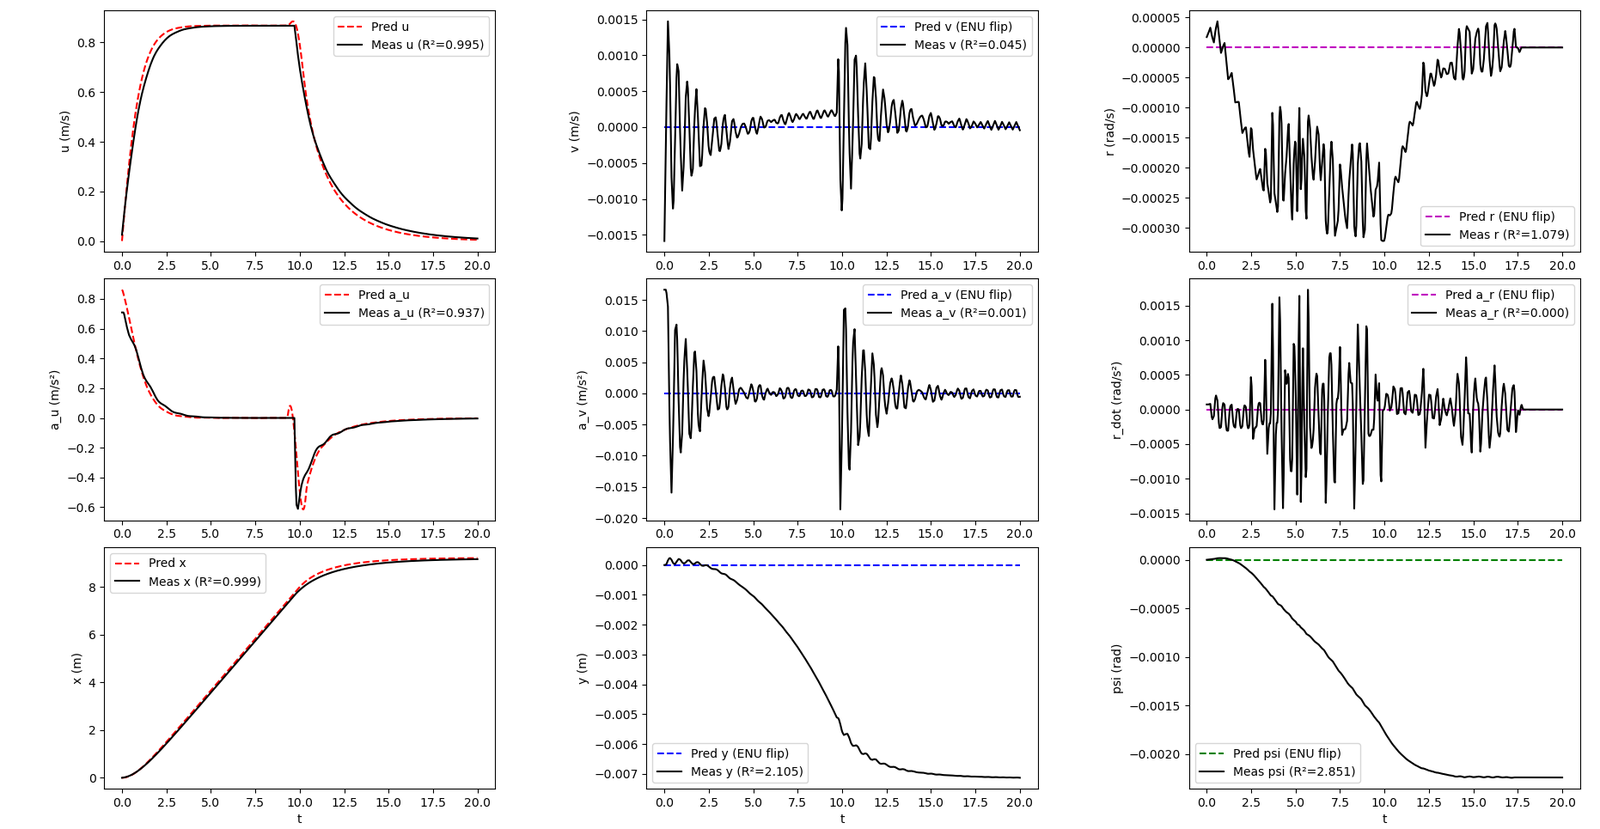
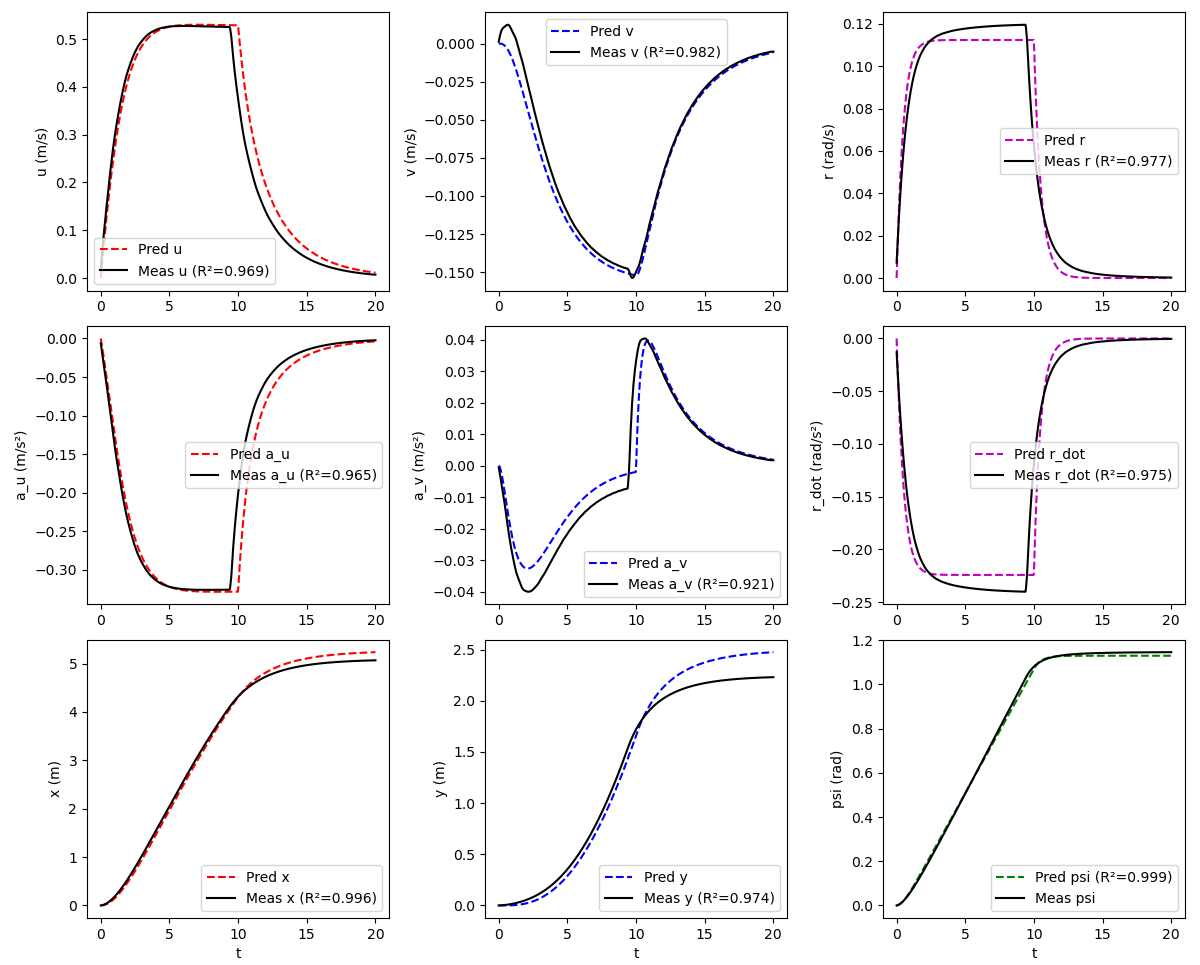
- Modeled the vessel in URDF/XML and validated the C++ PID control and autonomy stack in Gazebo before on-water testing
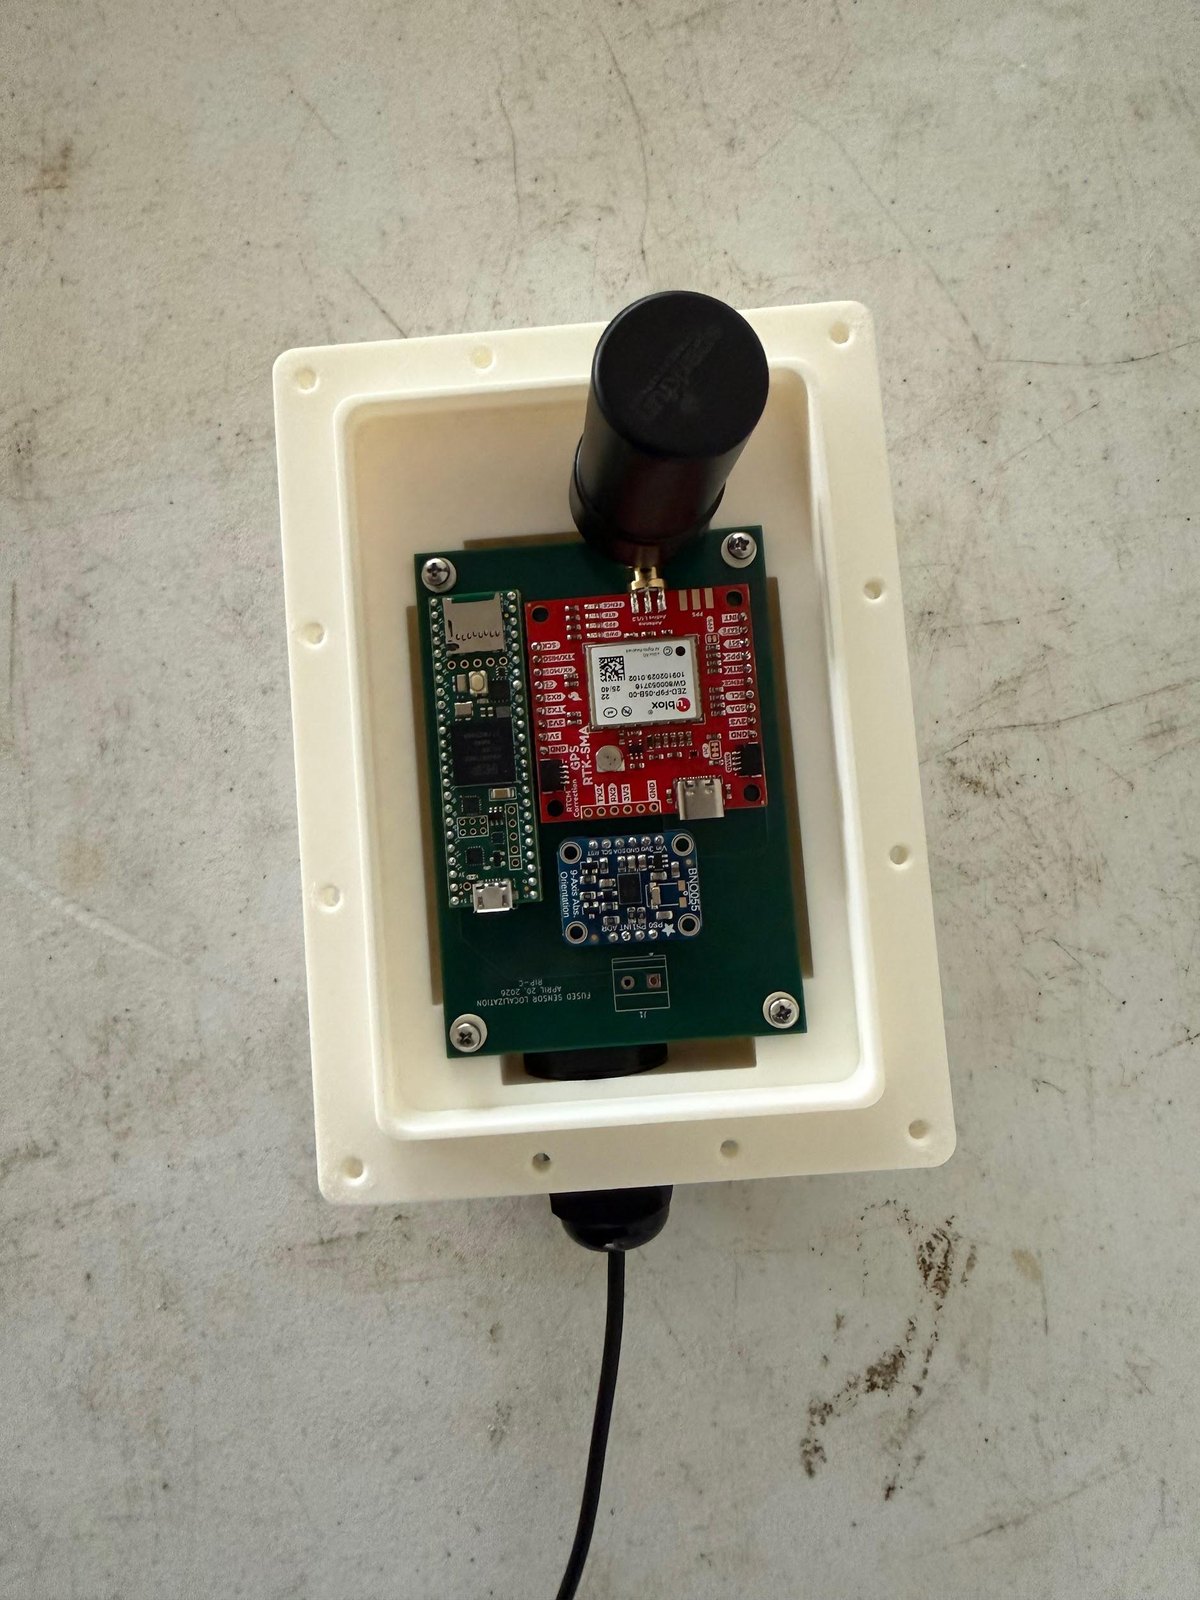
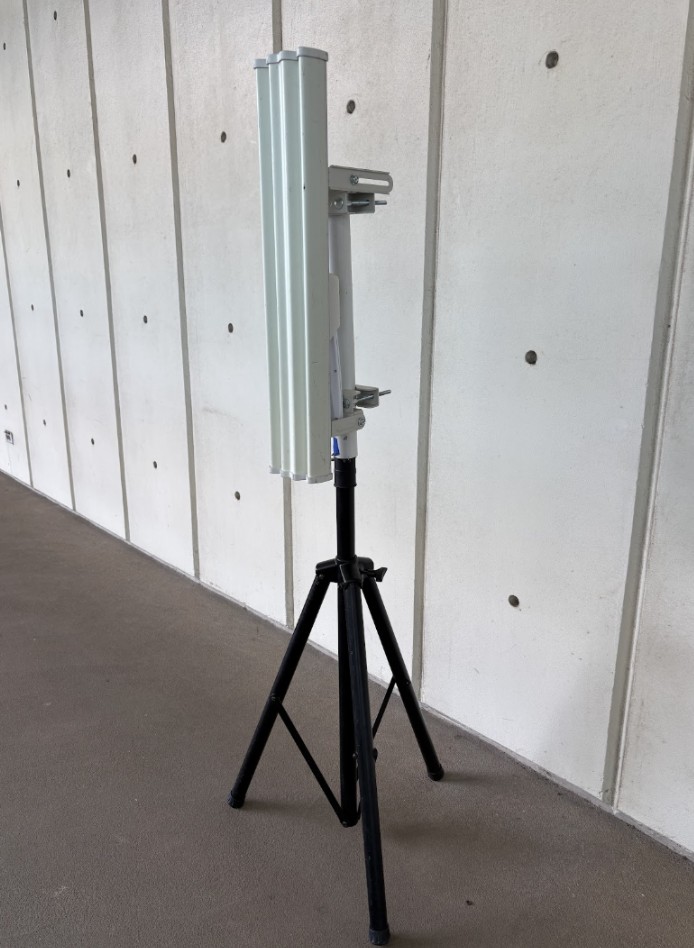
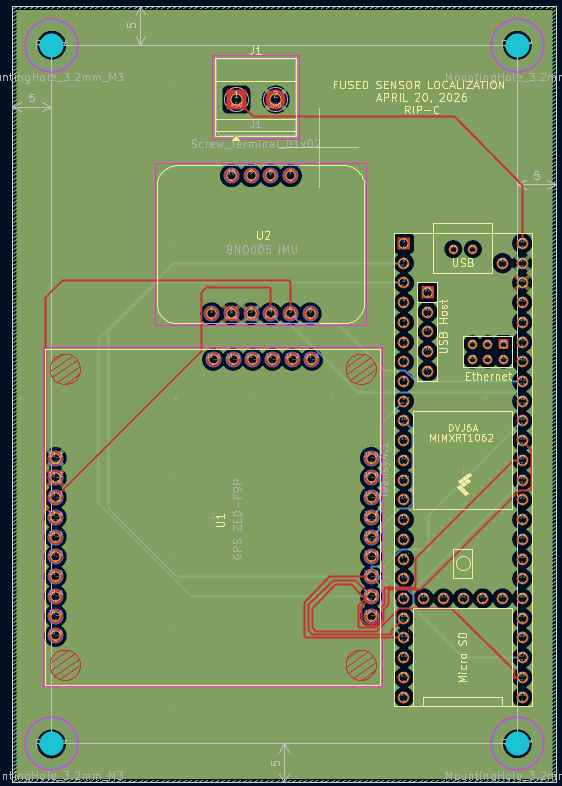
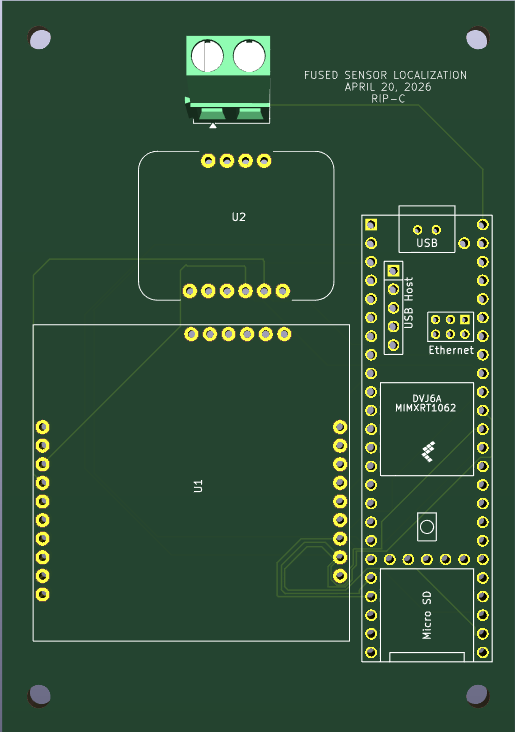
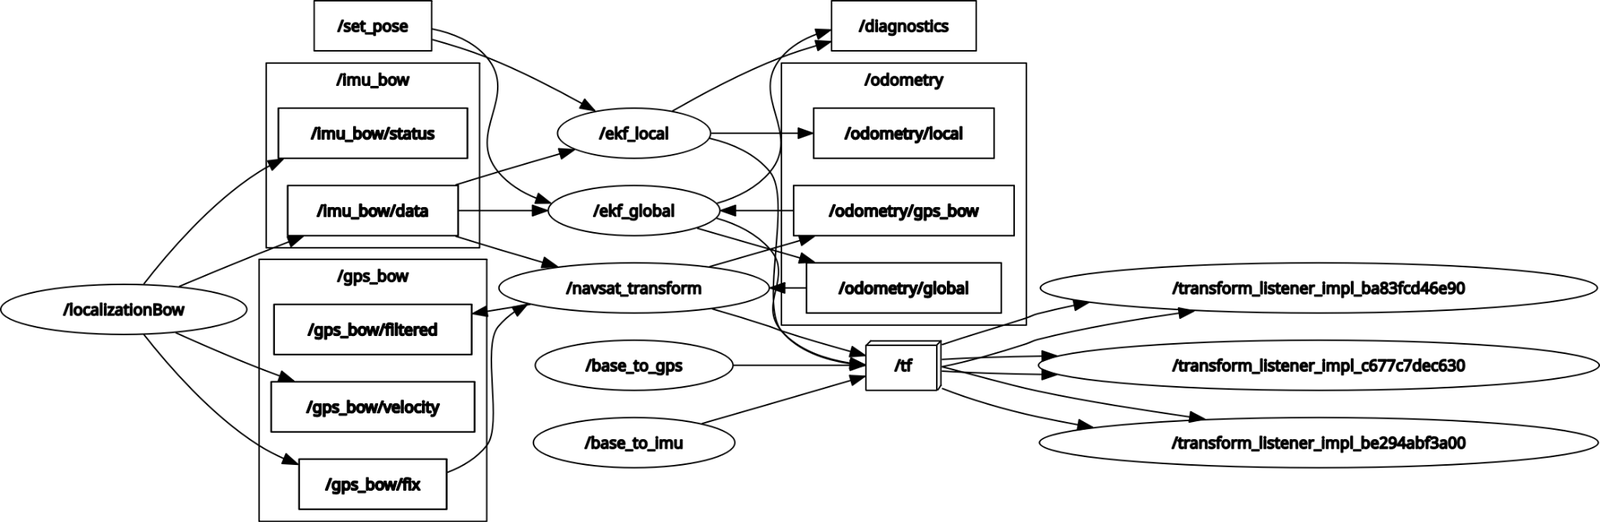
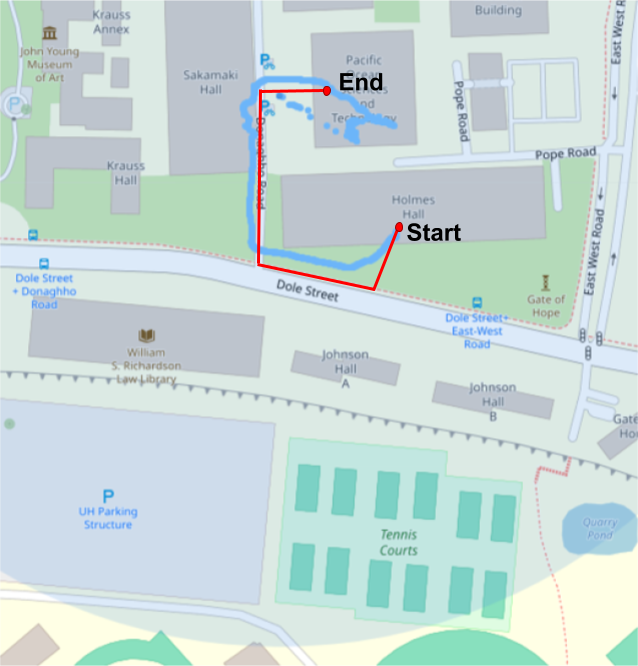
- Implemented an Extended Kalman Filter that fuses GPS, IMU, and wheel-encoder measurements with RTCM correction for centimeter-level real-time localization
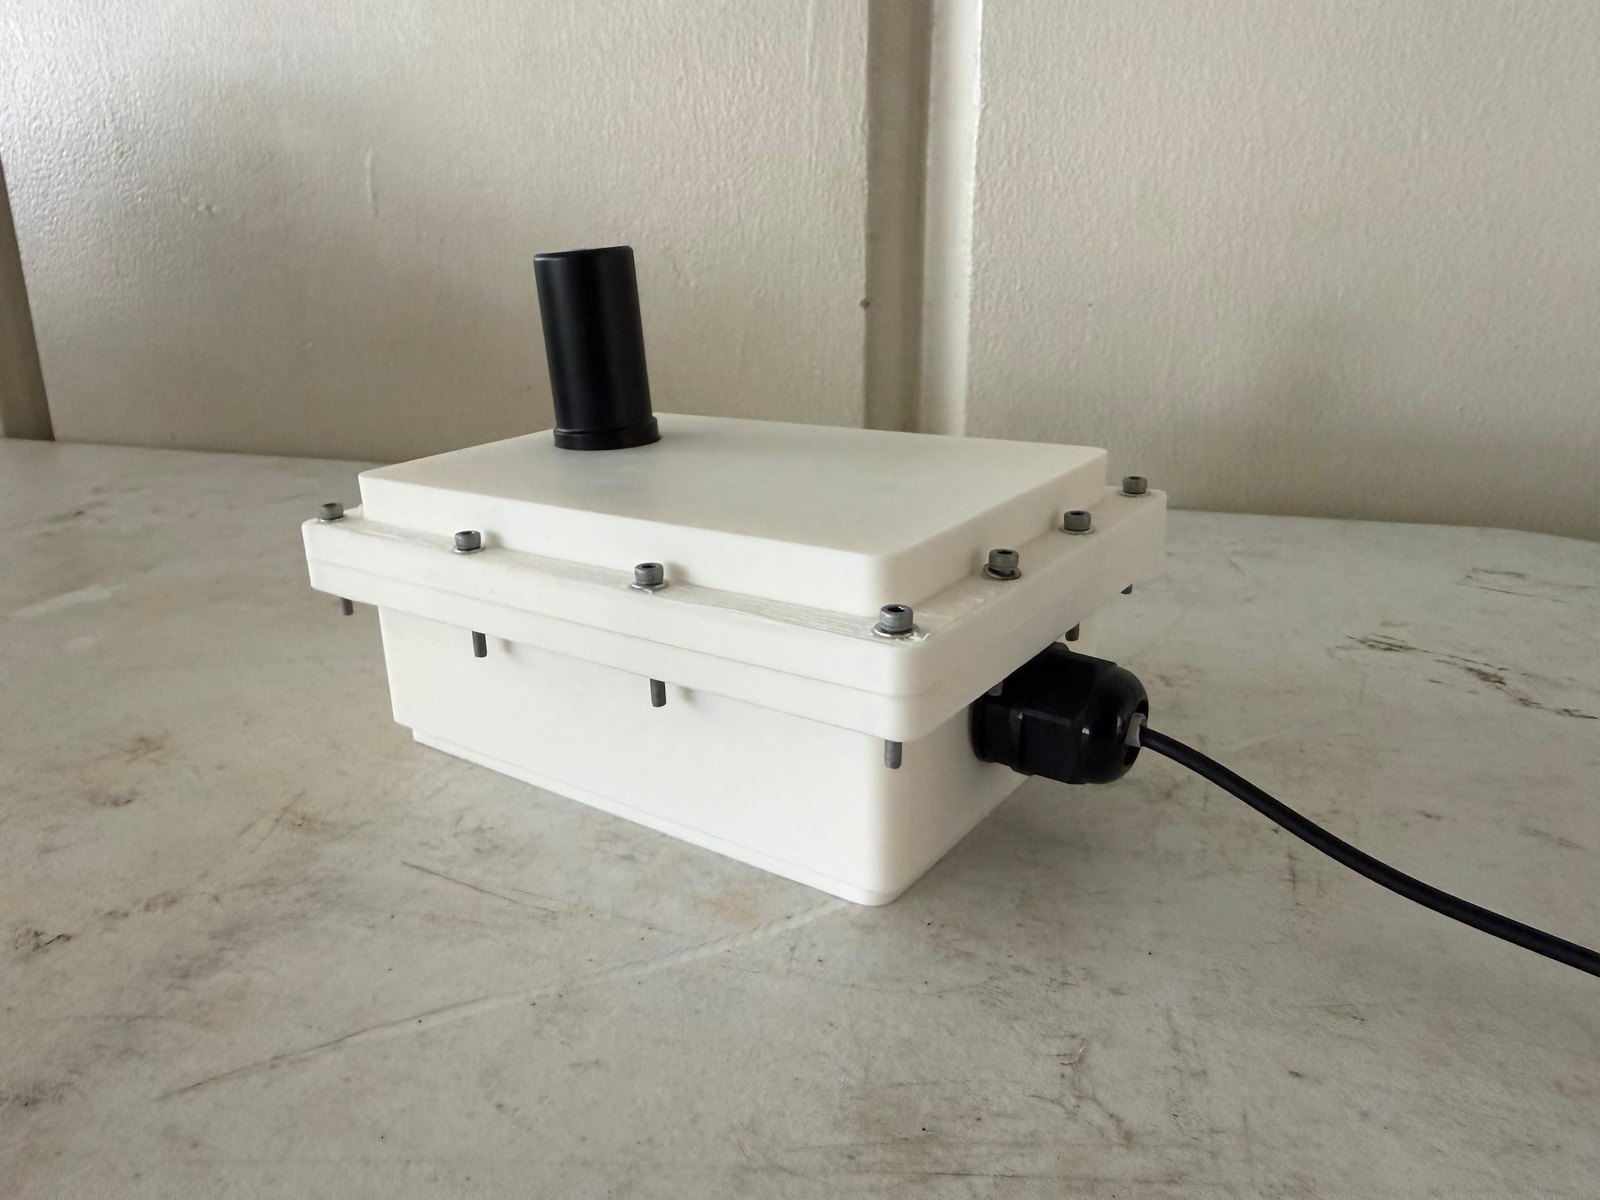
- Wrote low-level ROS2 drivers and hardware interfaces (I2C, UART, SPI, USB) to bring the vessel’s sensors and electronics online
Skills: FEA · ROS2 · C++ · EKF · PID control · Sensor Fusion · Gazebo