4-DOF Pick-and-Place Robot Arm — Lynxmotion AL5A
Published:

1 / 7
| Role: ME 452 Course Project · University of Hawaiʻi at Mānoa | When: Aug 2025 – Dec 2025 |
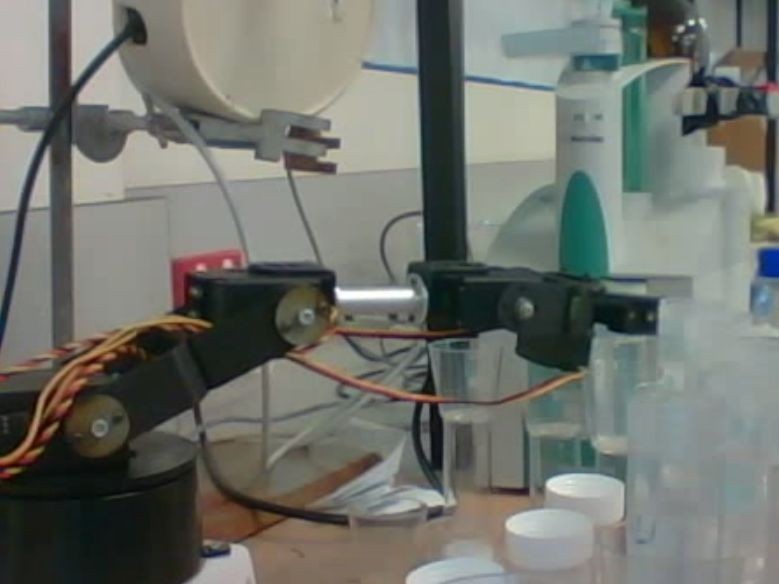
Programmed a Lynxmotion AL5A 4-DOF robot arm (base, shoulder, elbow, wrist, plus a gripper) on an Arduino to pick up two blocks and place them at a drop-off location.
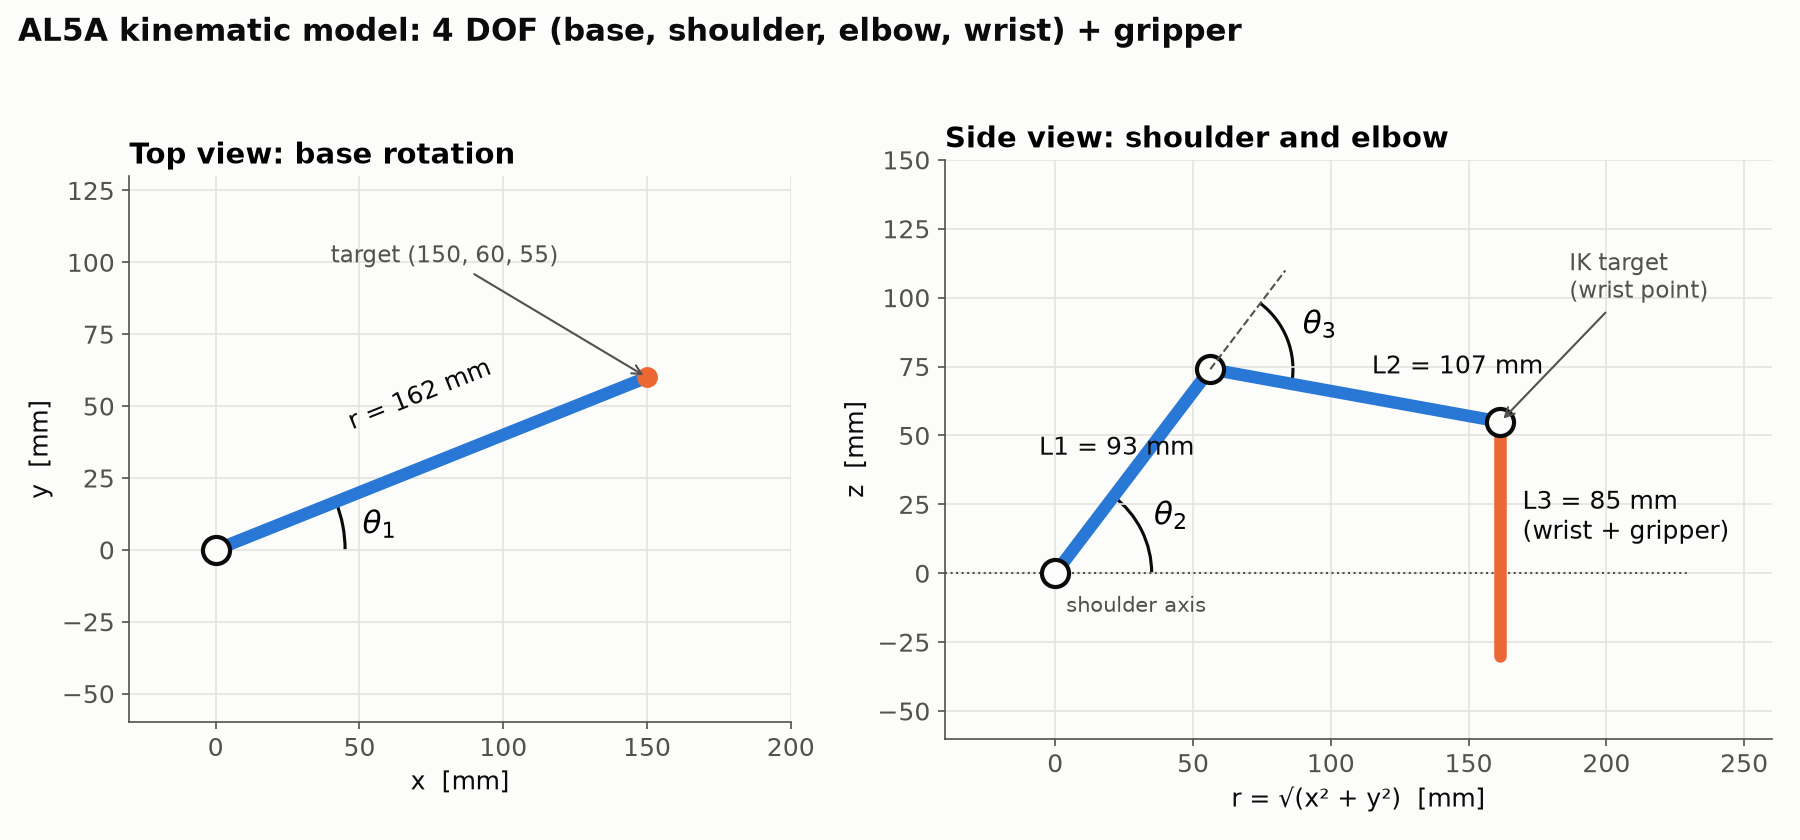
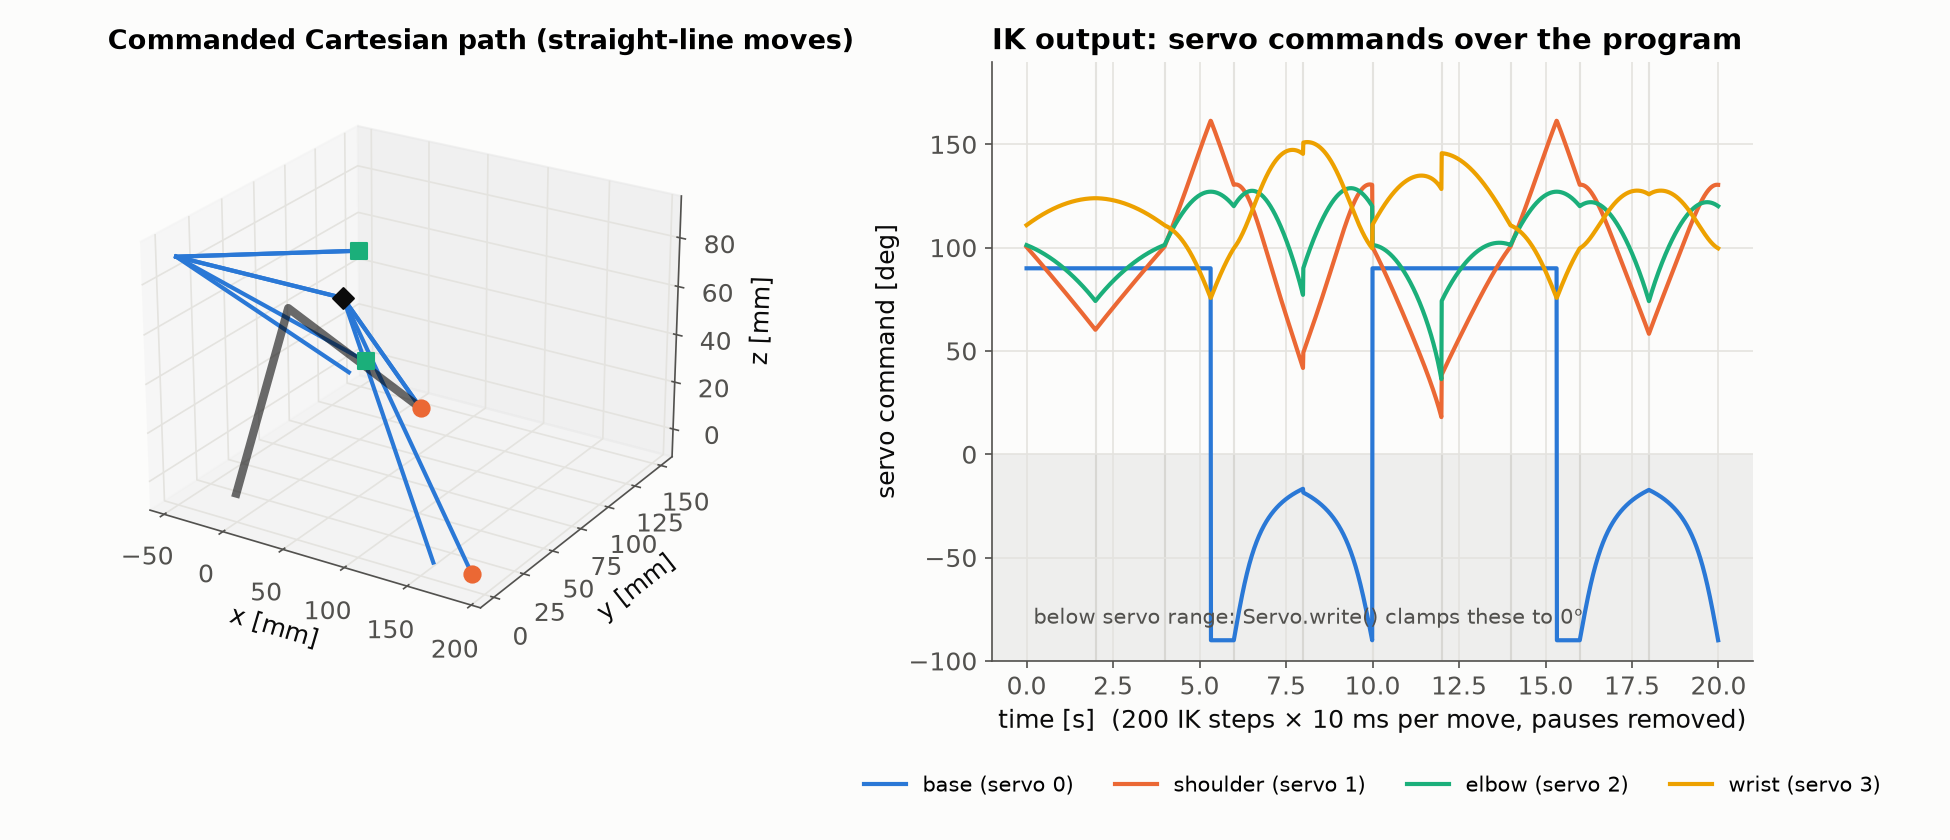
- Derived closed-form inverse kinematics that map a target wrist position (x, y, z) to base, shoulder, and elbow angles, with the wrist servo set from the shoulder and elbow angles to hold the gripper’s pitch constant
- Moved the gripper along straight Cartesian lines by interpolating each move into 200 IK steps, giving smooth, constant-speed motion between the pick and place points
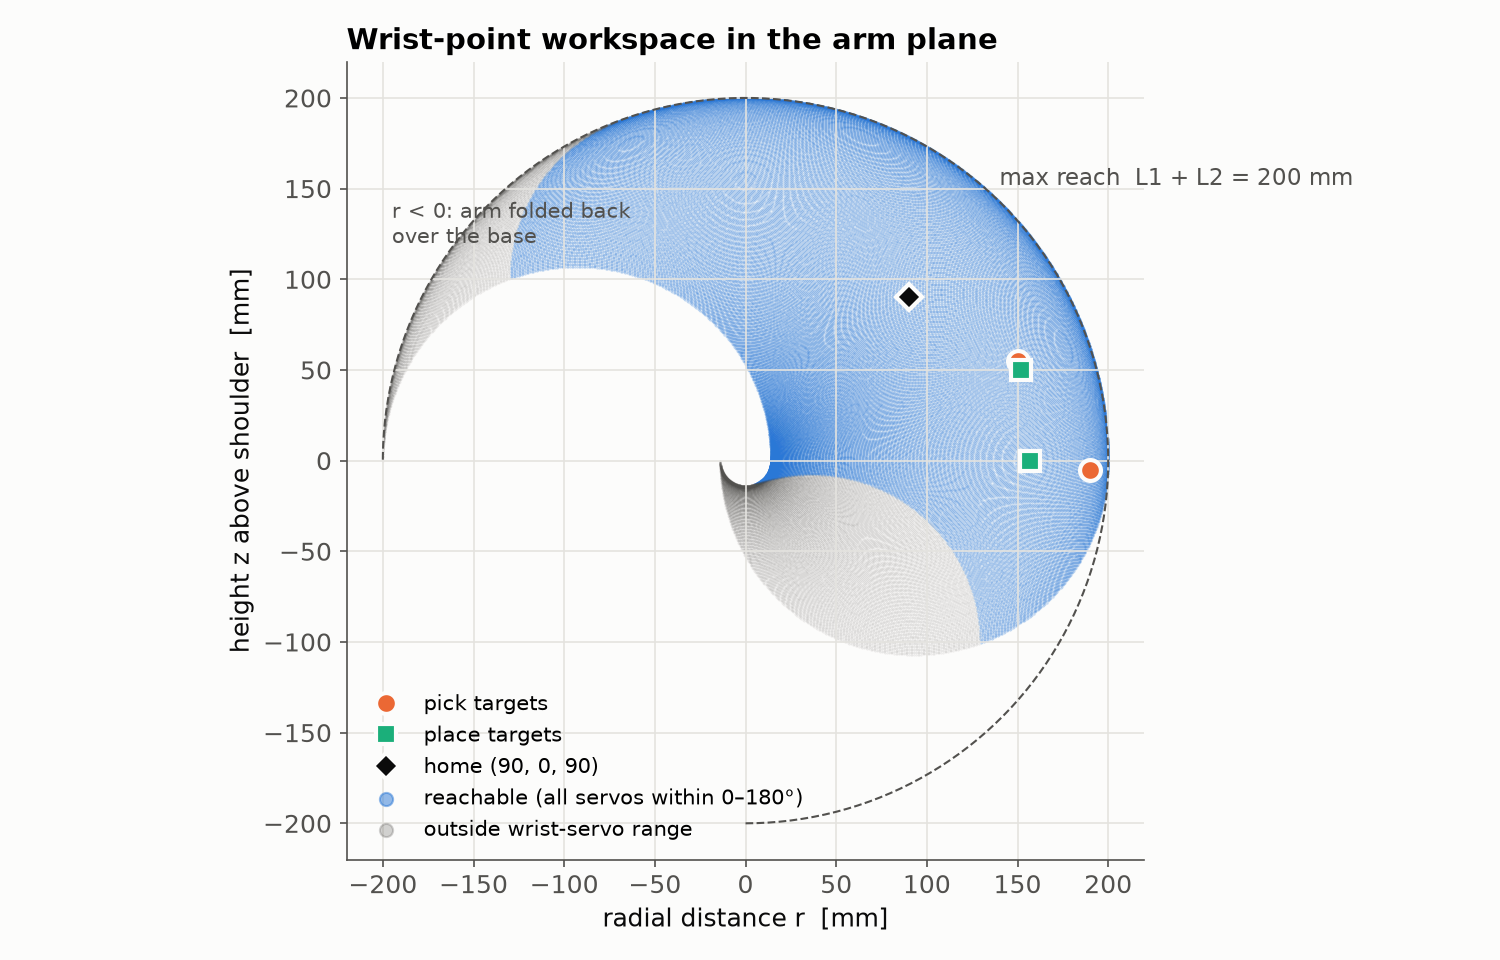
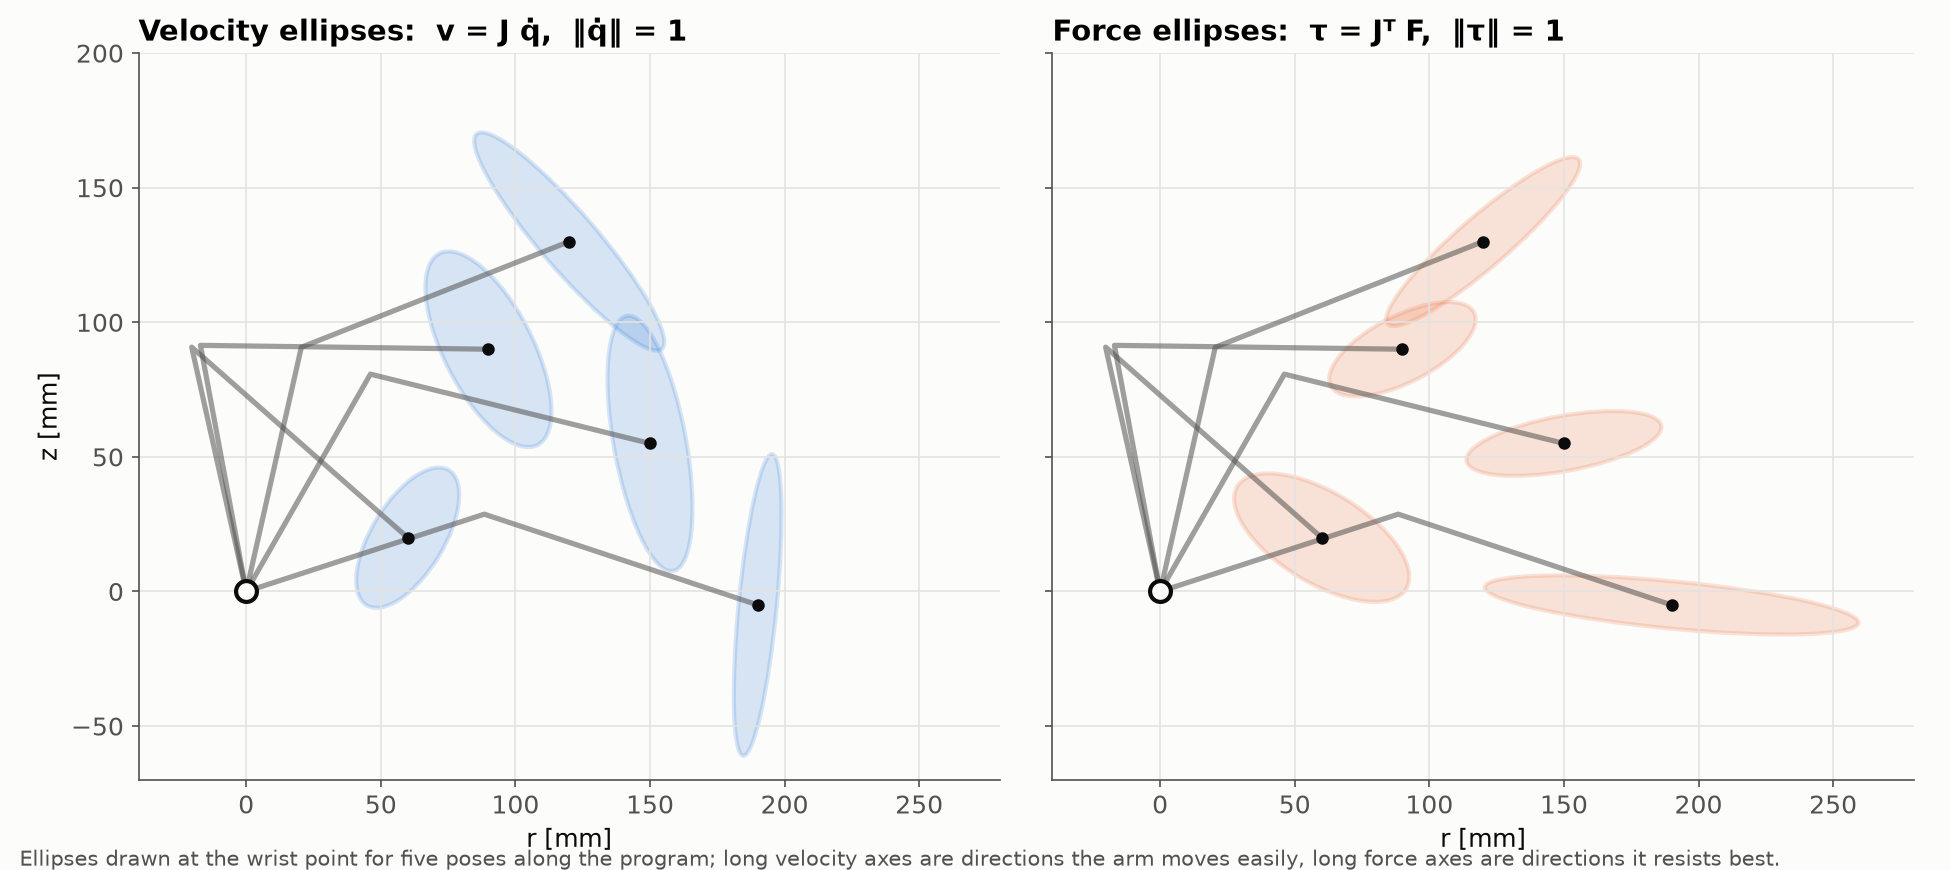
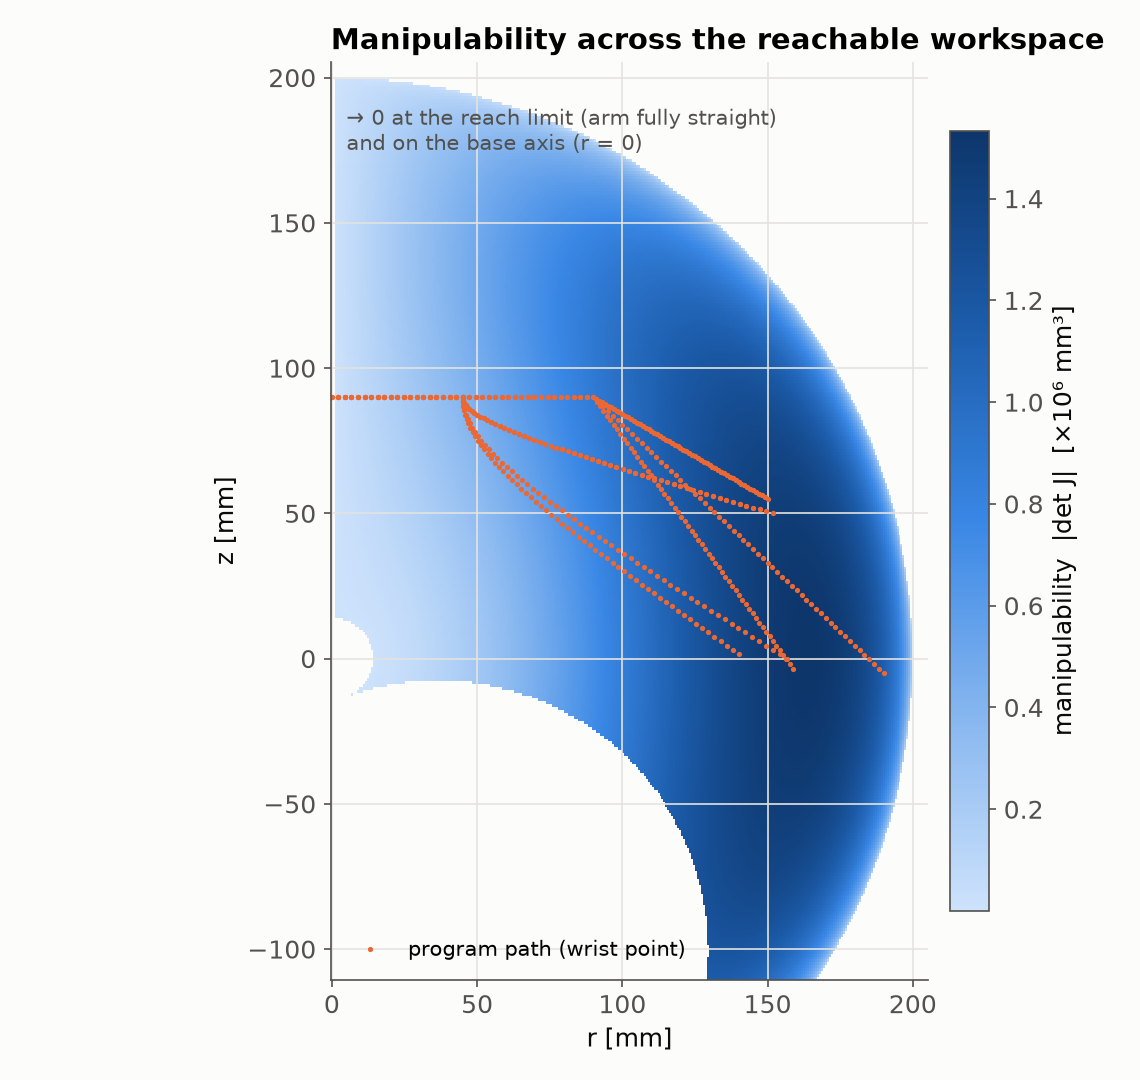
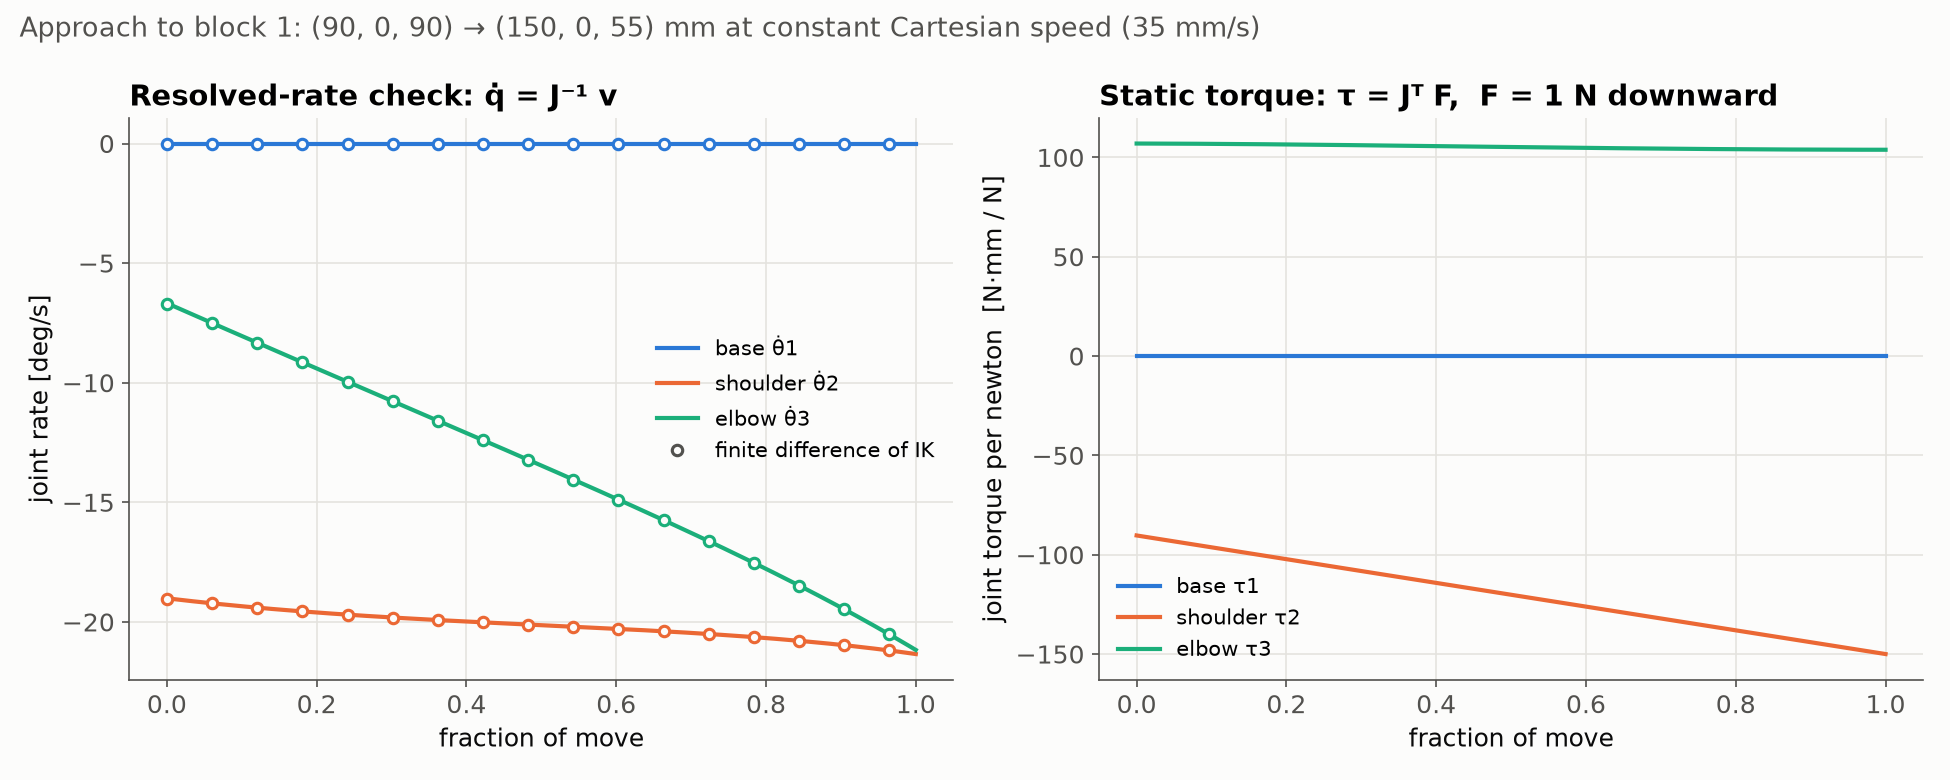
- Analyzed the arm’s workspace, manipulability, and Jacobian velocity and force behavior along the programmed path
Skills: Arduino / C++ · Inverse kinematics · Jacobian analysis · Trajectory planning