Modeling the Compliance of a 95A TPU FDM 3D-Printed Wheel
Published:
1 / 8
| Role: ME 671 Course Project · University of Hawaiʻi at Mānoa | When: Jan 2026 – May 2026 |
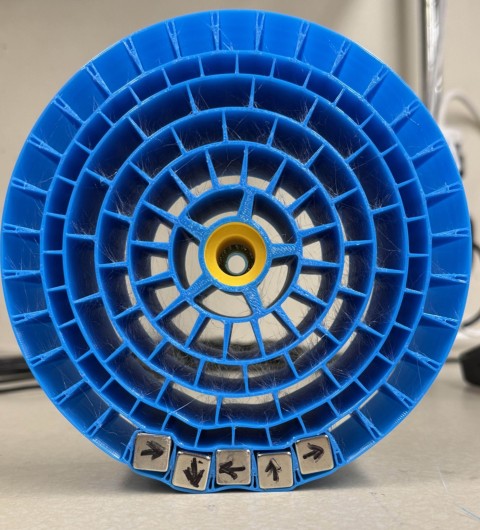
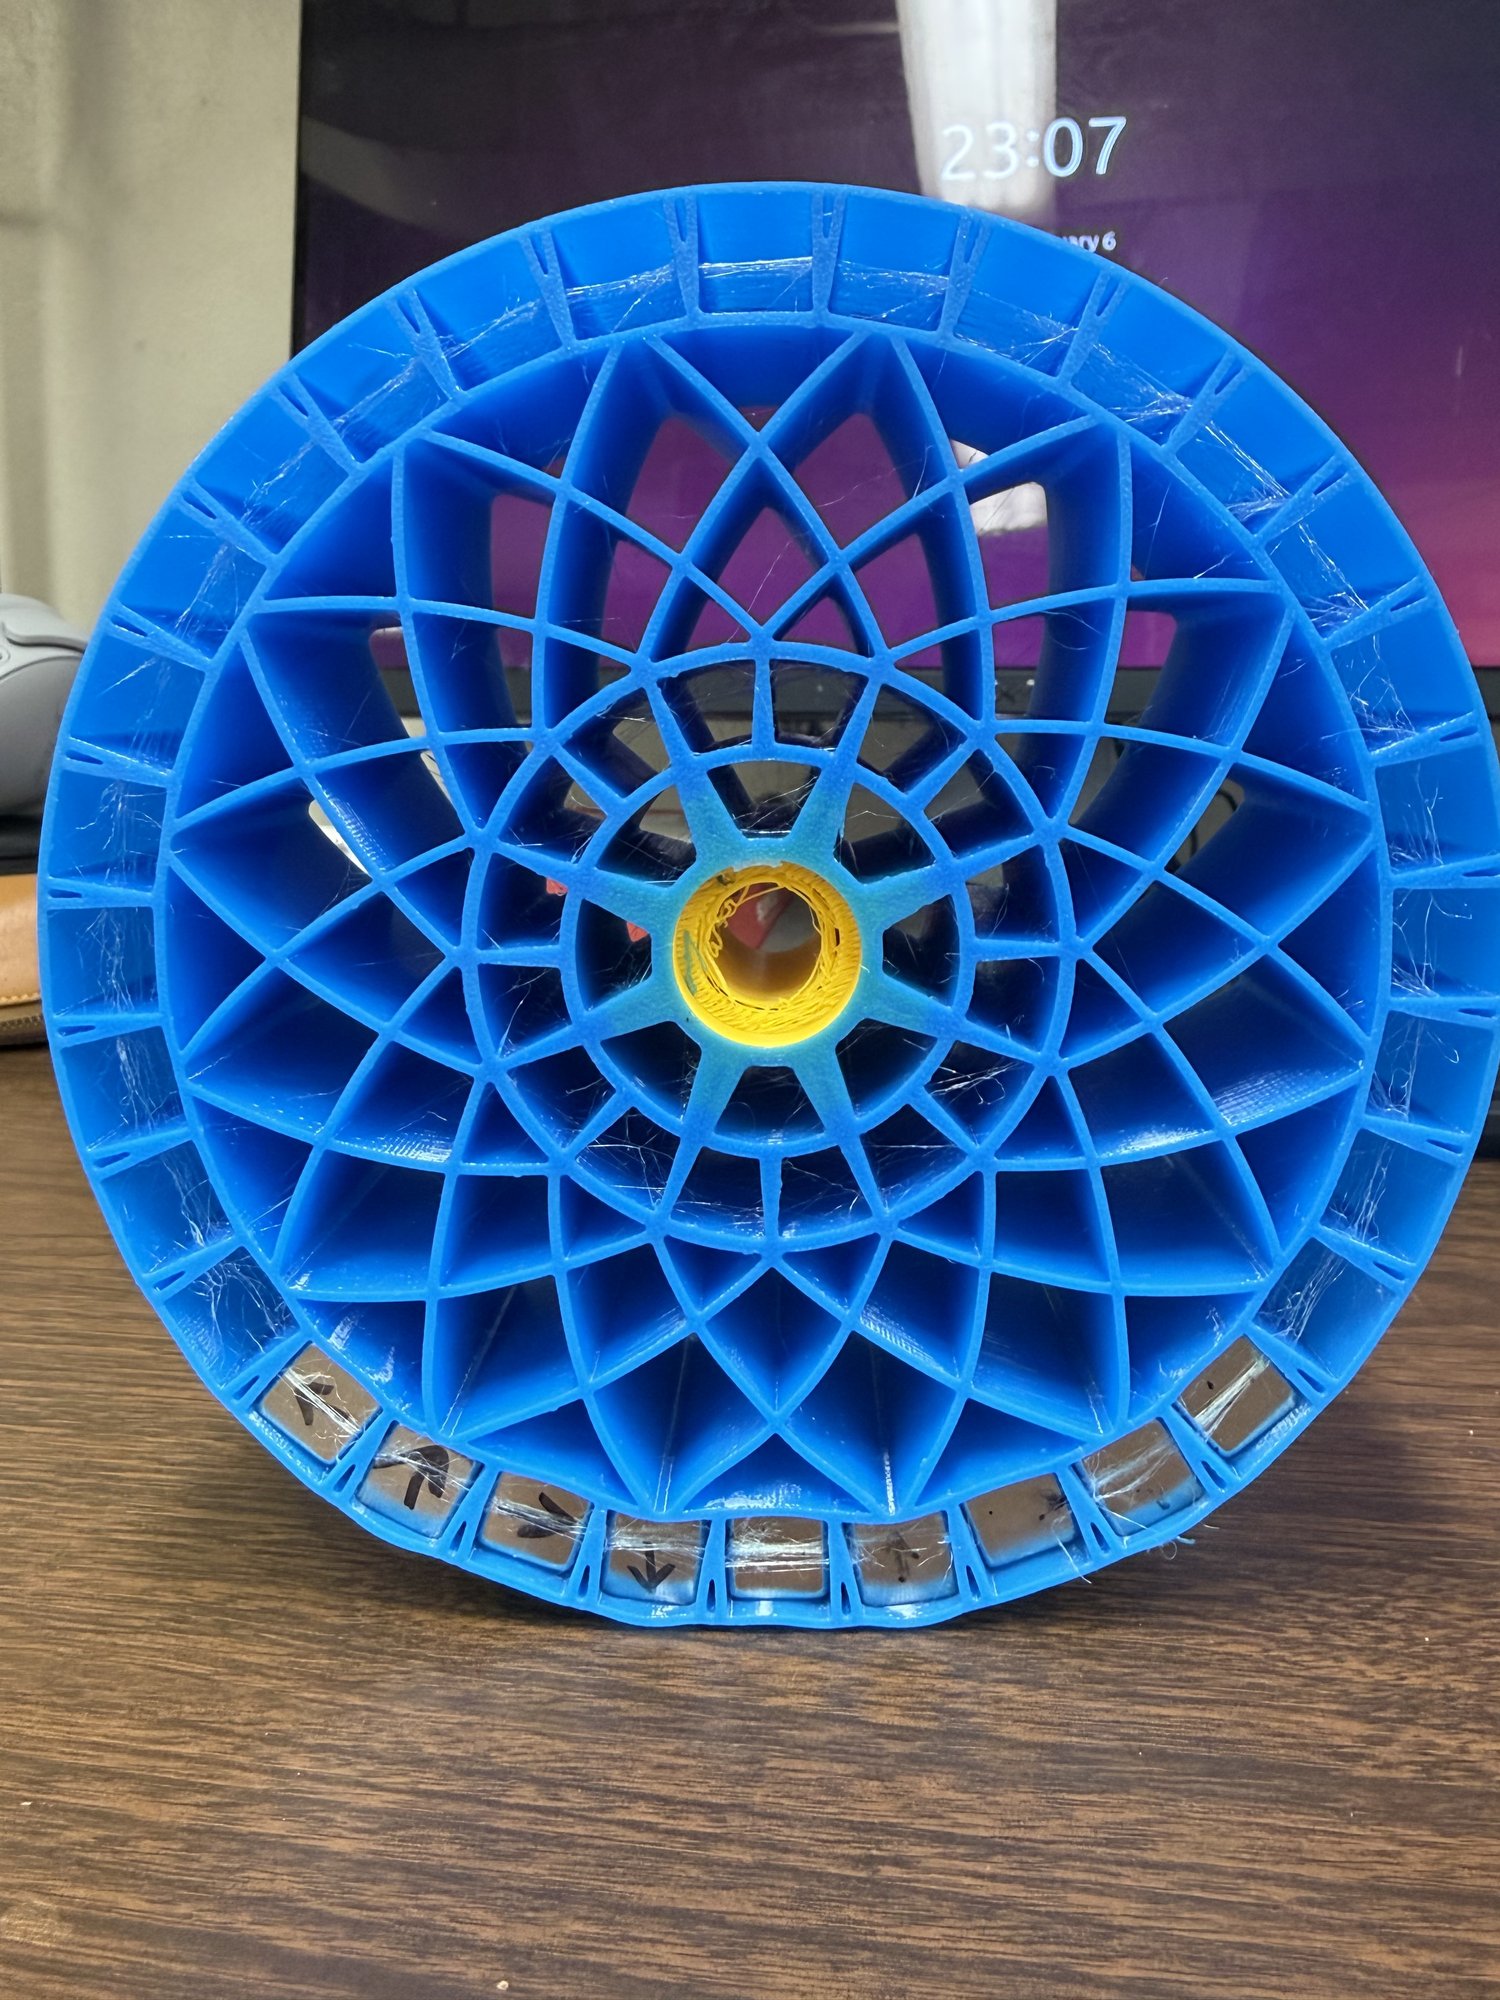
Built a simplified analytical model to predict how a 3D-printed magnetic-adhesion wheel deforms under robot weight and magnet loads, so wheel geometry can be tuned without relying on expensive FEA software.
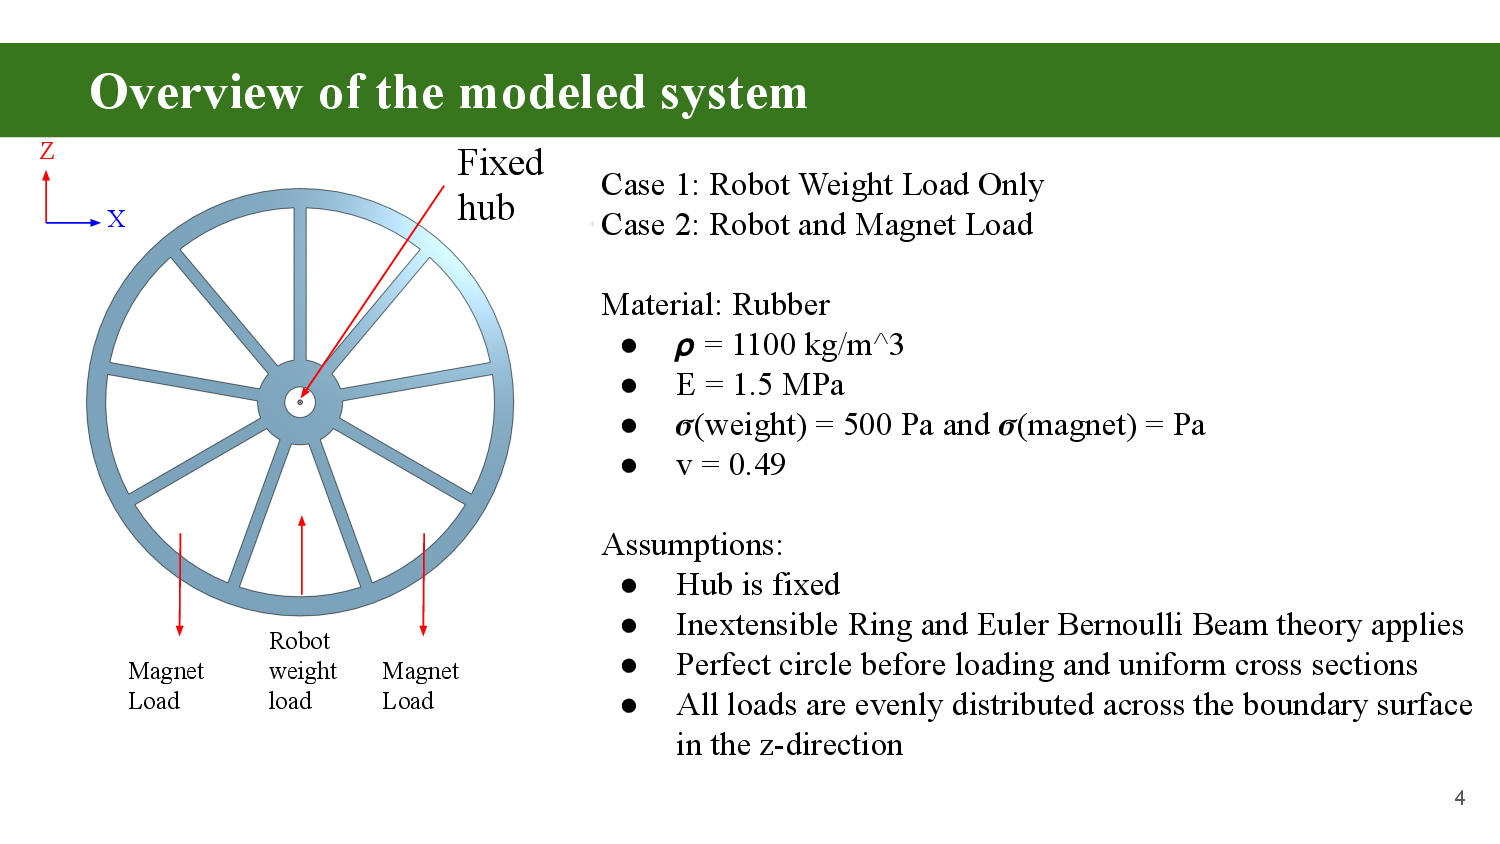
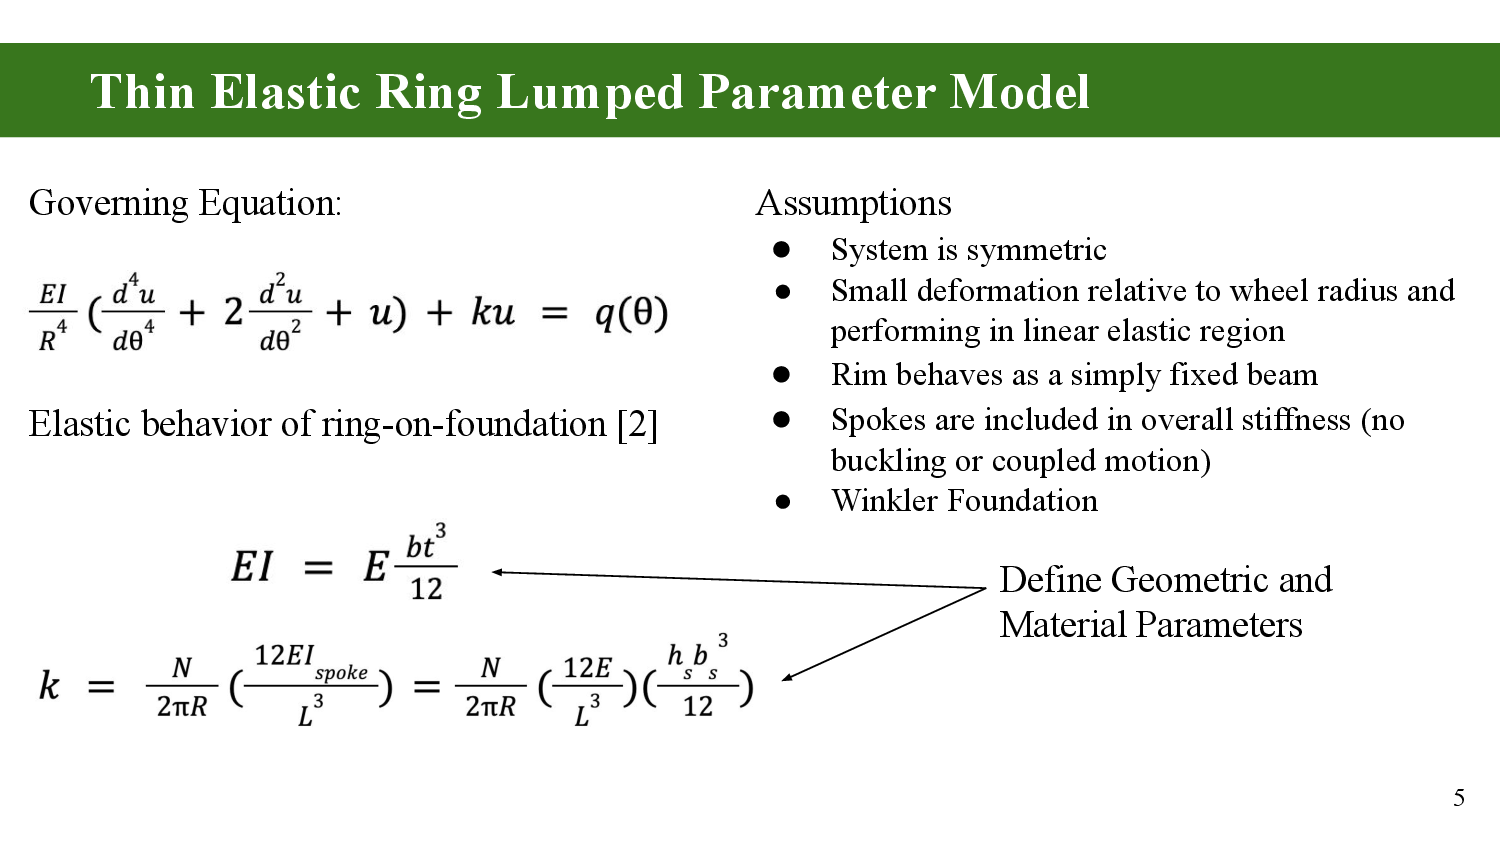
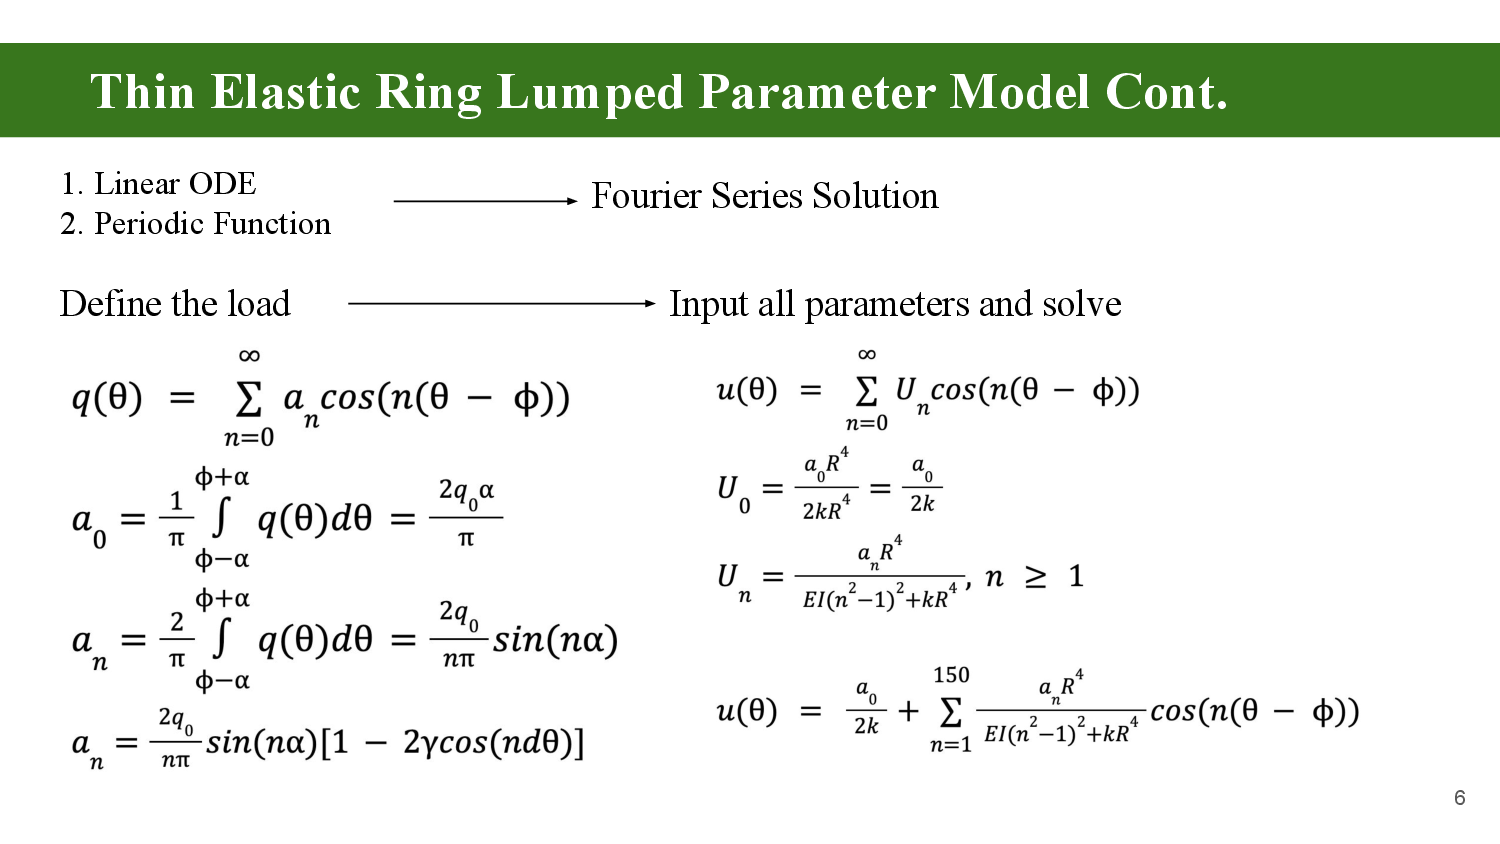
- Modeled the rim as a thin elastic ring on a Winkler foundation, with the spokes lumped into an equivalent radial stiffness, and solved the patch-loaded ring analytically with a Fourier series
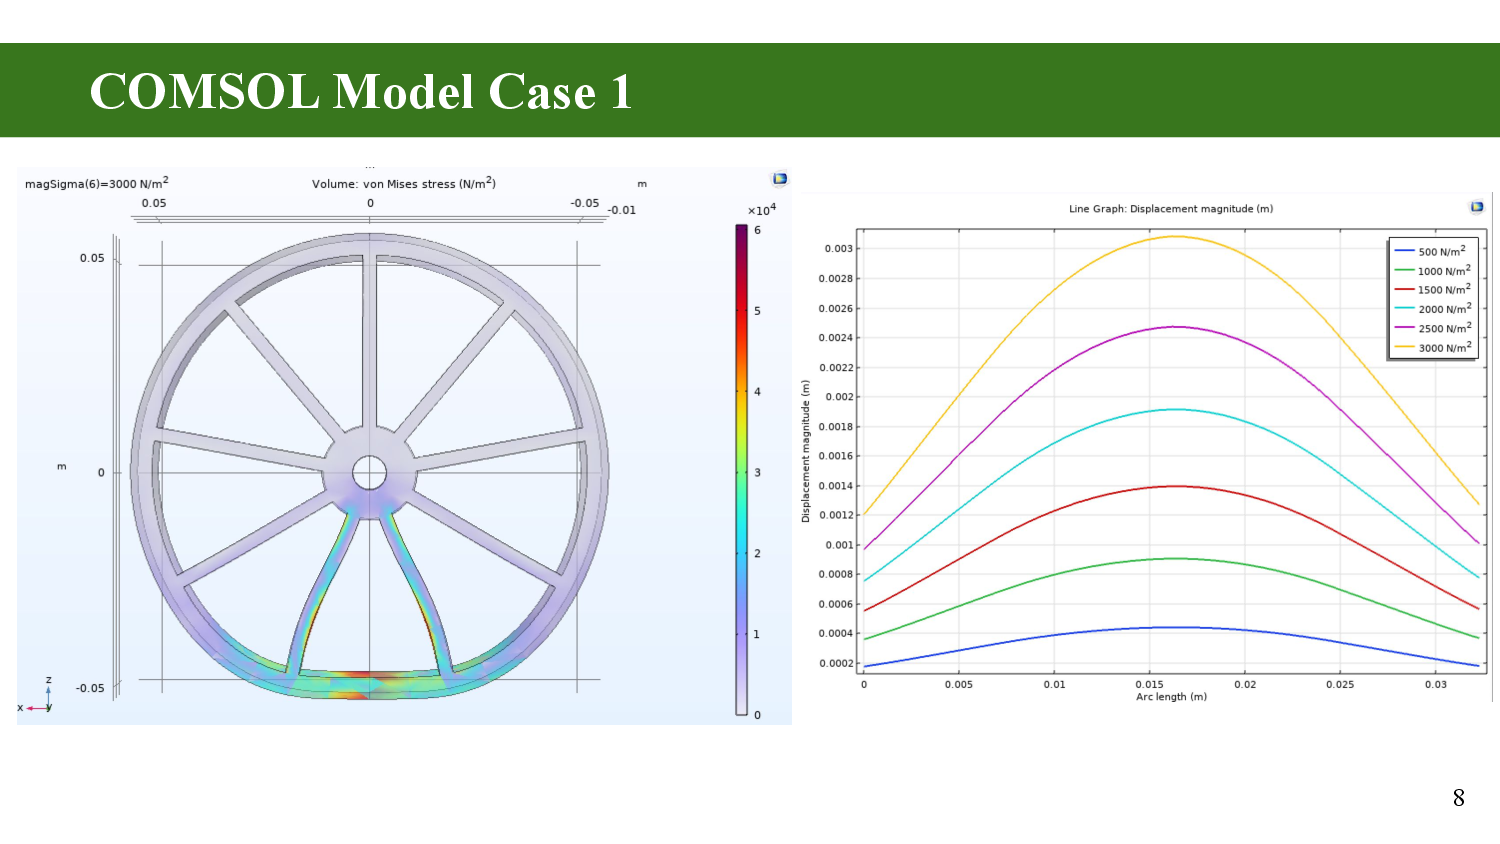
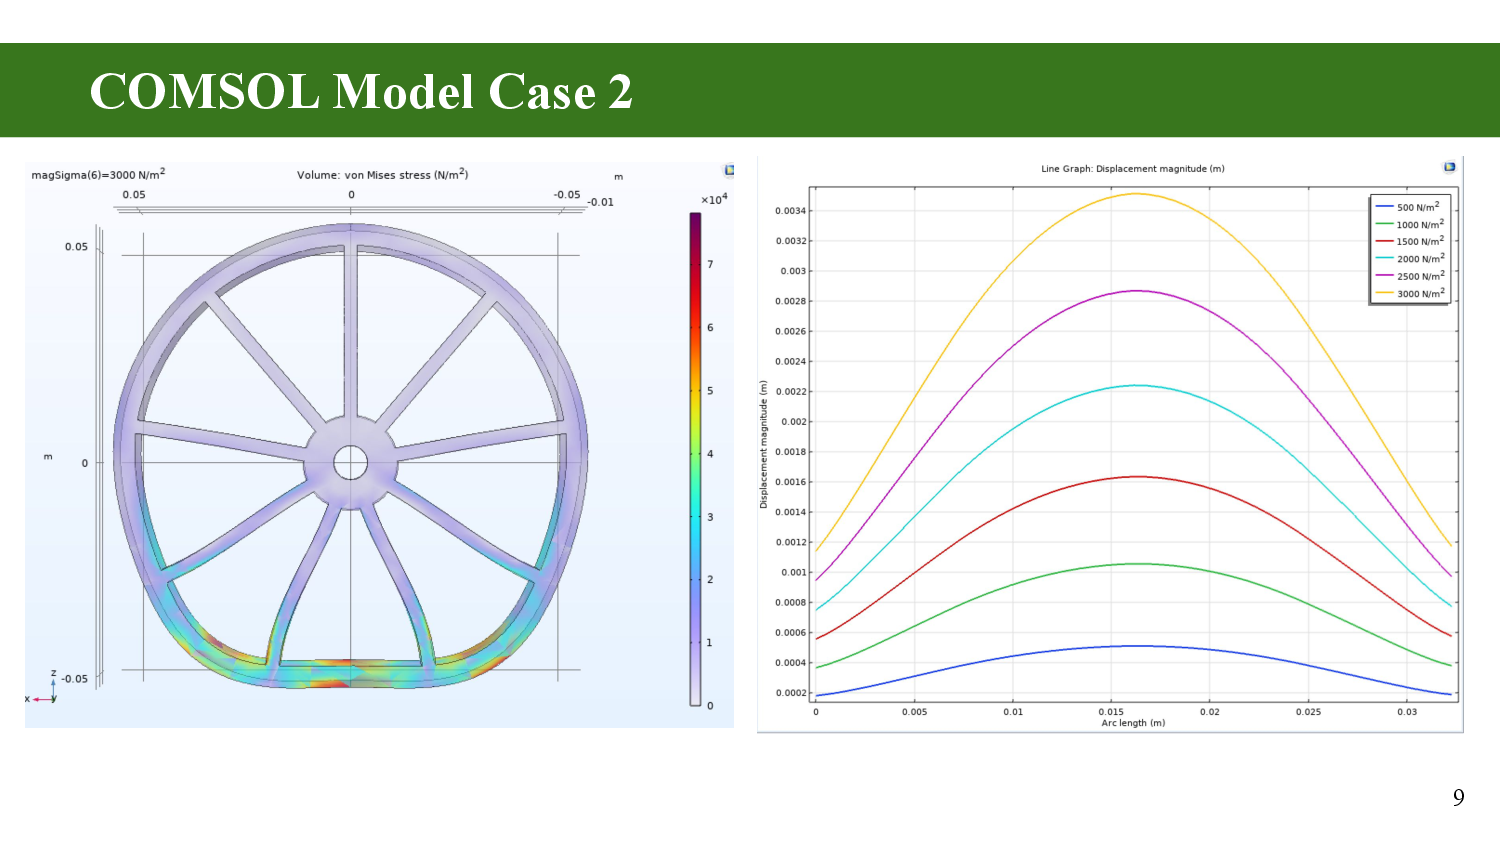
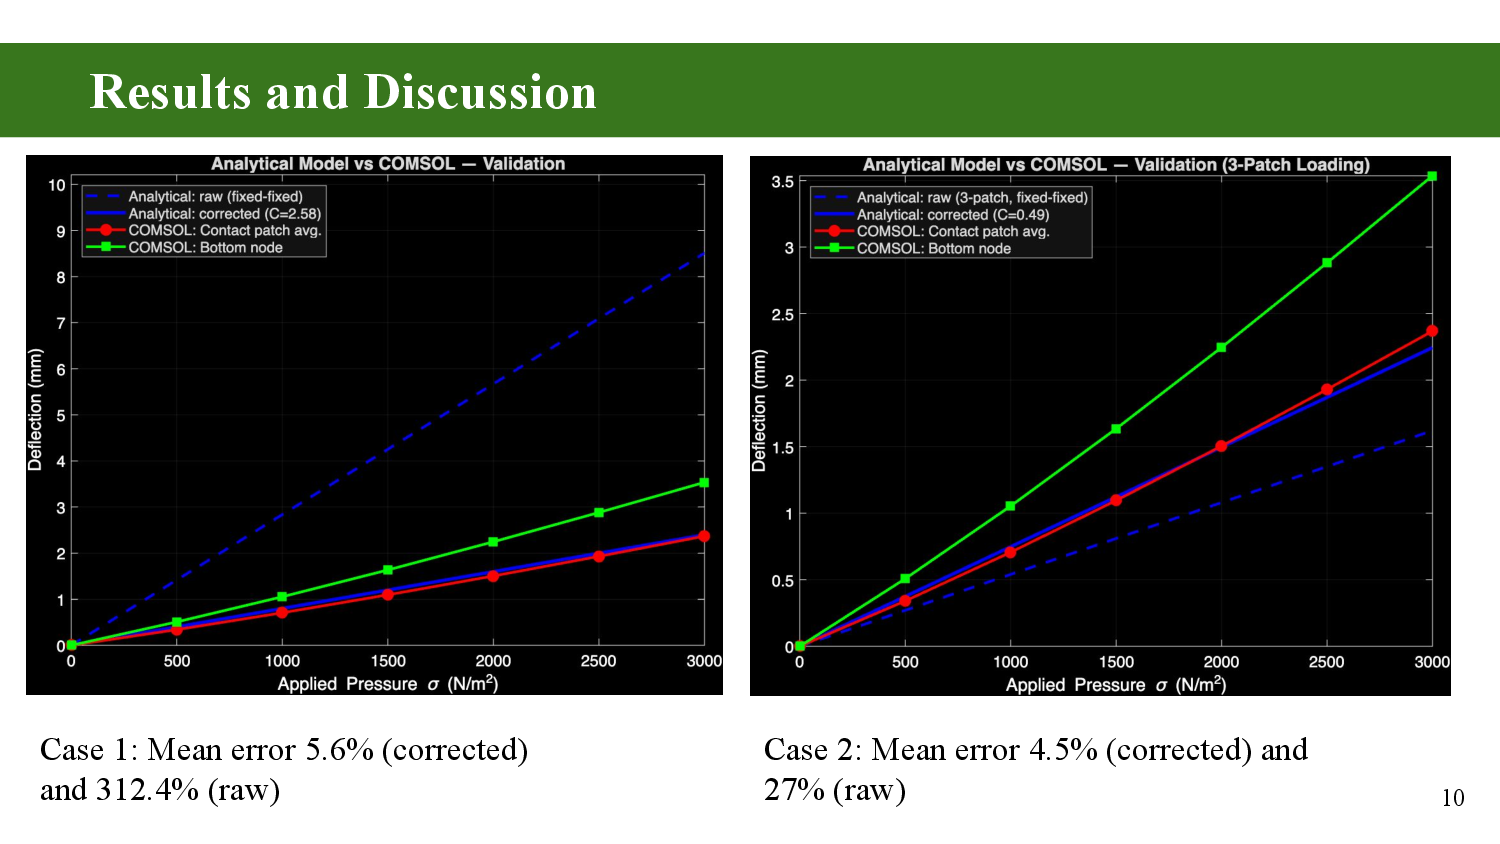
- Validated against COMSOL for two load cases (robot weight only, and robot weight plus magnet loads); the corrected model matched COMSOL with 5.6% and 4.5% mean error
- Swept spoke count, spoke width, and rim thickness to show that spoke geometry dominates wheel compliance while rim thickness has little effect
Skills: MATLAB · COMSOL Multiphysics · Analytical modeling · Fourier series · Euler–Bernoulli beam theory