Bio-Inspired Soft Robotic Manta Ray — SAIL Lab
Published:
1 / 7
| Role: Soft Robotics Research Assistant · SAIL Lab | When: May 2024 – May 2025 |
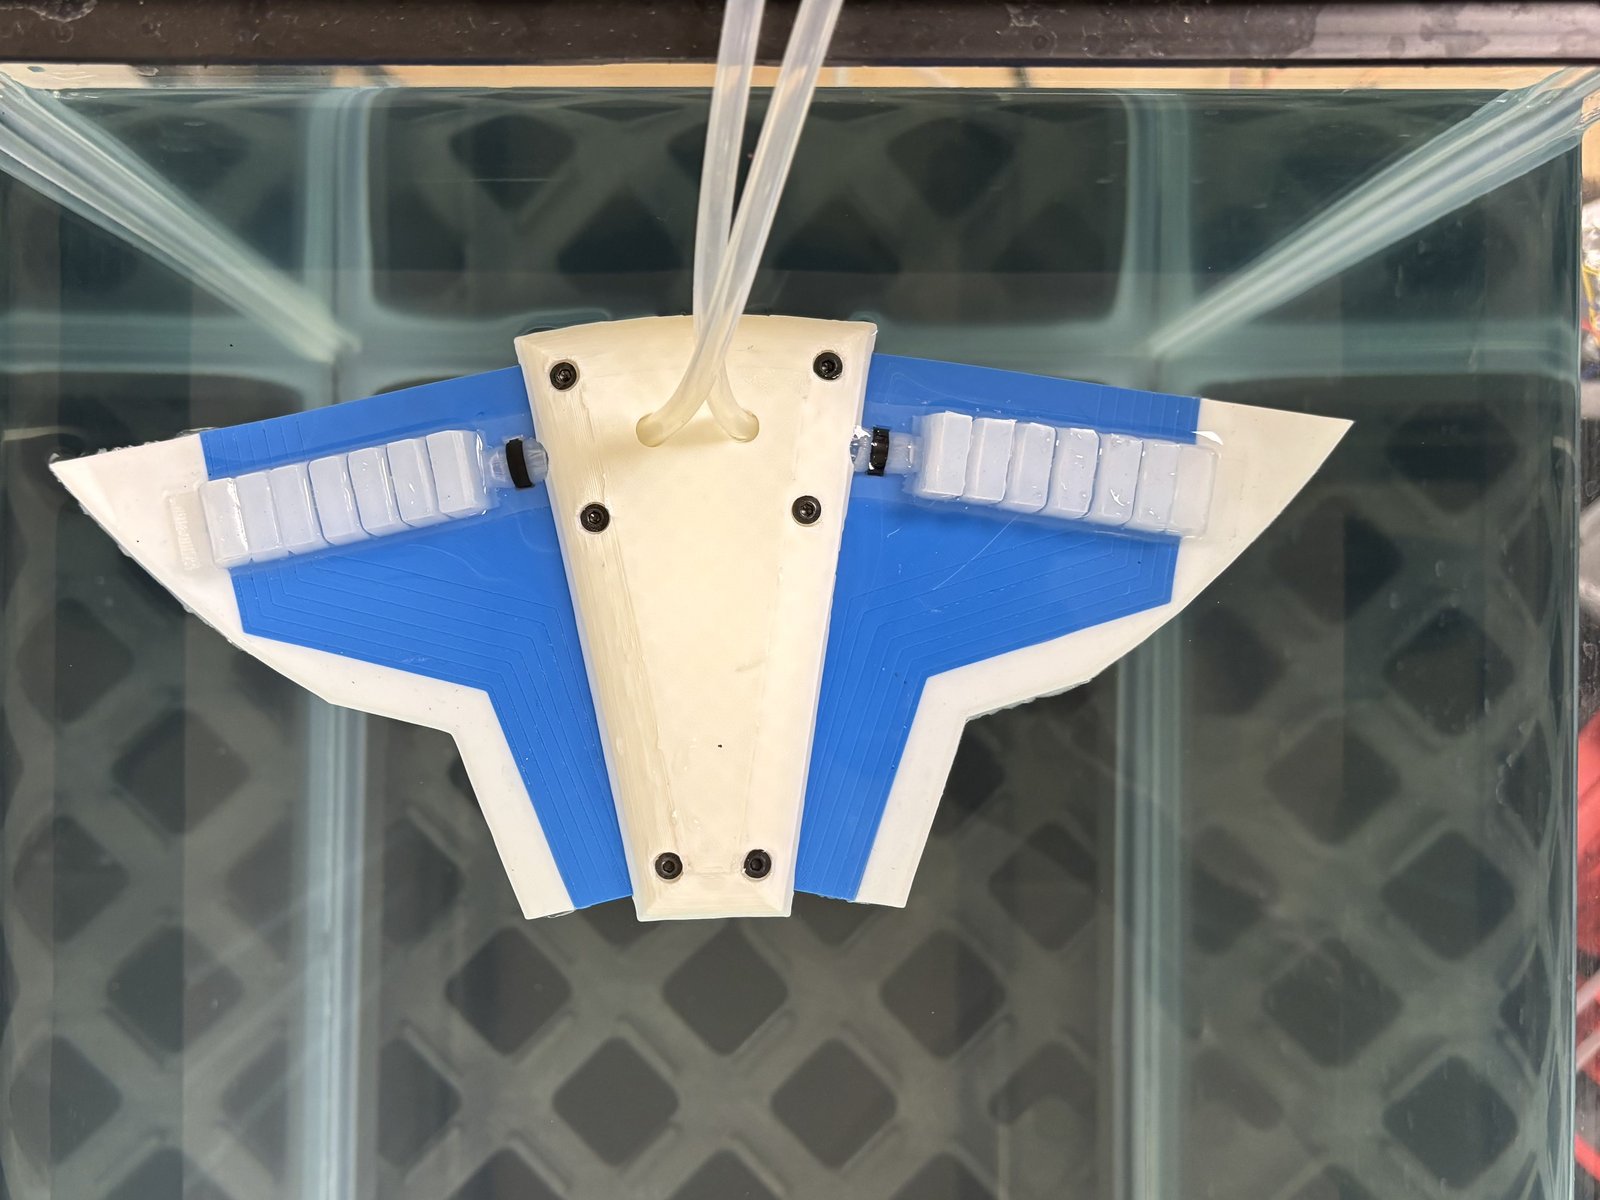
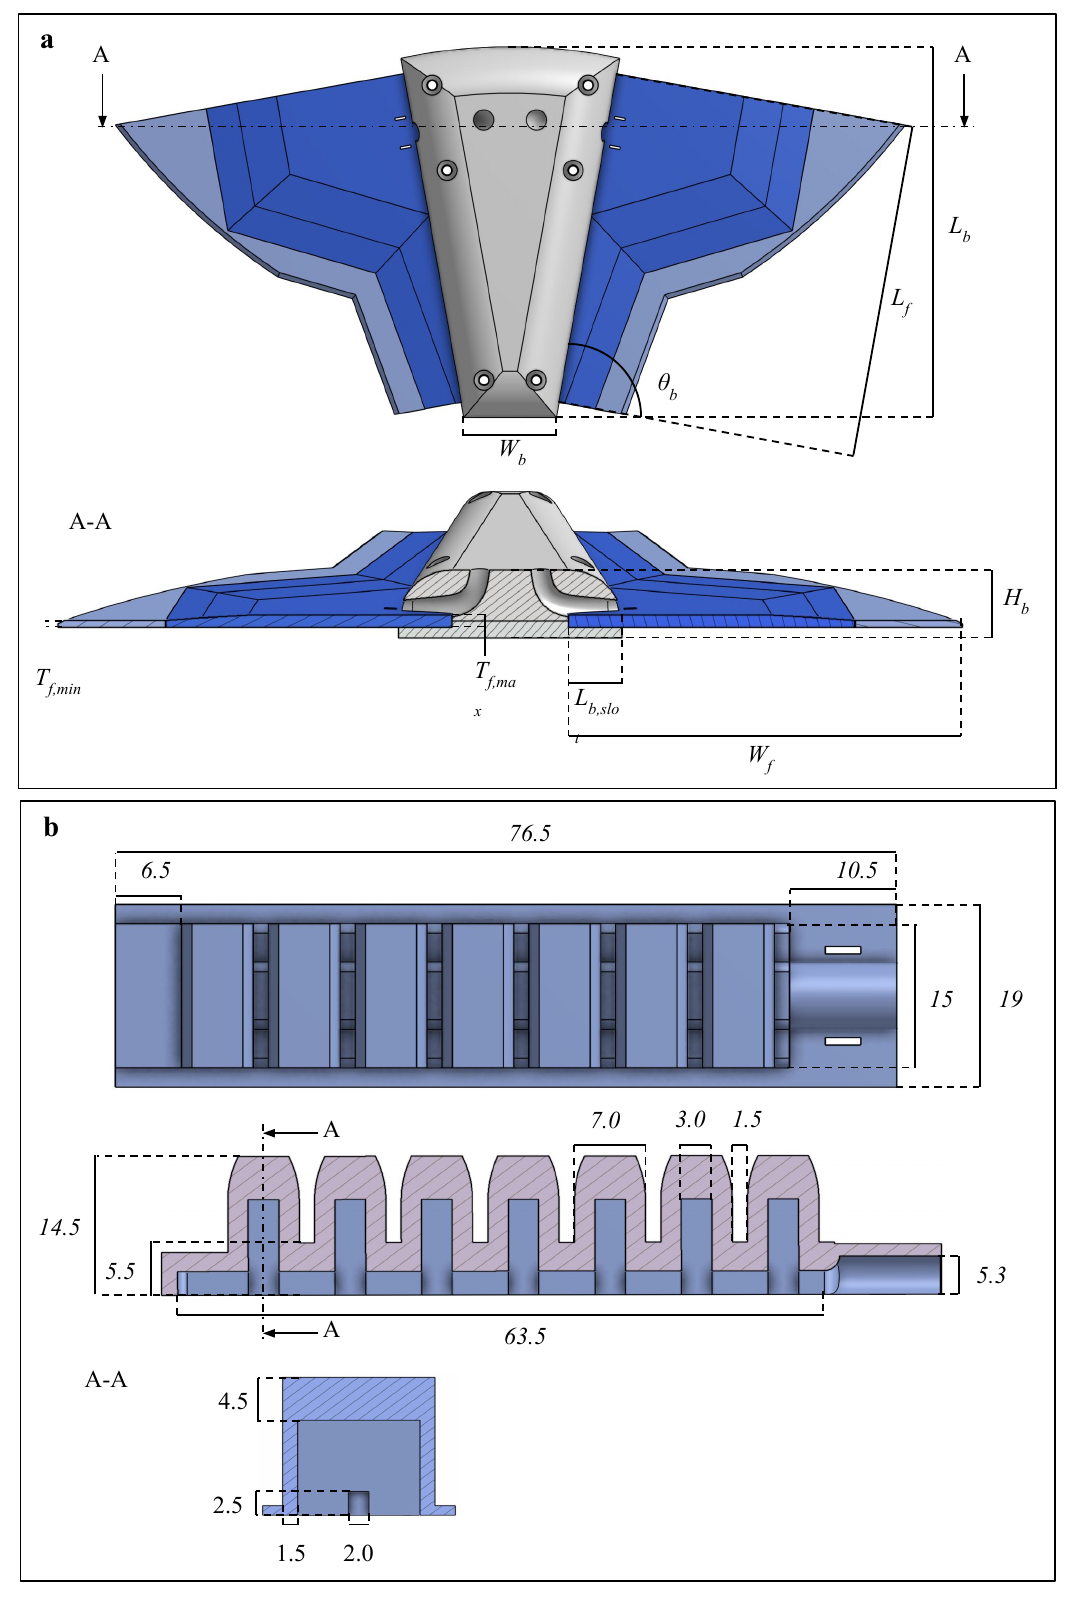
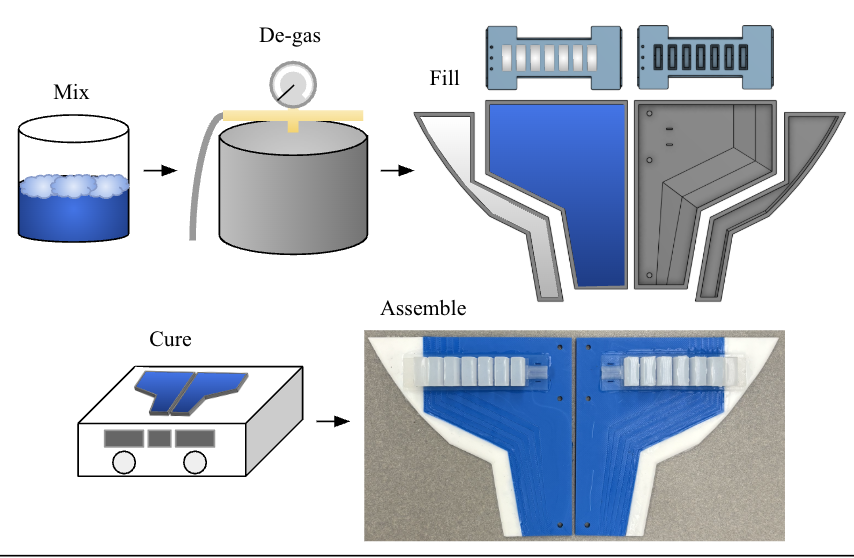
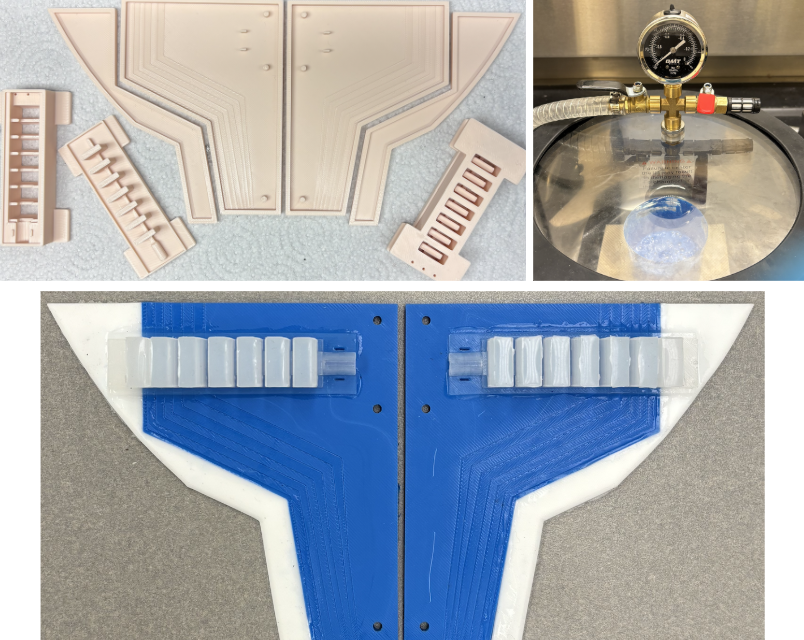
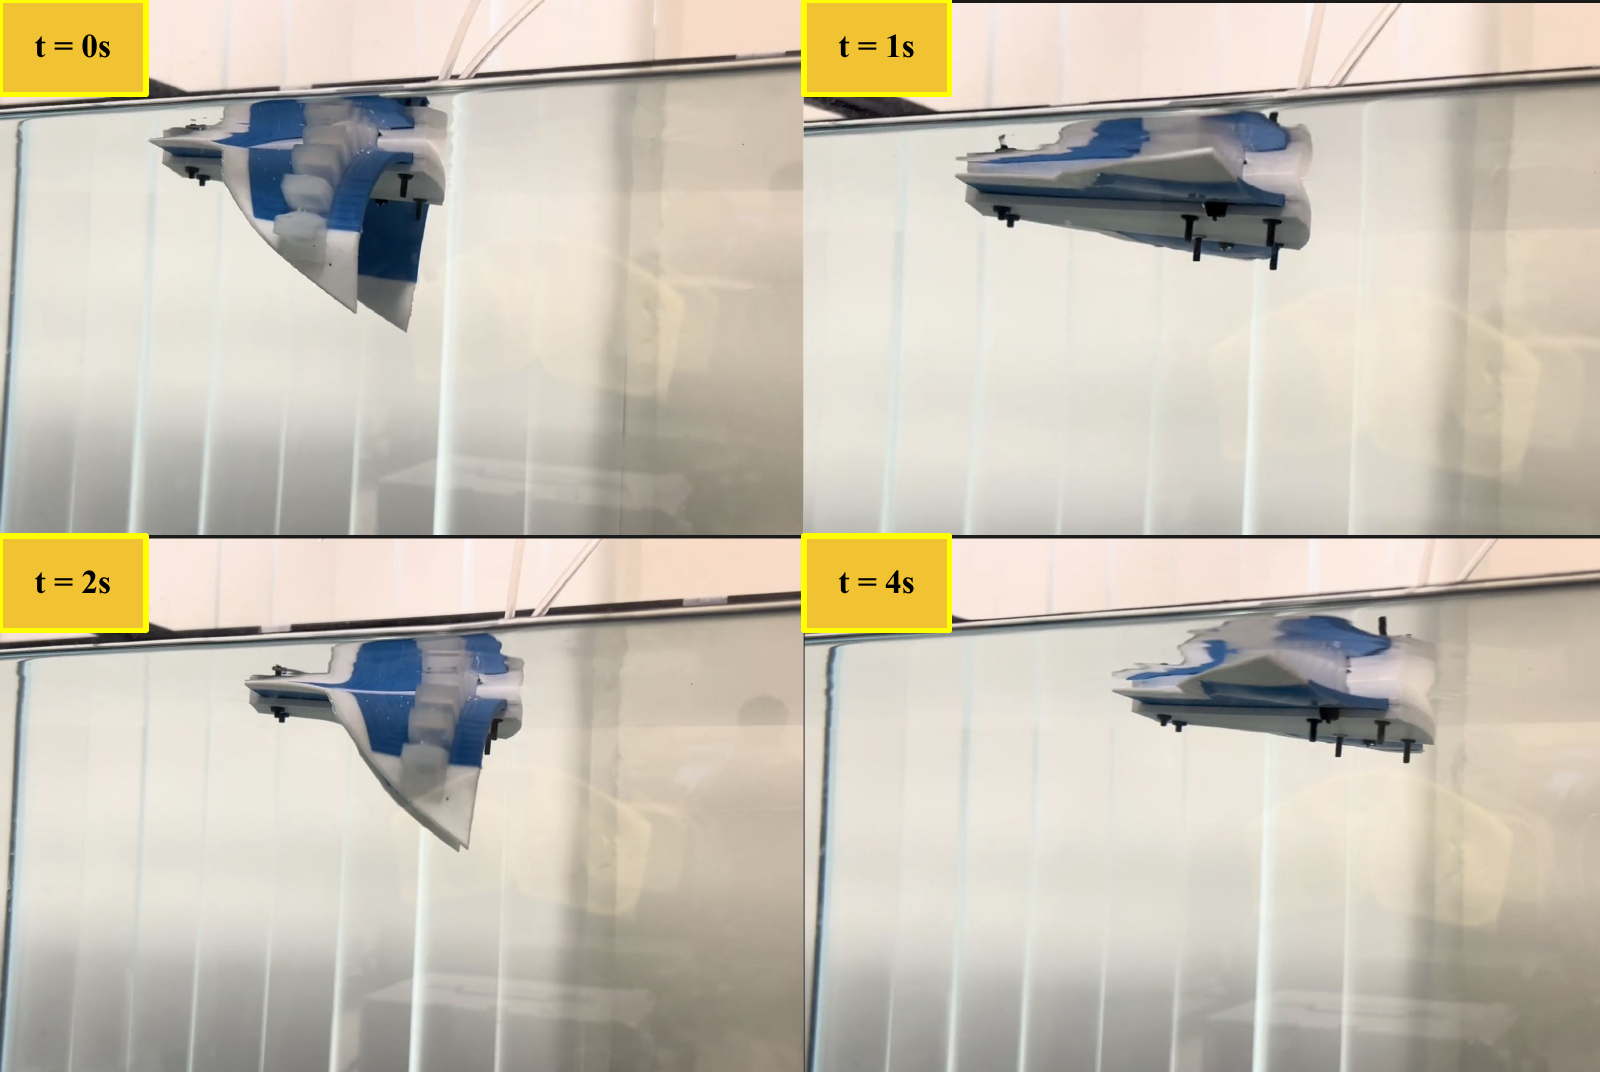
Designed and iterated pectoral fin prototypes cast in Dragon Skin silicone from FDM-printed molds, then wrote the embedded software that drives their pneumatic actuation.
- Designed iterative pectoral fin prototypes in Onshape, fabricated as FDM-printed molds cast in Dragon Skin silicone rubber
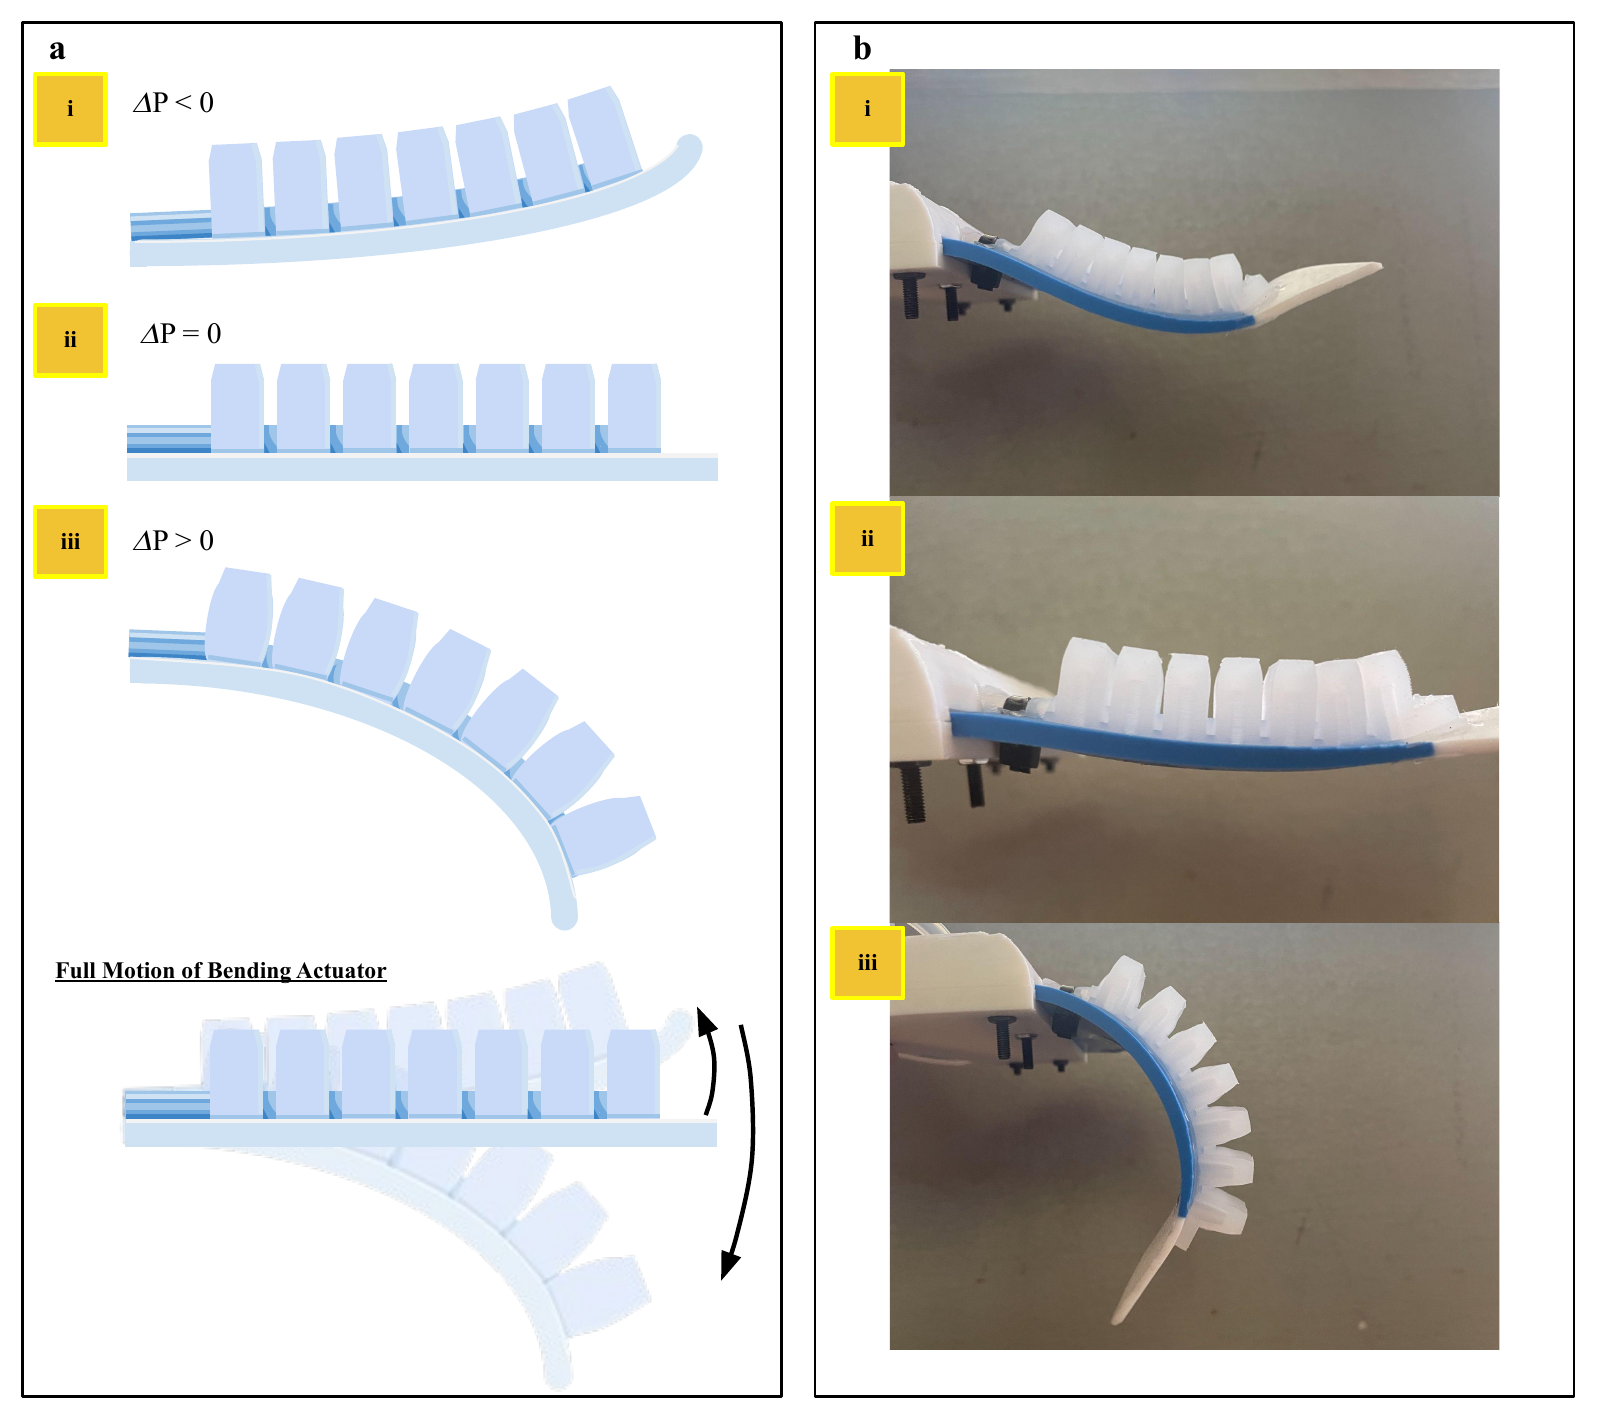
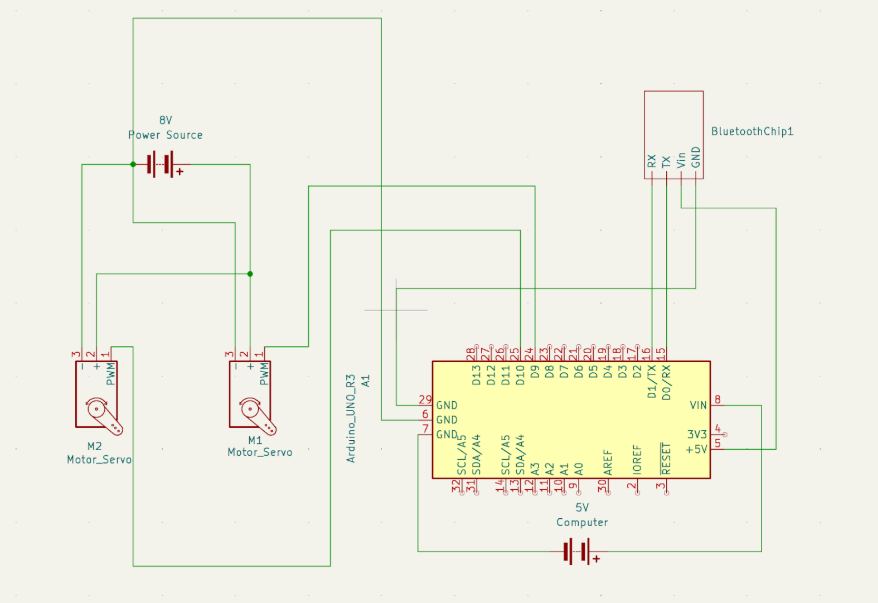
- Wrote embedded C++ control software on Arduino to automate PWM-driven pneumatic servo actuation, enabling repeatable fin motion for lab testing
- Built a Python tool that analytically computes the 3D magnetic field of an N52 magnet at arbitrary points, validated to >90% accuracy against a 3-axis magnetometer
Skills: Soft robotics · Onshape · Arduino / C++ · Pneumatic actuation · Python