Magnetic-Adhesion Climbing Robot — RIP Lab
Published:
1 / 9
| Role: Mobile Robotics Research Assistant · RIP Lab | When: May 2024 – Jul 2026 |
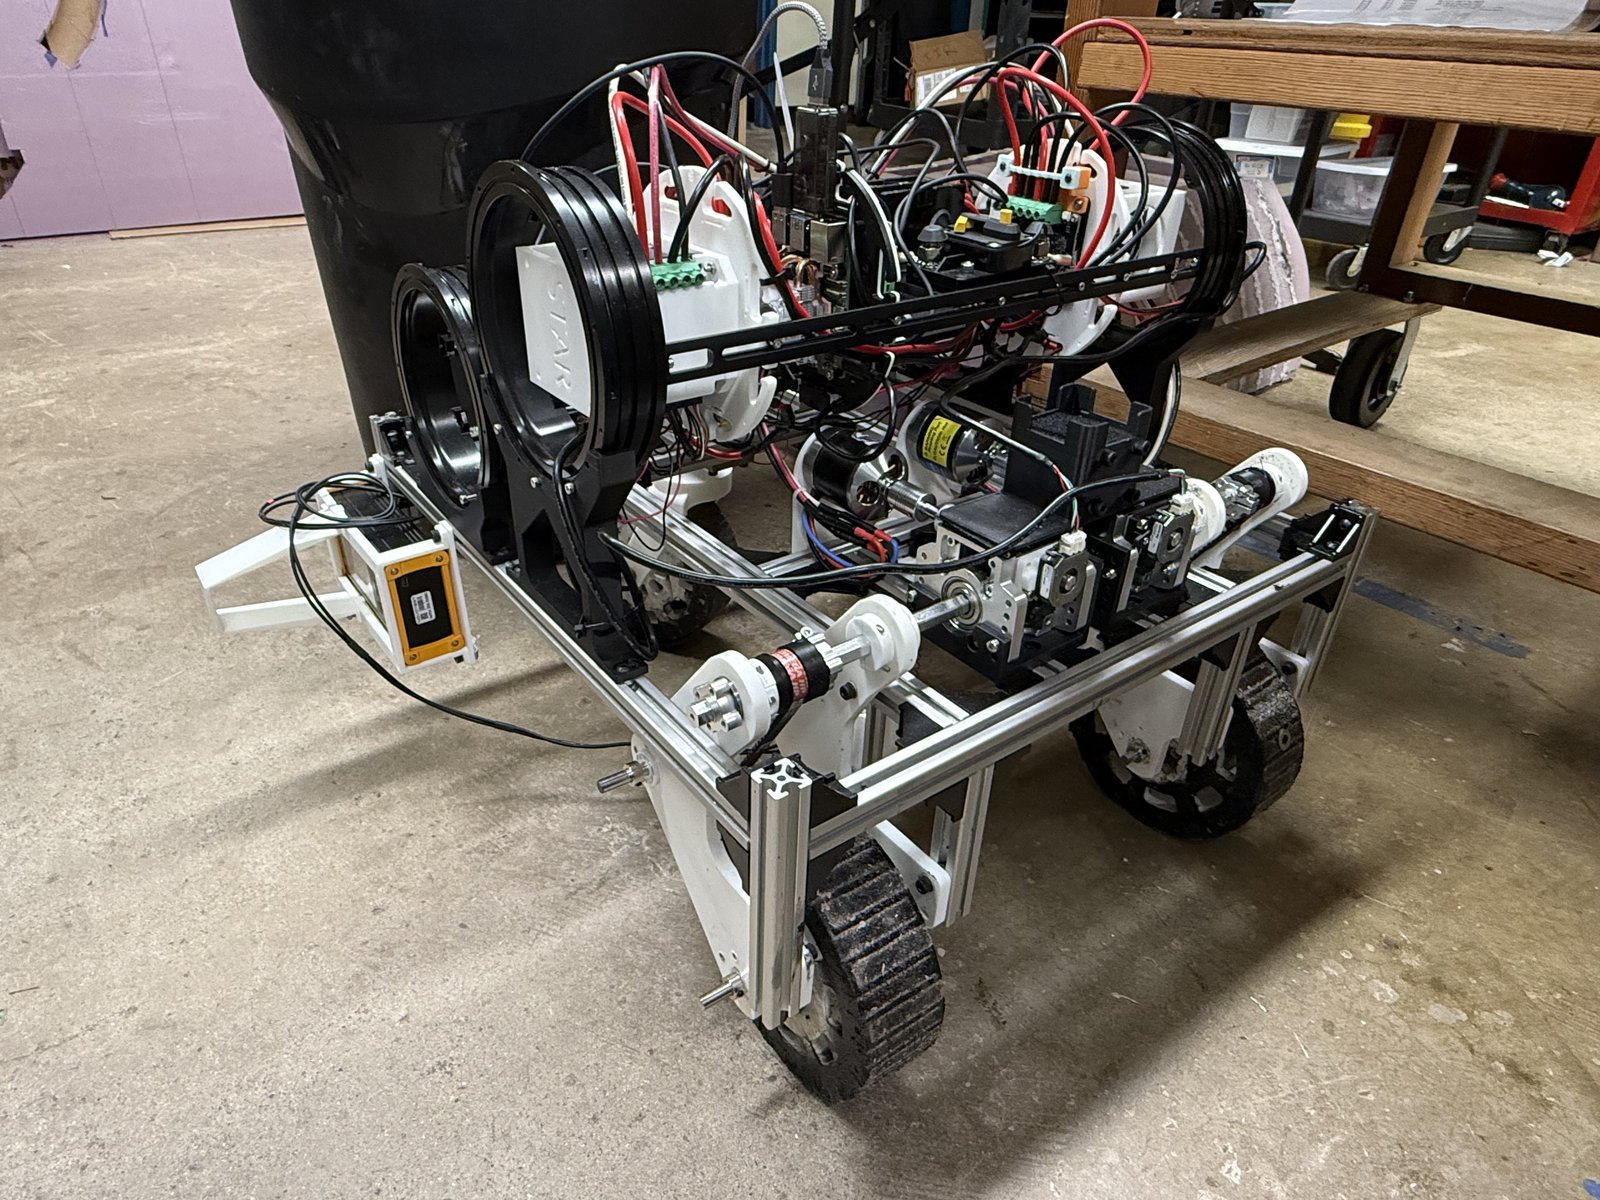
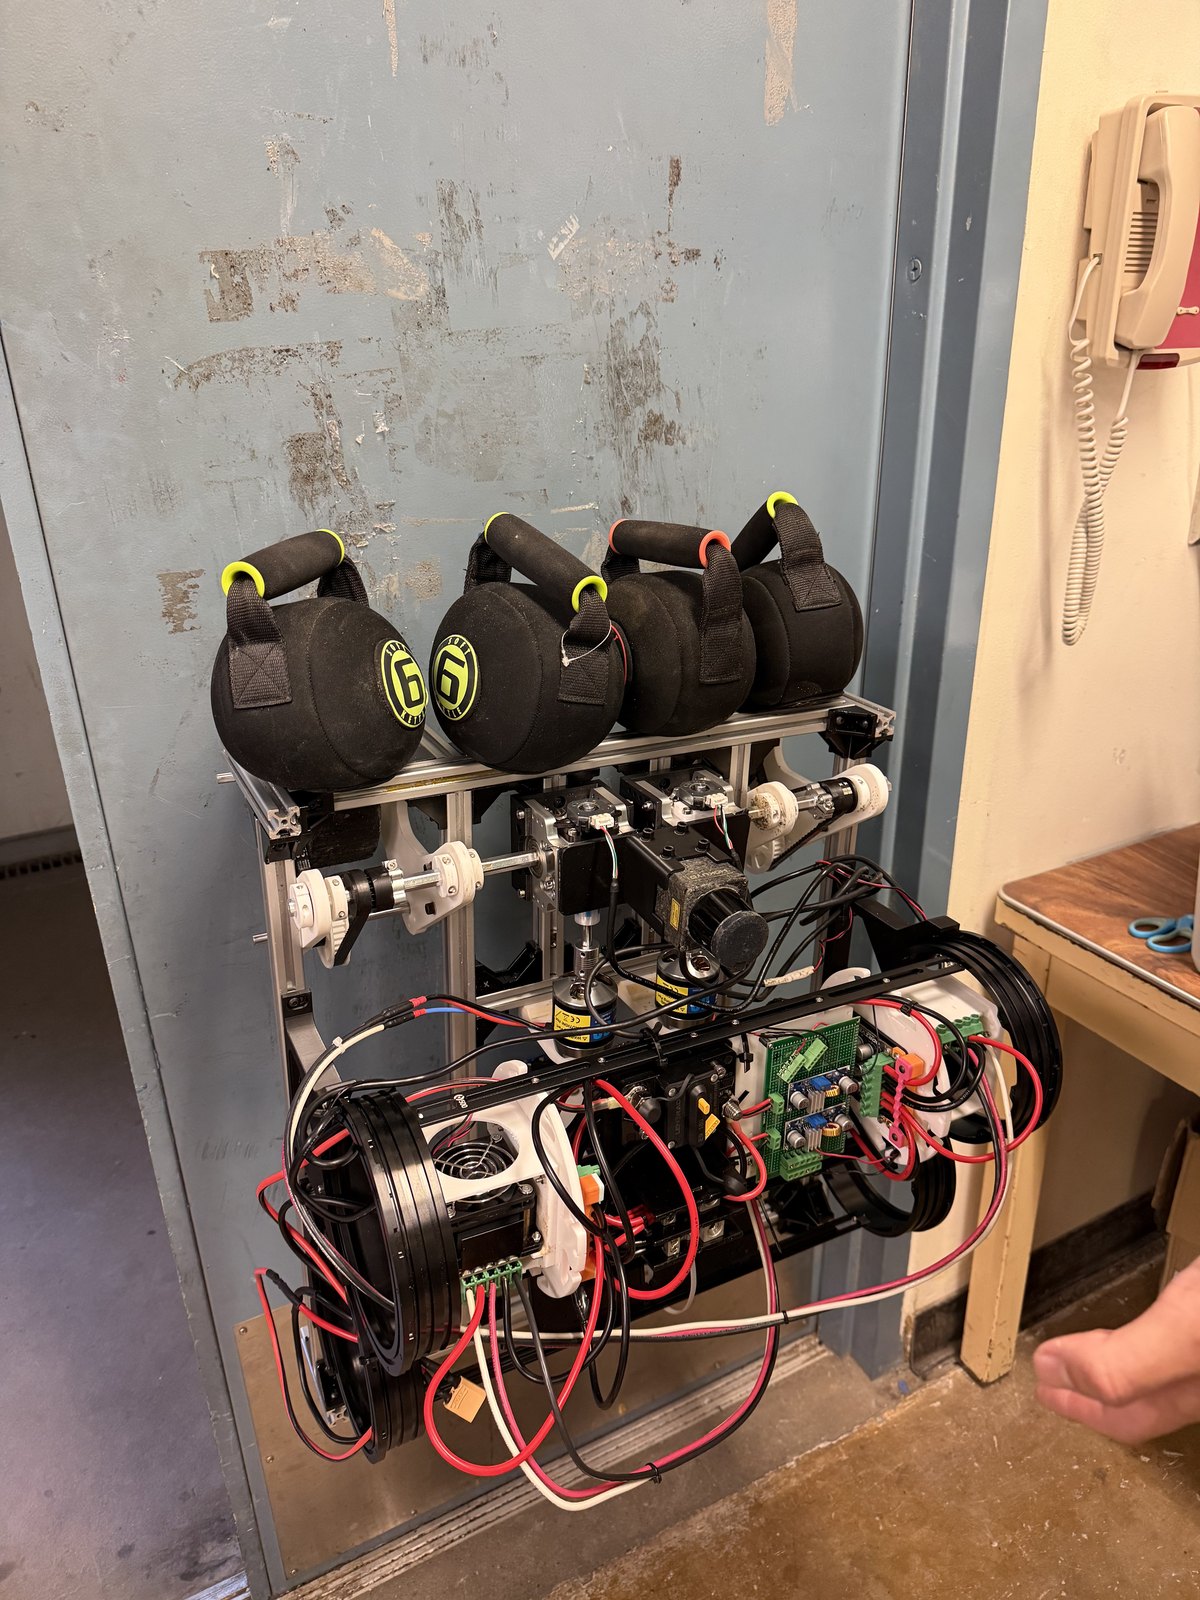
Designed and developed a 50-lb robot that inspects and climbs steel surfaces using magnetic adhesion, from the magnet geometry through the sensor-fusion software that keeps it stable.
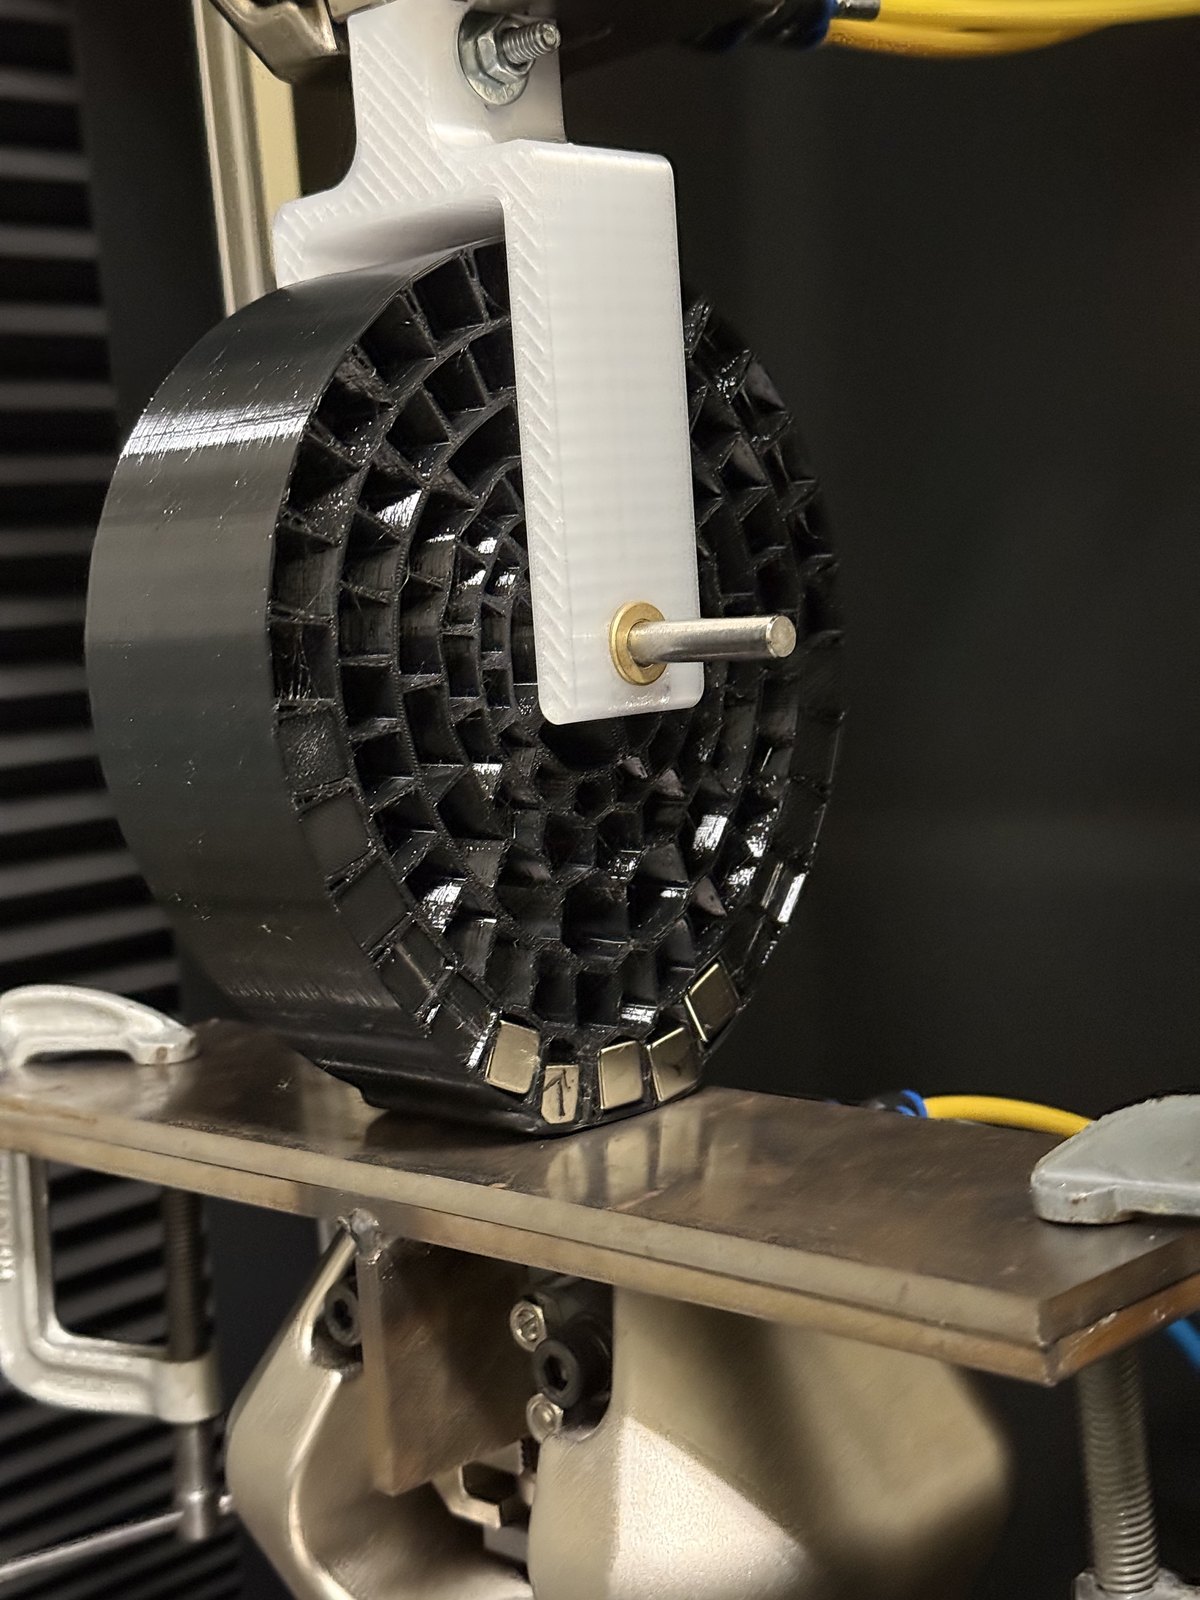
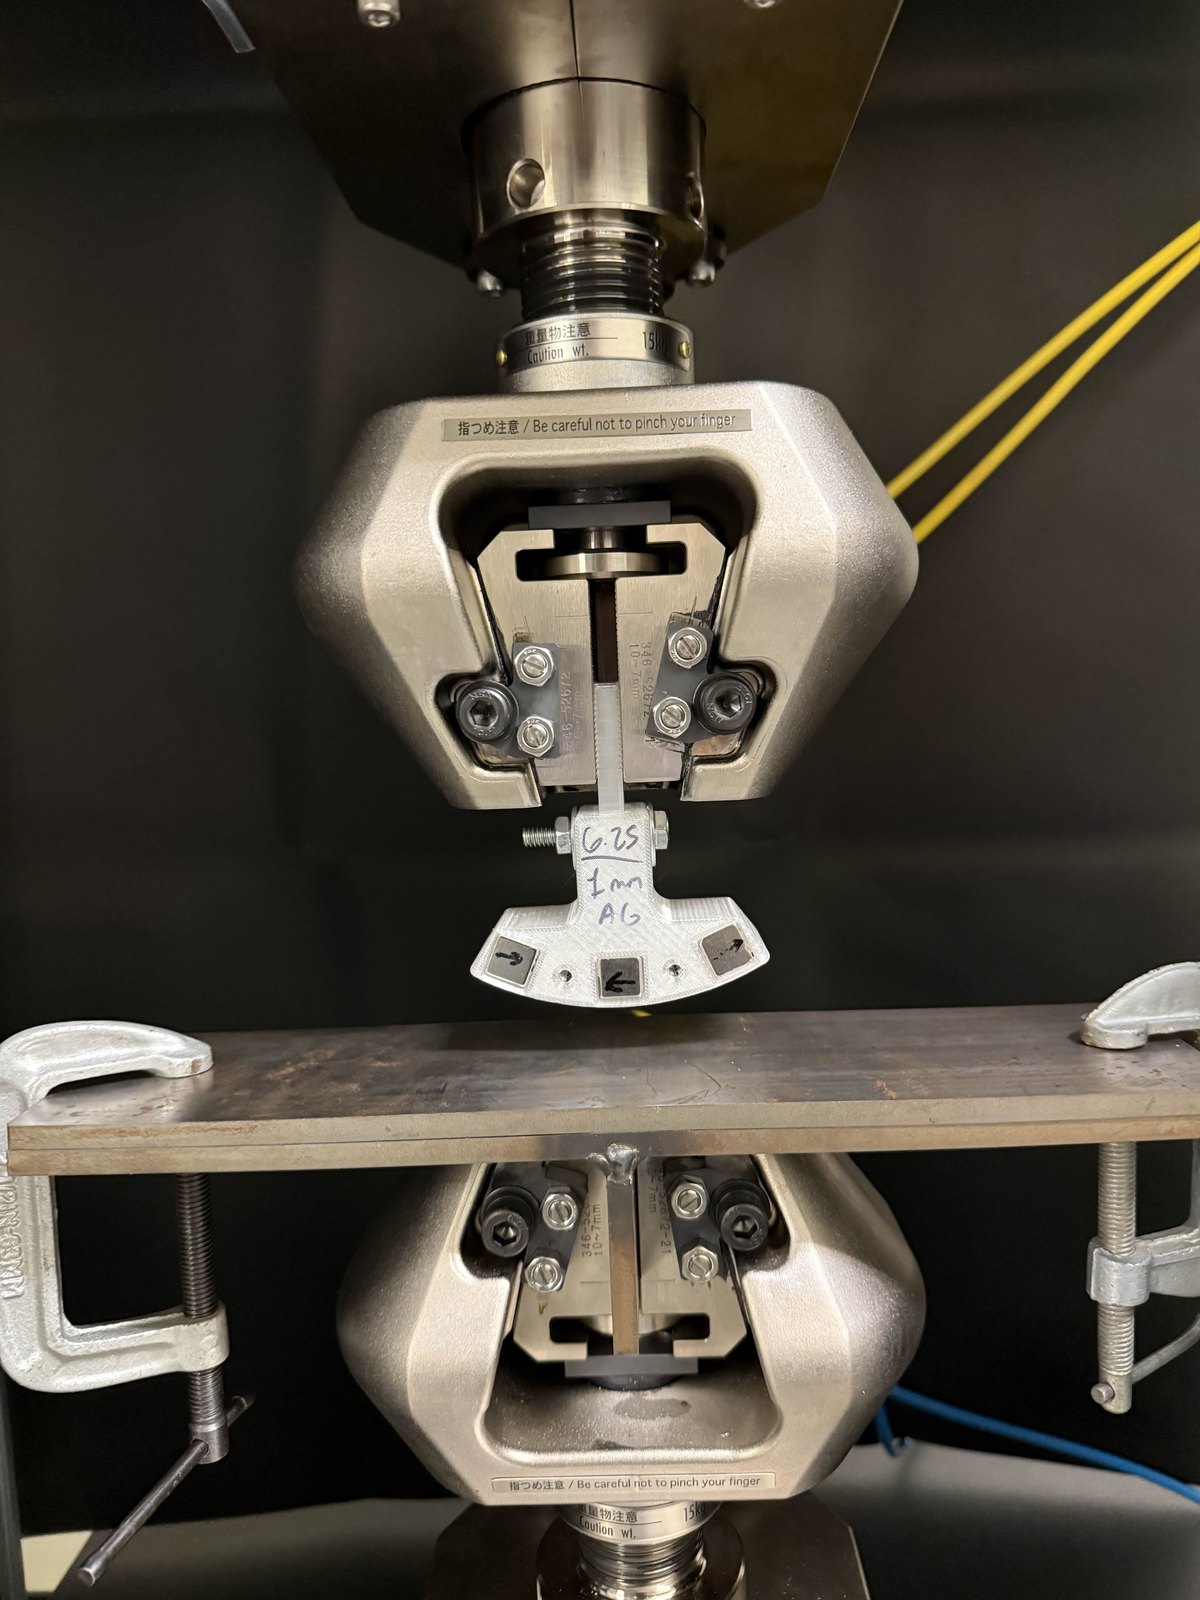
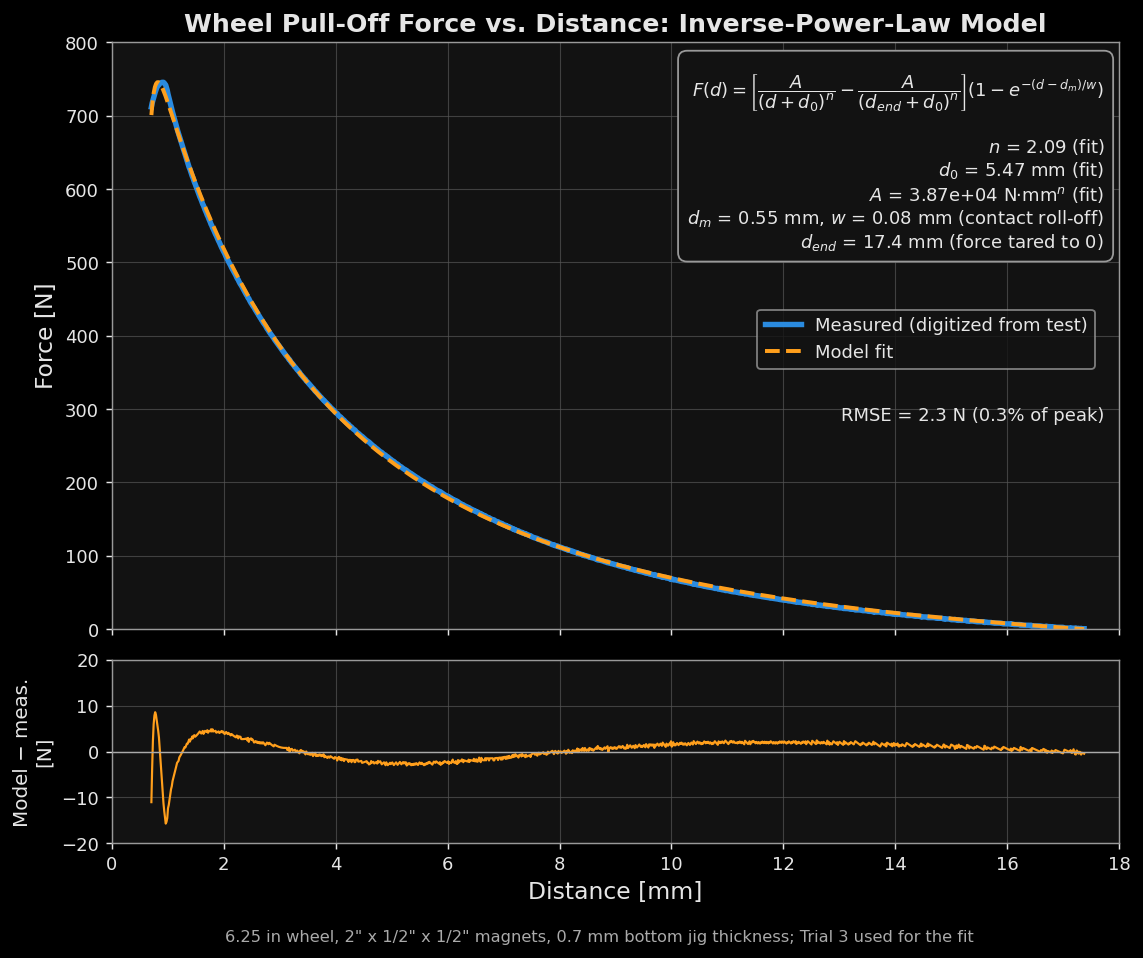
- Optimized magnetic-adhesion geometry in MATLAB and COMSOL FEA before fabrication to achieve stable vertical-surface operation, operating at speeds of 0.1 m/s.
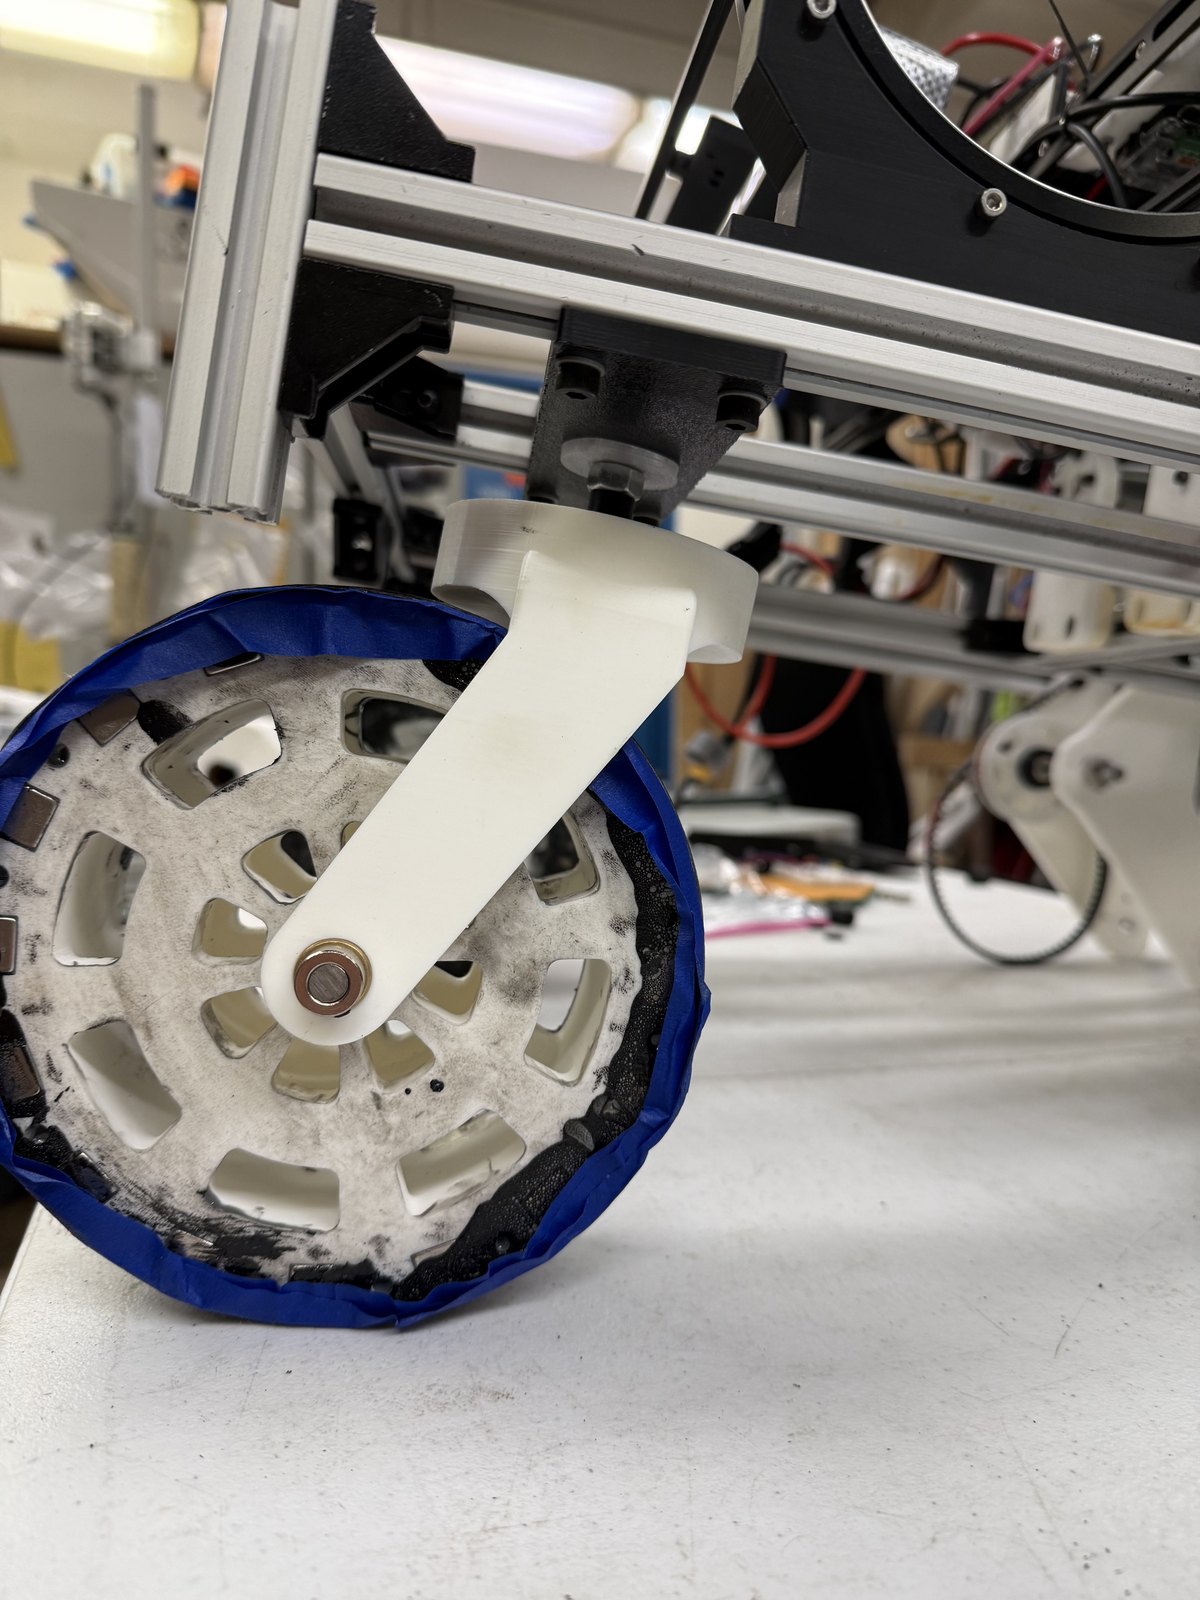
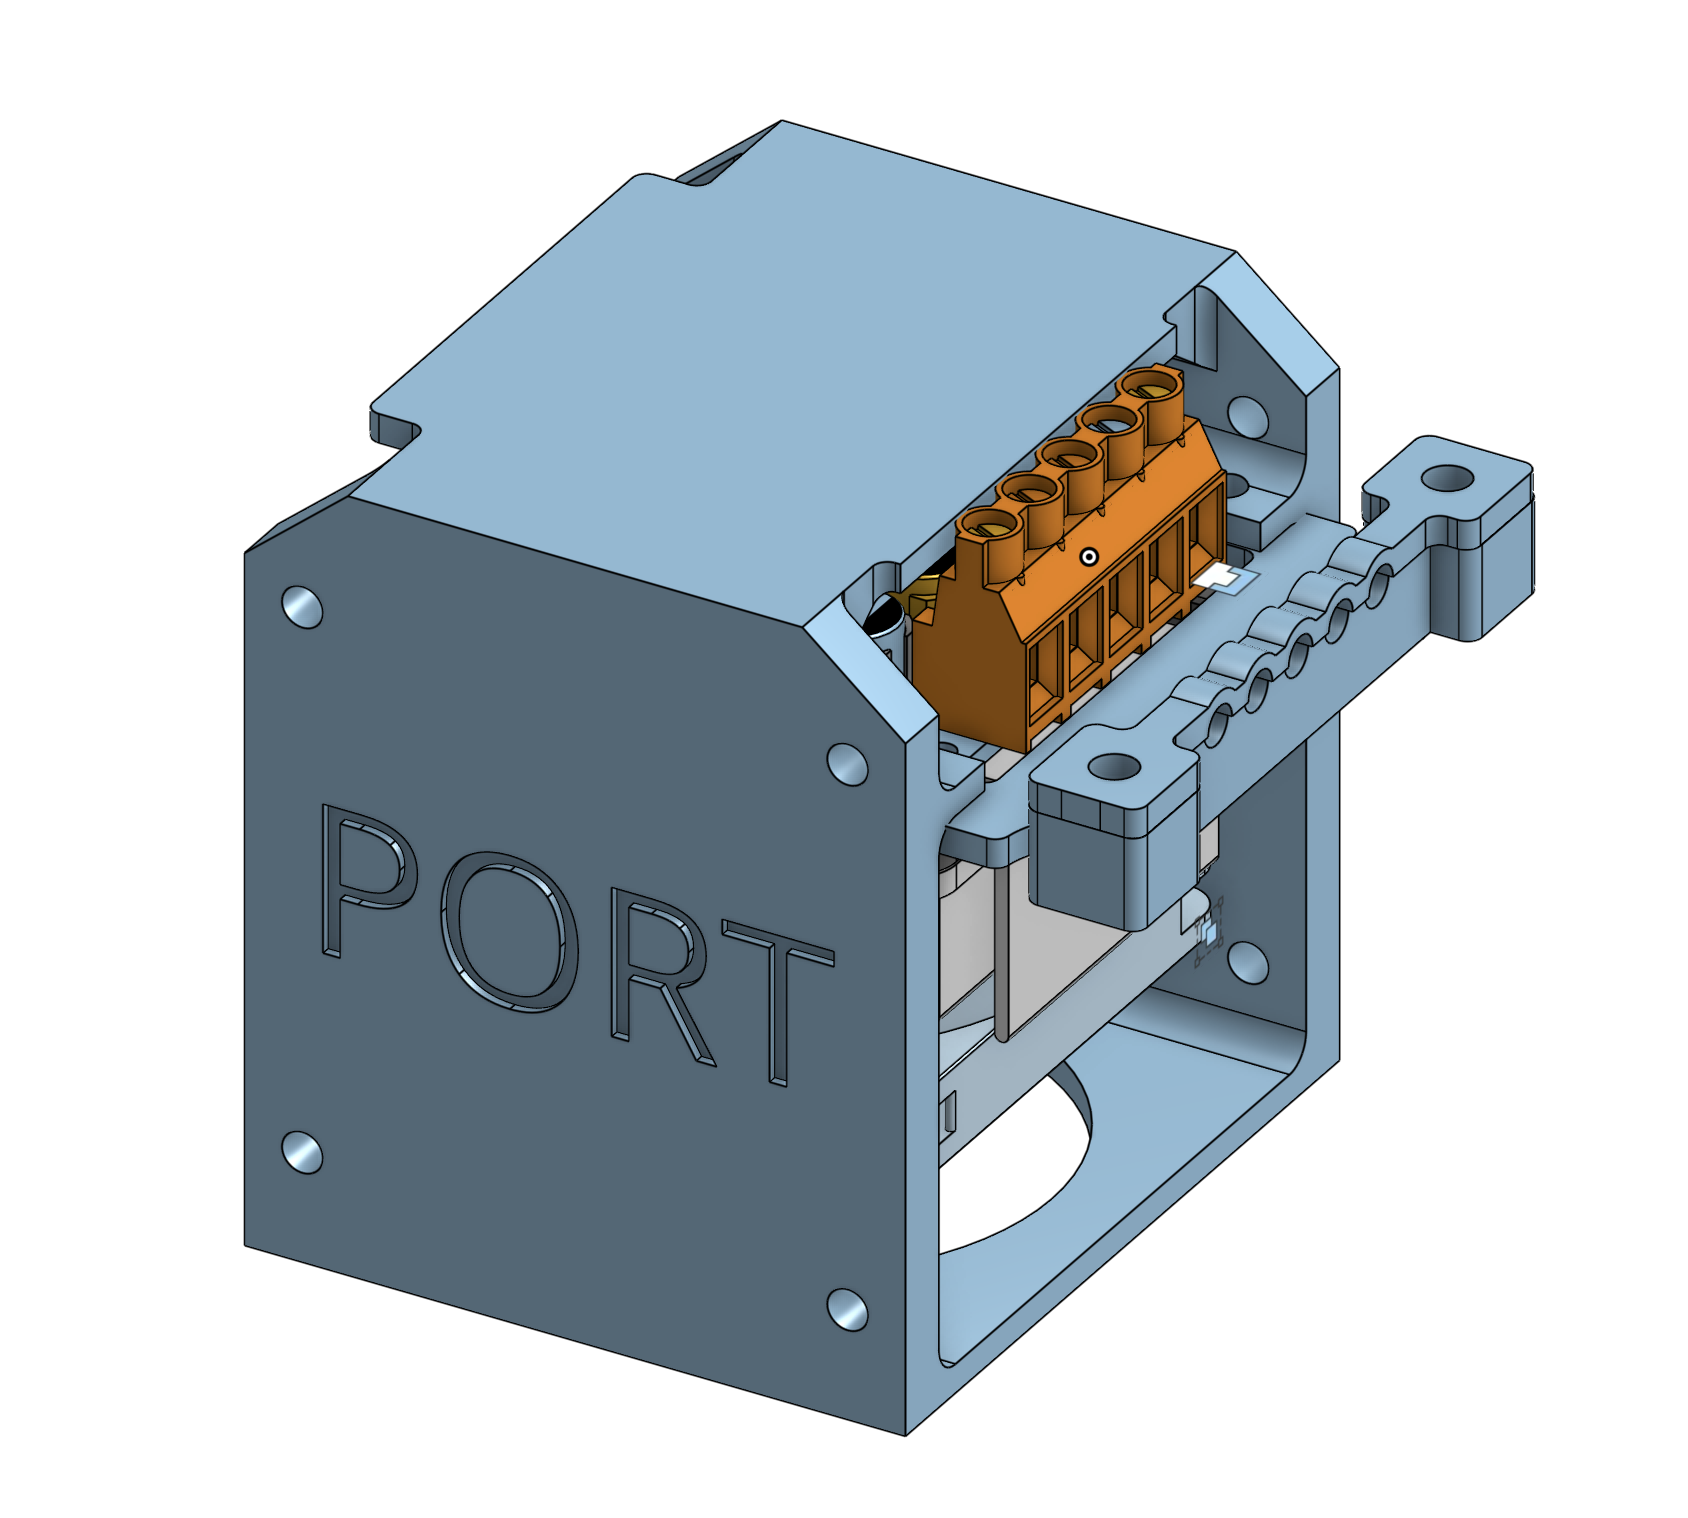
- Rapid-prototyped robotic parts such as sensor housings and caster wheels in Onshape, produced in-house via FDM and resin 3D printing
- Built a Python/C++ ROS 2 pipeline that fuses dual 9-DOF IMU streams through an Extended Kalman Filter, visualized live in RViz2
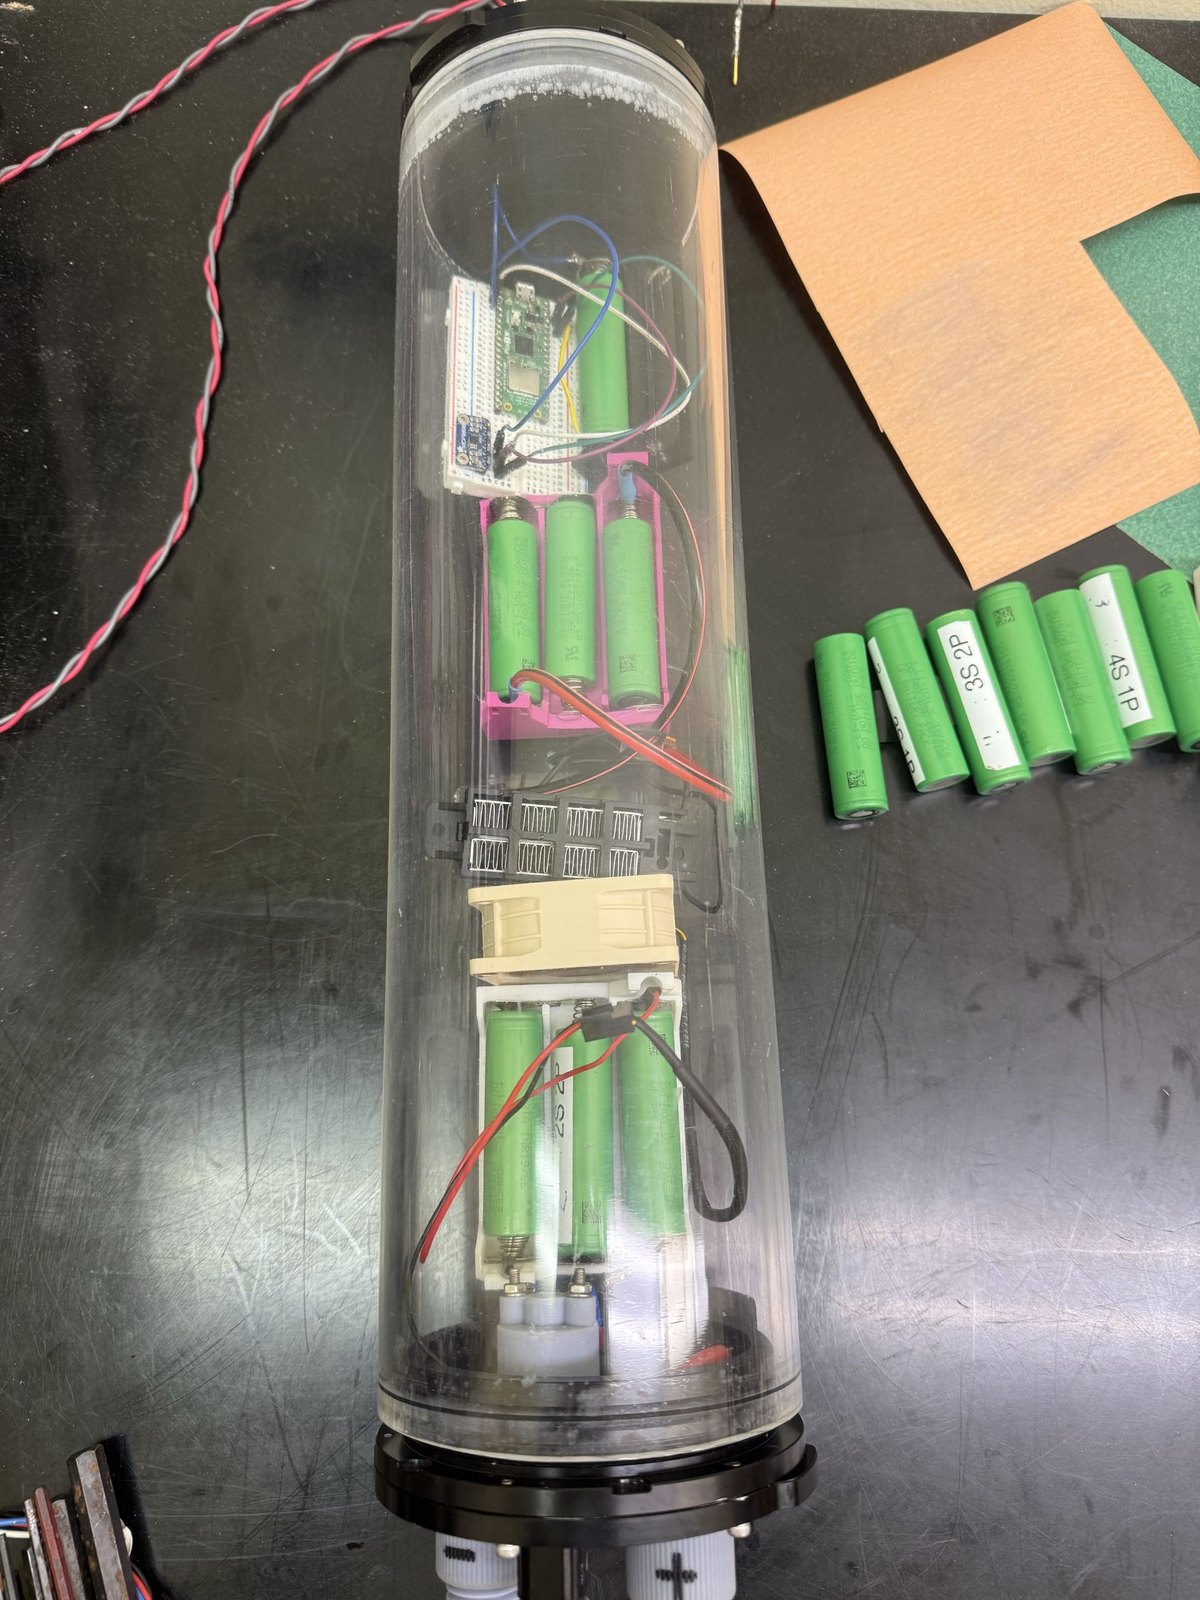
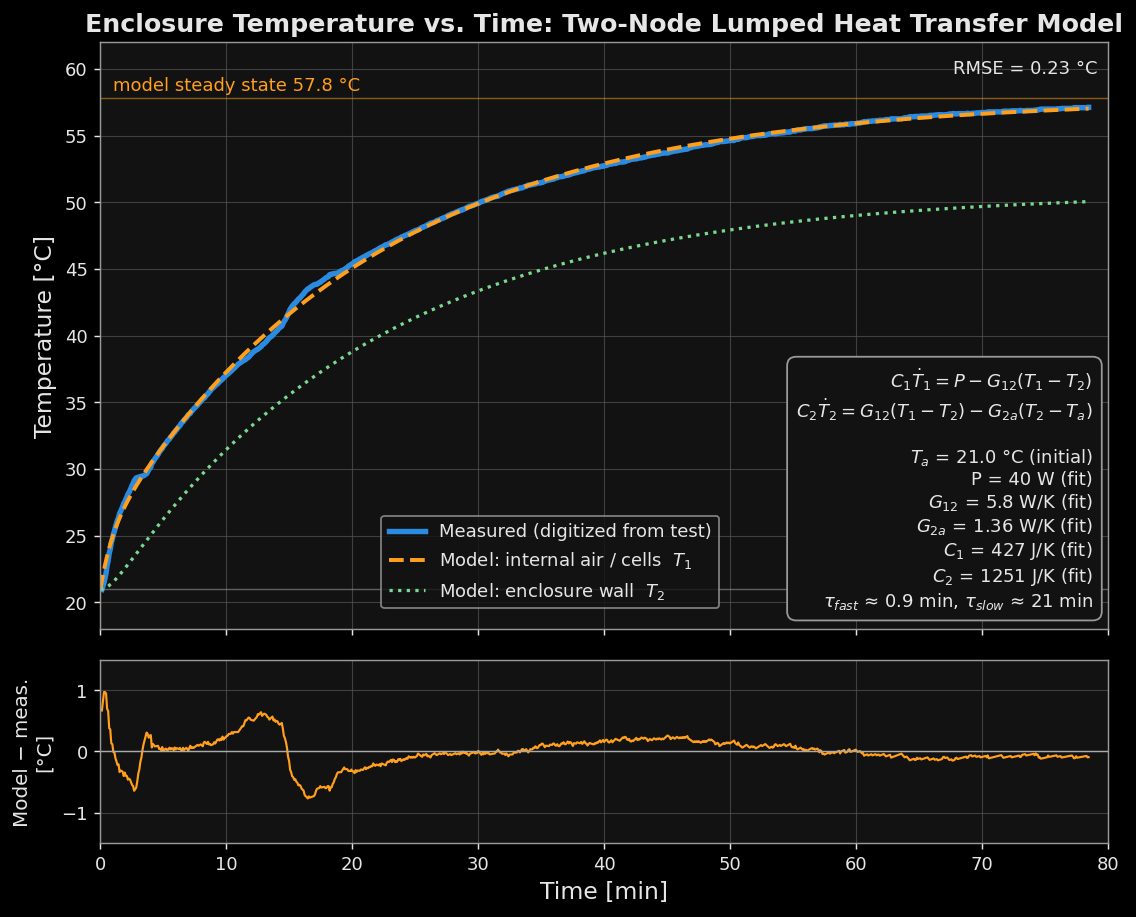
- Built a Python tool that monitors battery-enclosure temperature within 5% of a reference sensor across a full runtime cycle
Skills: Onshape · COMSOL Multiphysics · MATLAB · ROS2 · EKF · Python